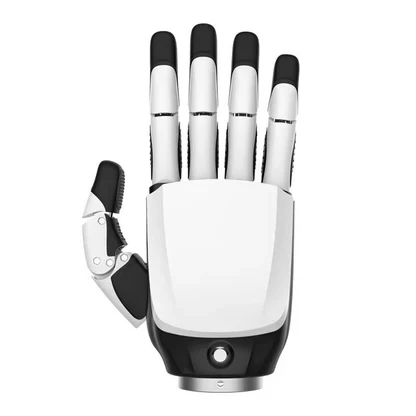
Inspire RH56DFTP Dexterous Hand
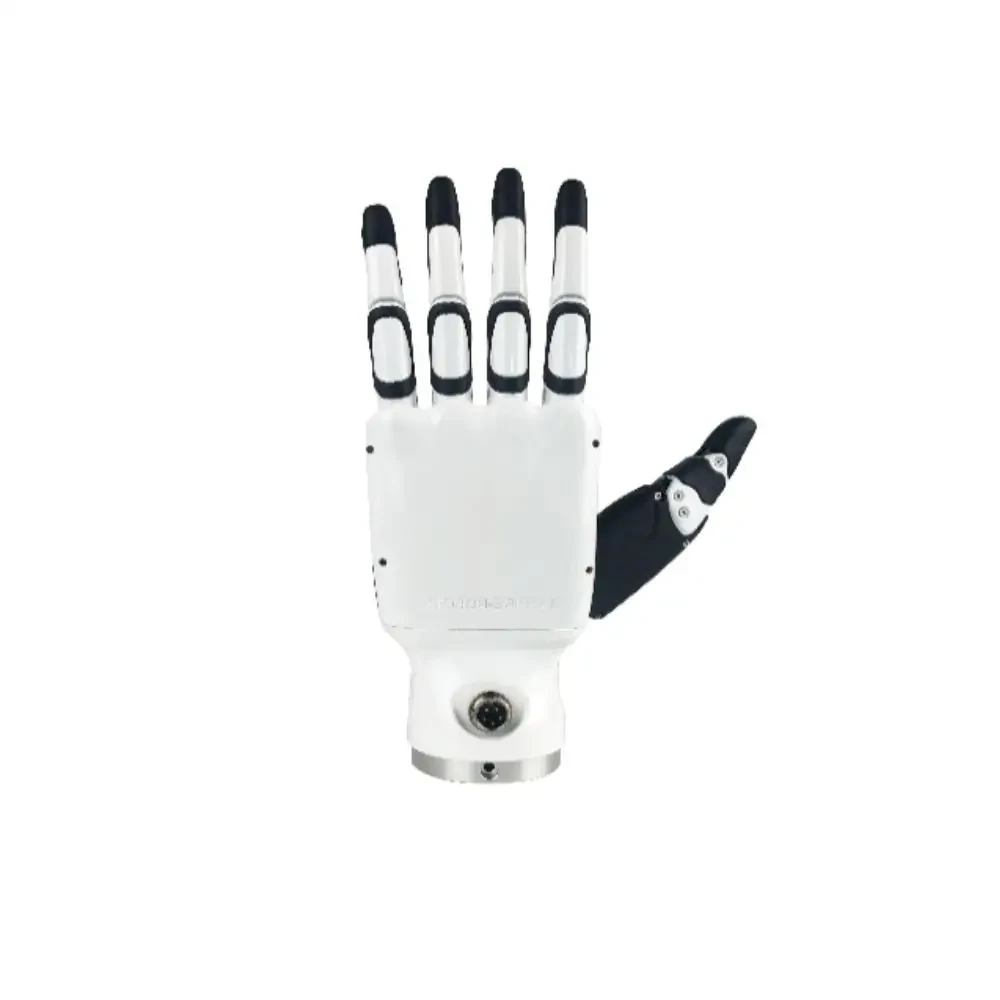
Inspire RH56DFTP dexterous hand — the five-finger tactile hand for Unitree G1 EDU, H1 and H2. This listing is the left hand; the right hand is one click away.
- Unitree G1 EDU Ultimate
- Unitree H1
- Unitree H1-2
- Unitree H2
About the Inspire RH56DFTP Dexterous Hand
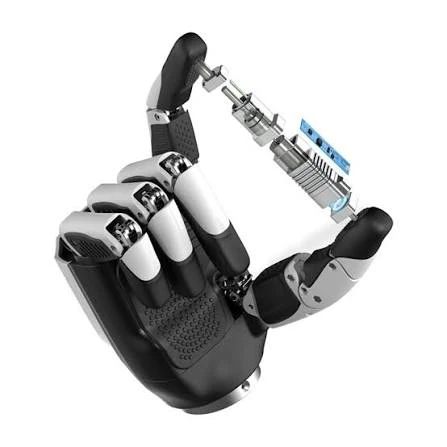
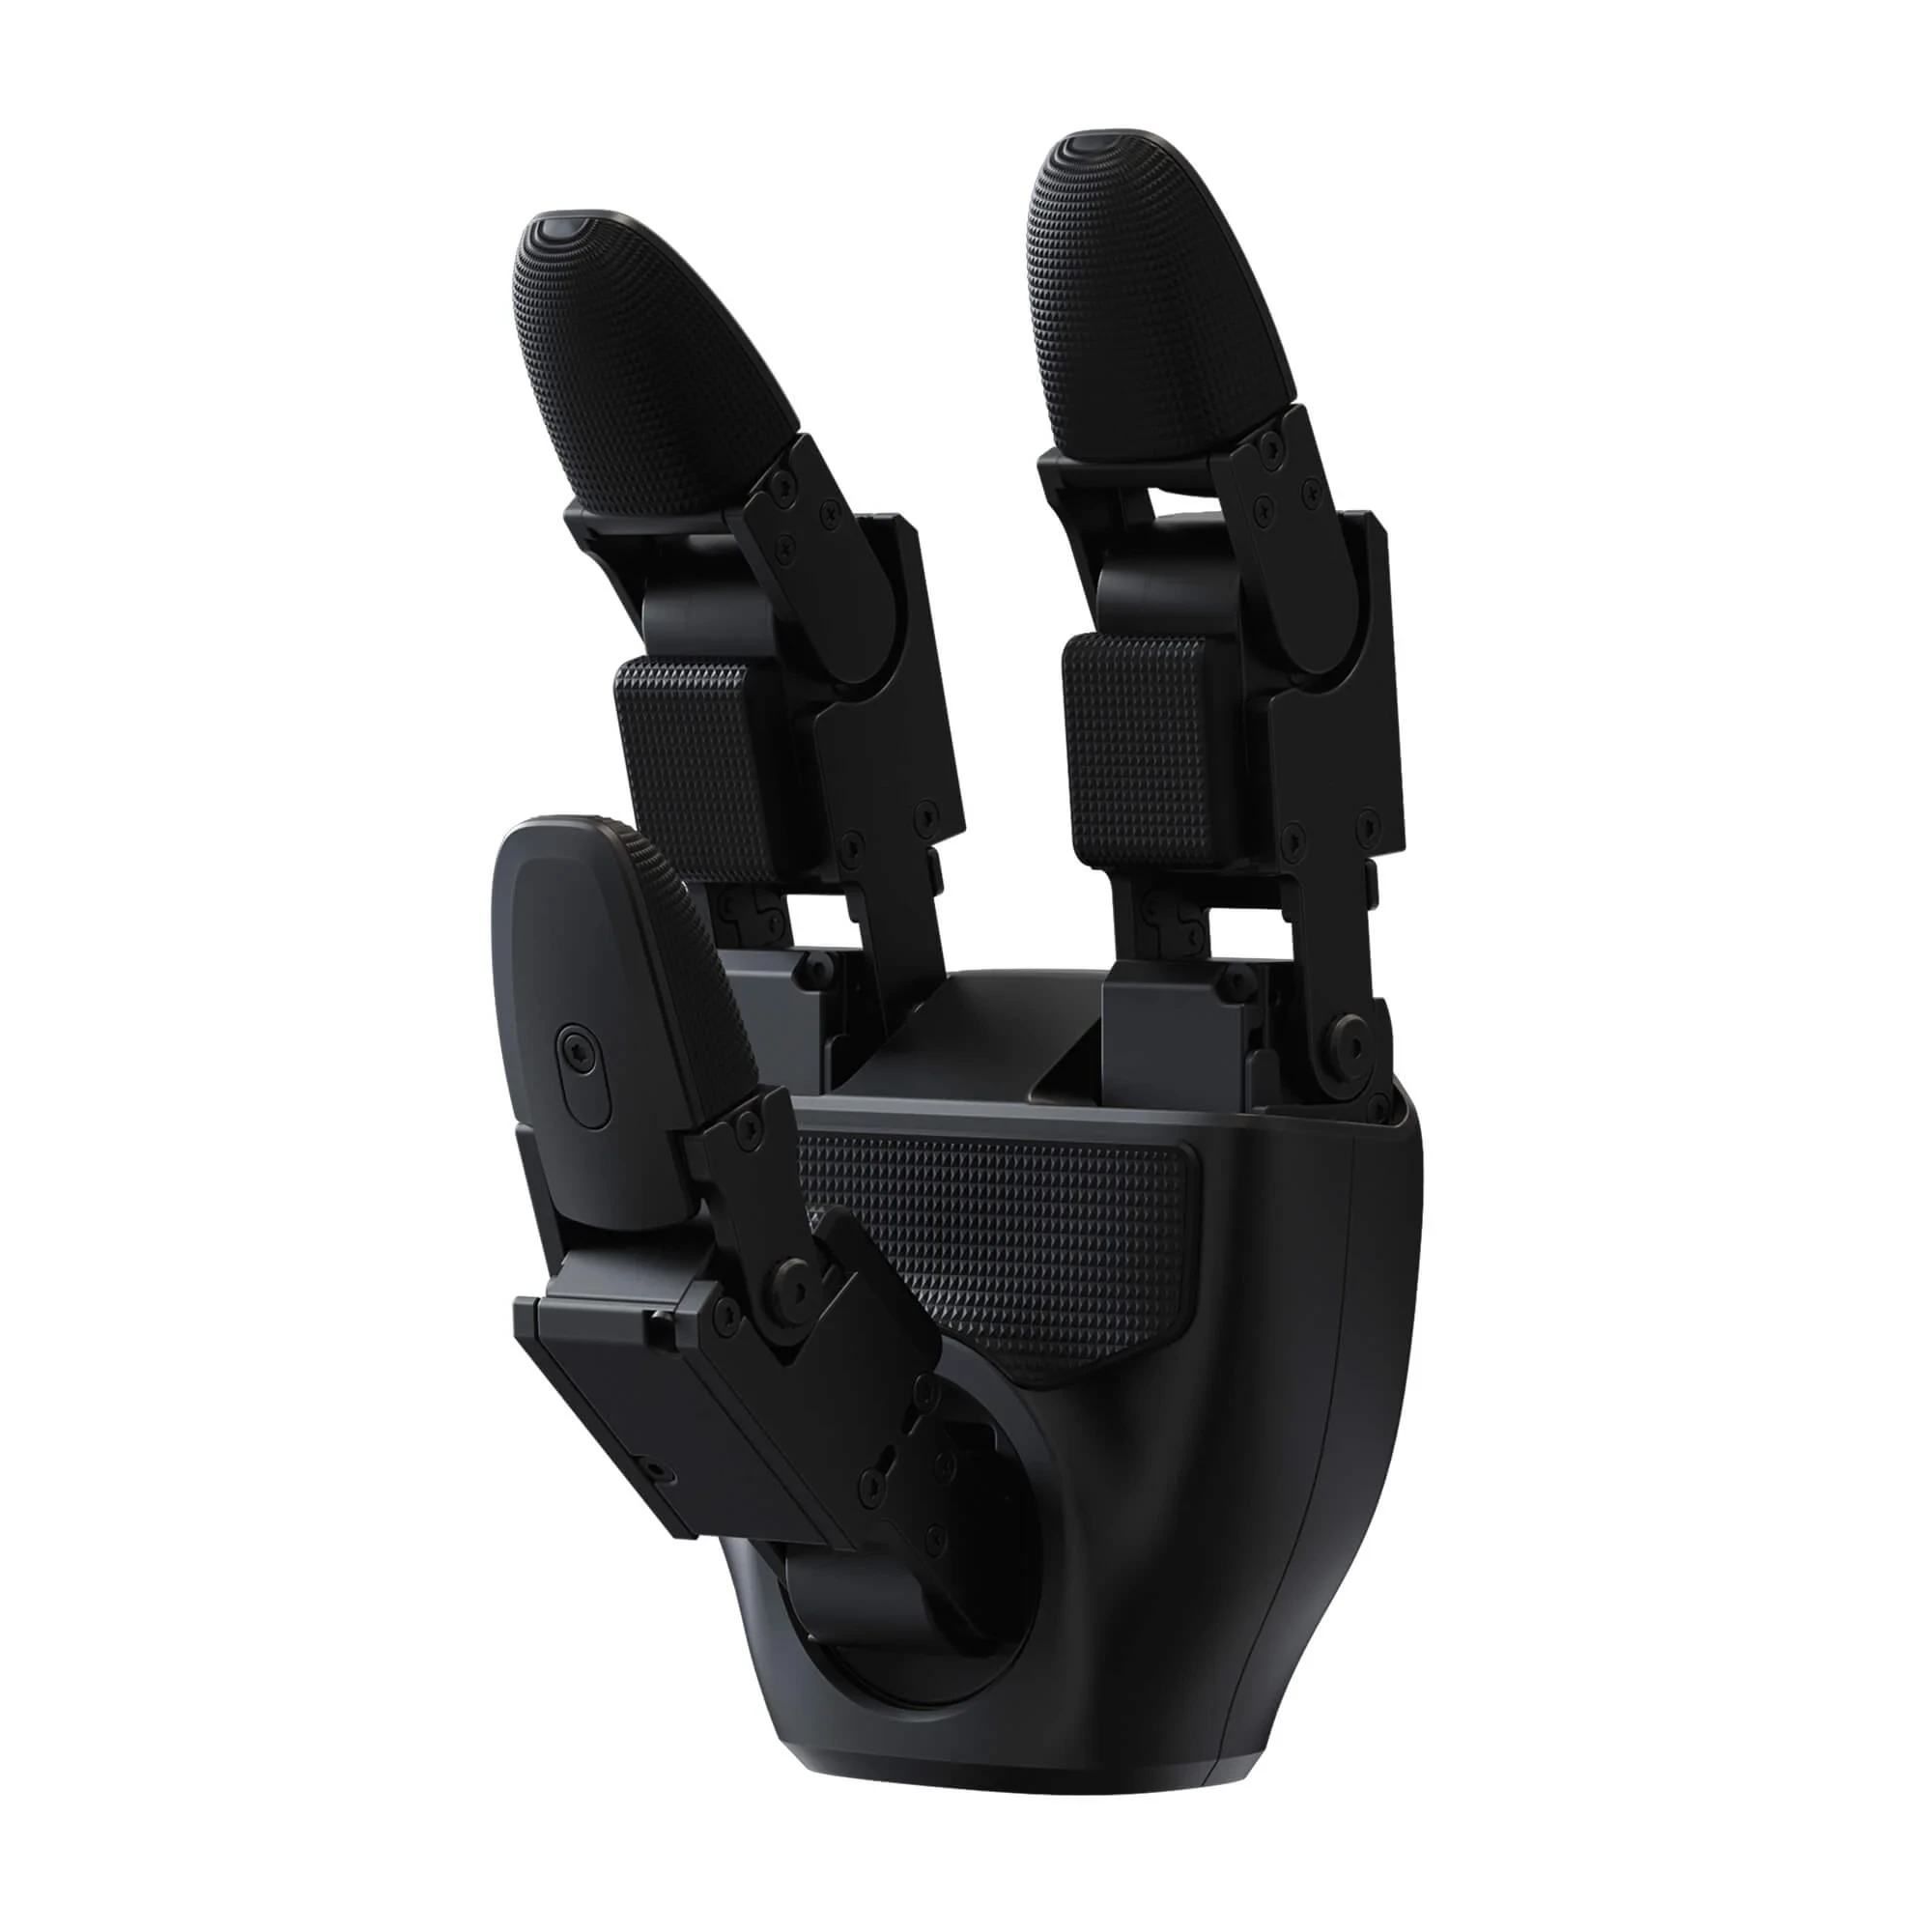
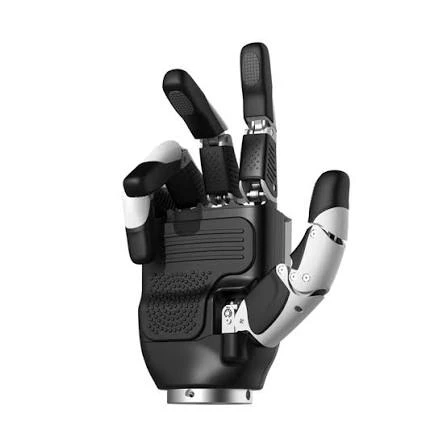
The Inspire RH56DFTP dexterous hand is the five-finger, tactile-sensing flagship of the RH56 family — 6 active degrees of freedom across 12 joints, with 17 tactile sensors and 6 force sensors reporting contact in real time. It is sold per hand — left or right — for new robot configurations, replacements and development work.
For labs and developers, it is the manipulation option behind contact-rich work on Unitree humanoids: precision grasping, teleoperation and demonstration-data collection, and tactile policy training on the G1 EDU, H1 and H2.
17 Tactile Sensors Across Fingertips, Finger Pads and Palm
The TP in the Inspire RH56DFTP dexterous hand is the tactile array: 17 tactile sensors spread across the fingertips, finger pads and palm, working alongside 6 force sensors reporting grip force in real time. Tactile data refreshes at 30 Hz or faster, so contact events register while the grasp is still forming, not after it slips.
That contact-level stream is what tactile manipulation research runs on: slip detection during transport, force estimation without an external sensor, and tactile policy training from real grasps. For teleoperation pipelines, it adds the contact channel that joint telemetry alone cannot provide.
- 17 tactile sensors — fingertips, finger pads and palm
- 6 force sensors with real-time grip feedback
- ≥30 Hz tactile refresh for contact-rich research
Six Linear Servos, Twelve Joints, 30 N of Grip
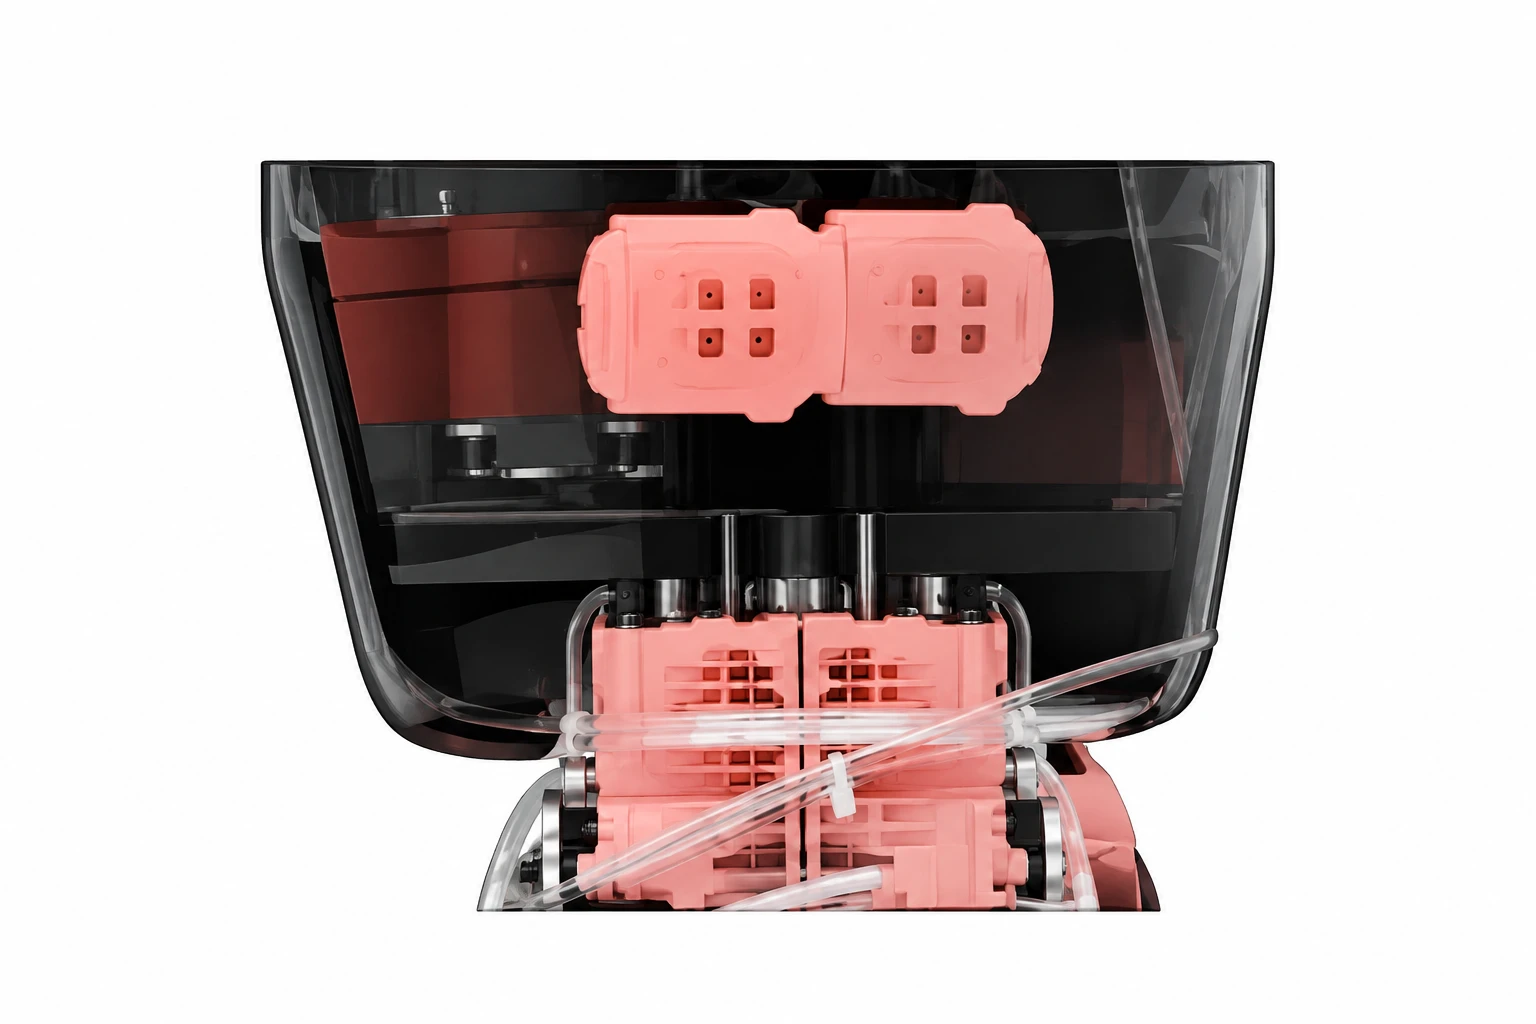
The Inspire RH56DFTP dexterous hand drives six active degrees of freedom across five fingers through six micro linear servo actuators acting on twelve joints. Force–position hybrid control with per-DoF force thresholds lets the fingers close on an object and hold it without driving through it — ±0.20 mm repeatability and up to 30 N of grip force.
When power is cut, the joints self-lock and hold the grasp — no re-zeroing on the next power-up. Control runs over ModbusTCP on Ethernet, CAN 2.0 or RS485, with ROS plugins available for integration work.
- 6 active DoF · 12 joints · 6 micro linear servo actuators
- ±0.20 mm repeatability · 30 N max grip force
- Power-off self-locking — holds the grasp without power
RH56DFTP vs RH56DFQ vs RH56DFX
Inspire builds the RH56 family in several versions. This page is the Inspire RH56DFTP dexterous hand — the tactile flagship. The RH56DFQ is the fast version fitted to the higher G1 EDU tiers and the H2-D; the RH56DFX is the general-integration version of the same hand family.
| RH56DFTP (this page) | RH56DFQ | RH56DFX | |
|---|---|---|---|
| Tactile sensing | 17 tactile sensors — fingertips, pads, palm | ||
| Force sensing | 6 force sensors | 6 pressure sensors · 0.5 N resolution | Integrated force sensing |
| Max grip force | 30 N | Thumb 6 N · four fingers 4 N | Thumb 15 N · four fingers 10 N |
| Four-finger speed | > 200°/s | 570°/s | 260°/s |
| Weight | 790 g | 540 g | 540 g |
| Communication | ModbusTCP + CAN · RS485 optional | RS485 or CAN · ROS/ROS2 | RS485 · ROS |
| Best for | Contact-rich research and tactile data on G1 EDU Ultimate, H1 and H2 | Fast teleoperation on G1 EDU (U2 and higher) and H2-D | General integration needing higher grip without tactile |
How to Tell the Left Hand from the Right
The Inspire RH56DFTP dexterous hand is sold per hand, and the two sides are mirror builds — they are not interchangeable. The part number carries the side: RH56DFTP-0L is the left hand, RH56DFTP-0R is the right hand. Listings tagged -2L/-2R (for example, for the Unitree H2) are the robot-bundle version of the same hand.
Order a single hand for a replacement or for single-arm tasks. For bilateral manipulation, plan a pair — one left hand and one right hand, added as two line items on your quote.
- RH56DFTP-0L = left hand · RH56DFTP-0R = right hand
- -2L / -2R listings are the robot-bundle version (e.g., Unitree H2)
- A full humanoid setup uses two — one left, one right
The Five-Finger Tactile Option for Unitree Humanoids
The Inspire RH56DFTP dexterous hand is the five-finger tactile hand option across the Unitree humanoid line: Unitree's H1 developer documentation covers the RH56DFTP integration, the H2 takes it as a dexterous-hand option (the -2L/-2R listings), and G1 EDU Ultimate builds ship with it. The hand mounts at the wrist interface and talks ModbusTCP over Ethernet, CAN 2.0 or RS485, with ROS plugins available.
On G1 EDU tiers below Ultimate, the five-finger option is the faster RH56DFQ — the same architecture without the tactile array.
Specifications
| Left Hand | Right Hand | |
|---|---|---|
| Type | Five-finger tactile dexterous hand | Five-finger tactile dexterous hand |
| Hand | Left (RH56DFTP-0L) | Right (RH56DFTP-0R) |
| Fingers | 5 | 5 |
| Degrees of freedom | 6 active — 12 joints total | 6 active — 12 joints total |
| Actuation | 6 micro linear servo actuators | 6 micro linear servo actuators |
| Weight | 790 g ±10 g | 790 g ±10 g |
| Max grip force | 30 N (≈3 kg) | 30 N (≈3 kg) |
| Repeatability | ±0.20 mm | ±0.20 mm |
| Tactile sensors | 17 — fingertips, finger pads and palm | 17 — fingertips, finger pads and palm |
| Force sensors | 6 | 6 |
| Tactile refresh rate | ≥30 Hz | ≥30 Hz |
| Thumb lateral rotation | > 85° | > 85° |
| Motion speed | Thumb > 130°/s · four fingers > 200°/s | Thumb > 130°/s · four fingers > 200°/s |
| Control | Force–position hybrid control, per-DoF force thresholds, power-off self-locking | Force–position hybrid control, per-DoF force thresholds, power-off self-locking |
| Communication | ModbusTCP (Ethernet) + CAN 2.0 · RS485 optional | ModbusTCP (Ethernet) + CAN 2.0 · RS485 optional |
| Operating voltage | DC 24 V ±10% | DC 24 V ±10% |
| Current | 0.2 A quiescent · 4 A peak | 0.2 A quiescent · 4 A peak |
| ROS support | ROS plugins available | ROS plugins available |
| Fits | Unitree G1 EDU Ultimate · H1 / H1-2 · H2 | Unitree G1 EDU Ultimate · H1 / H1-2 · H2 |
| In the box | Inspire RH56DFTP-0L dexterous hand — left hand | Inspire RH56DFTP-0R dexterous hand — right hand |
Shipping & Service
The hand ships worldwide by DHL or FedEx in protective industrial packaging; exact transit time is confirmed with your quote.
Every unit is 100% quality-inspected before it ships, so it arrives in perfect working order.
Last updated: September 2026.
Frequently Asked Questions
Can't find what you're looking for? Contact our