Inspire RH56DFQ Dexterous Hand
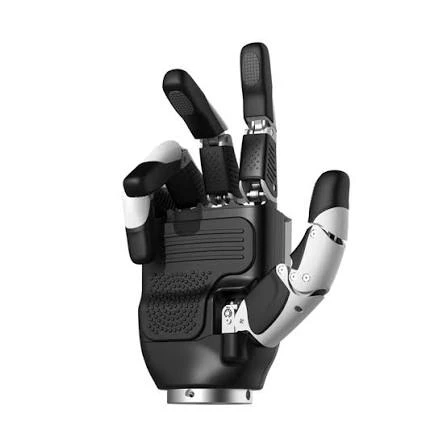
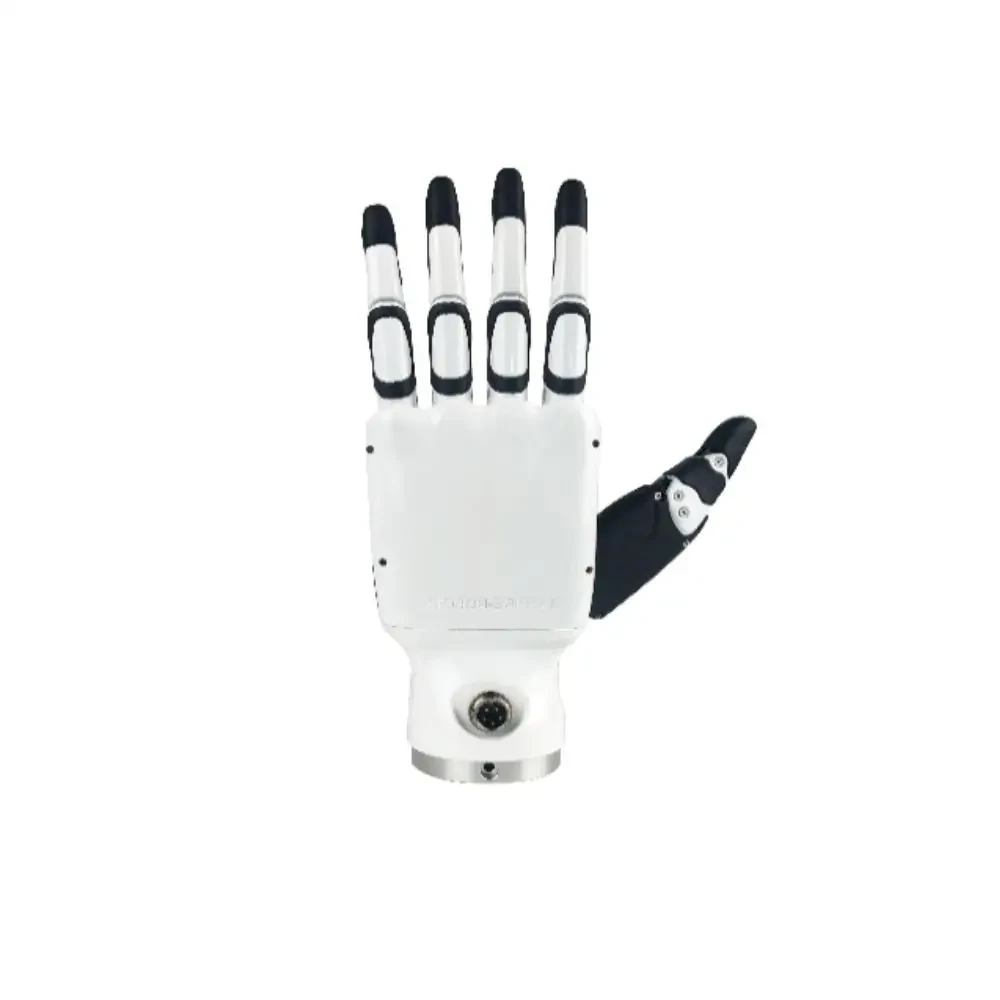
Inspire RH56DFQ dexterous hand — a five-finger, force-controlled hand for the G1 EDU, the H1 and the H2, shipped with its wrist unit. This listing is the left hand; the right hand is one click away.
- Unitree G1 EDU (U2 and higher)
- Unitree H1 / H1-2 (hand + wrist)
- Unitree H2 (H2-D configuration)
About the Inspire RH56DFQ Dexterous Hand
The Inspire RH56DFQ dexterous hand is a five-finger, force-controlled end effector — the dexterous-hand option fitted on the higher tiers of the Unitree G1 EDU, on the full-size H1 and H1-2, and on the H2 in its dexterous-hand configuration (the H2-D). It is sold per hand — left or right — for new robot configurations, replacements and development work.
For labs and developers, the five-finger layout covers human-like grasp postures: power grasps, precision pinches and in-hand adjustment, with force sensing behind teleoperation and demonstration-data collection.
Six Driven Joints, Five Fingers, Force Feedback
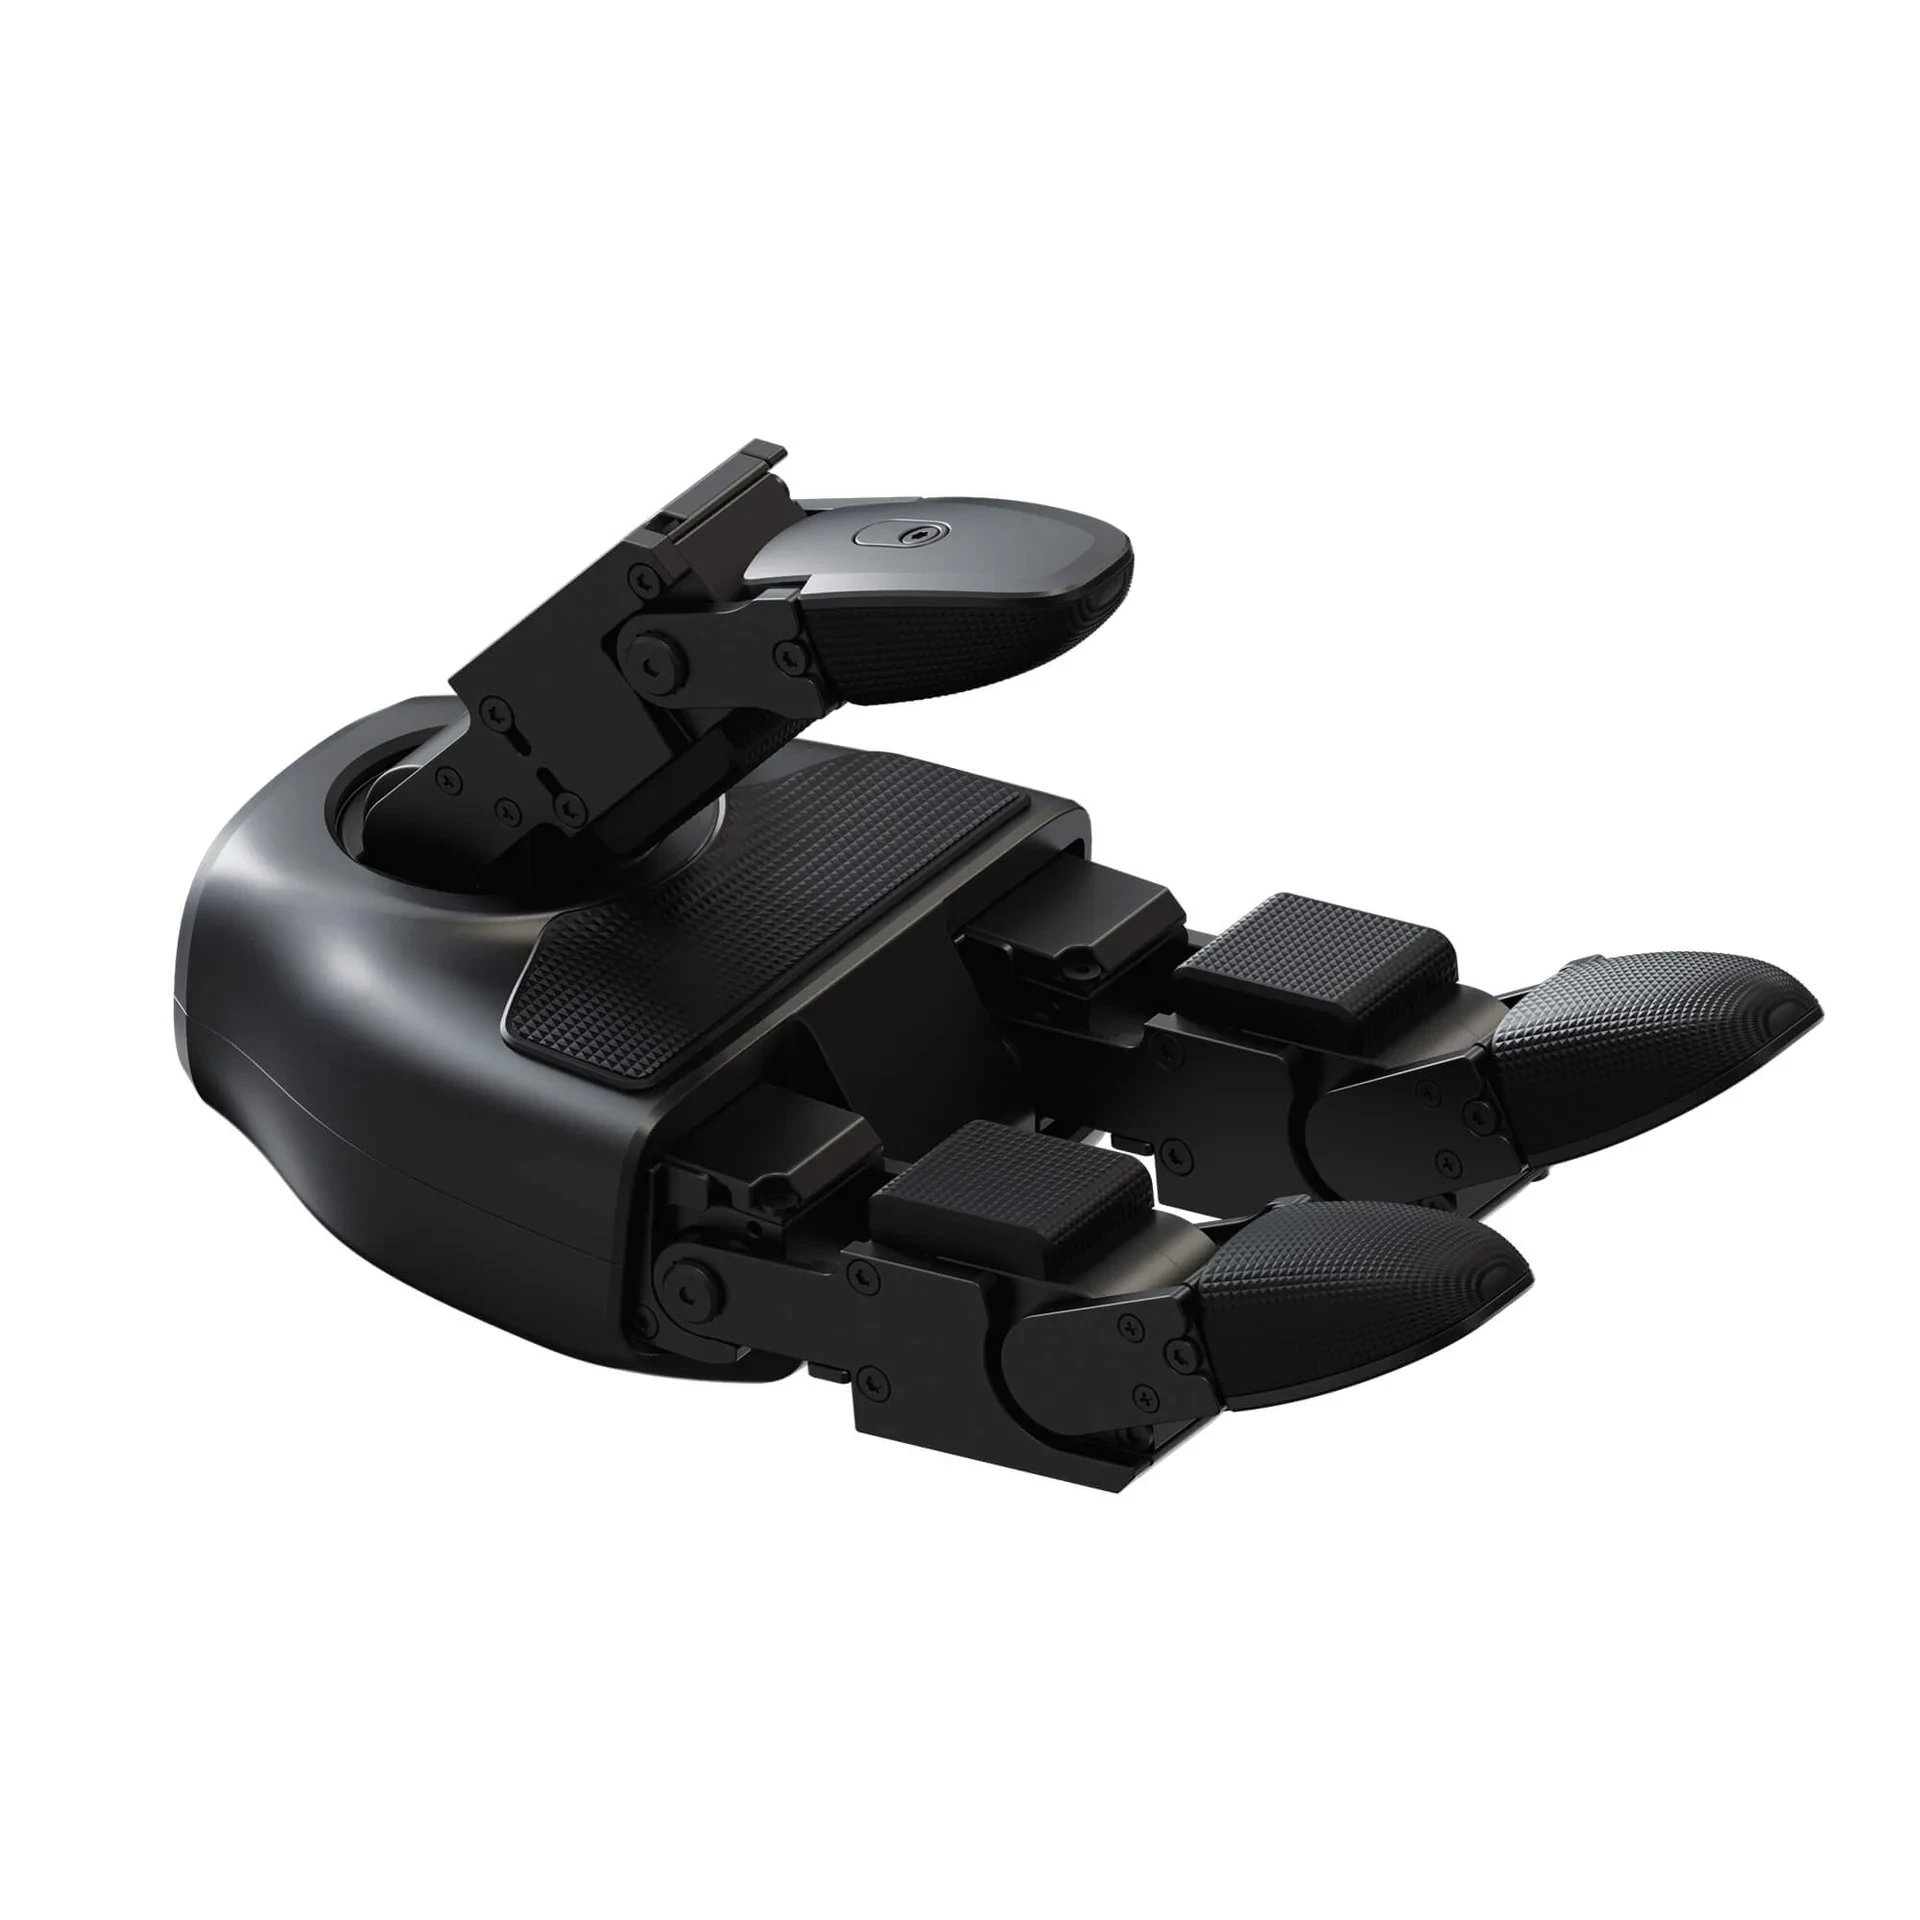
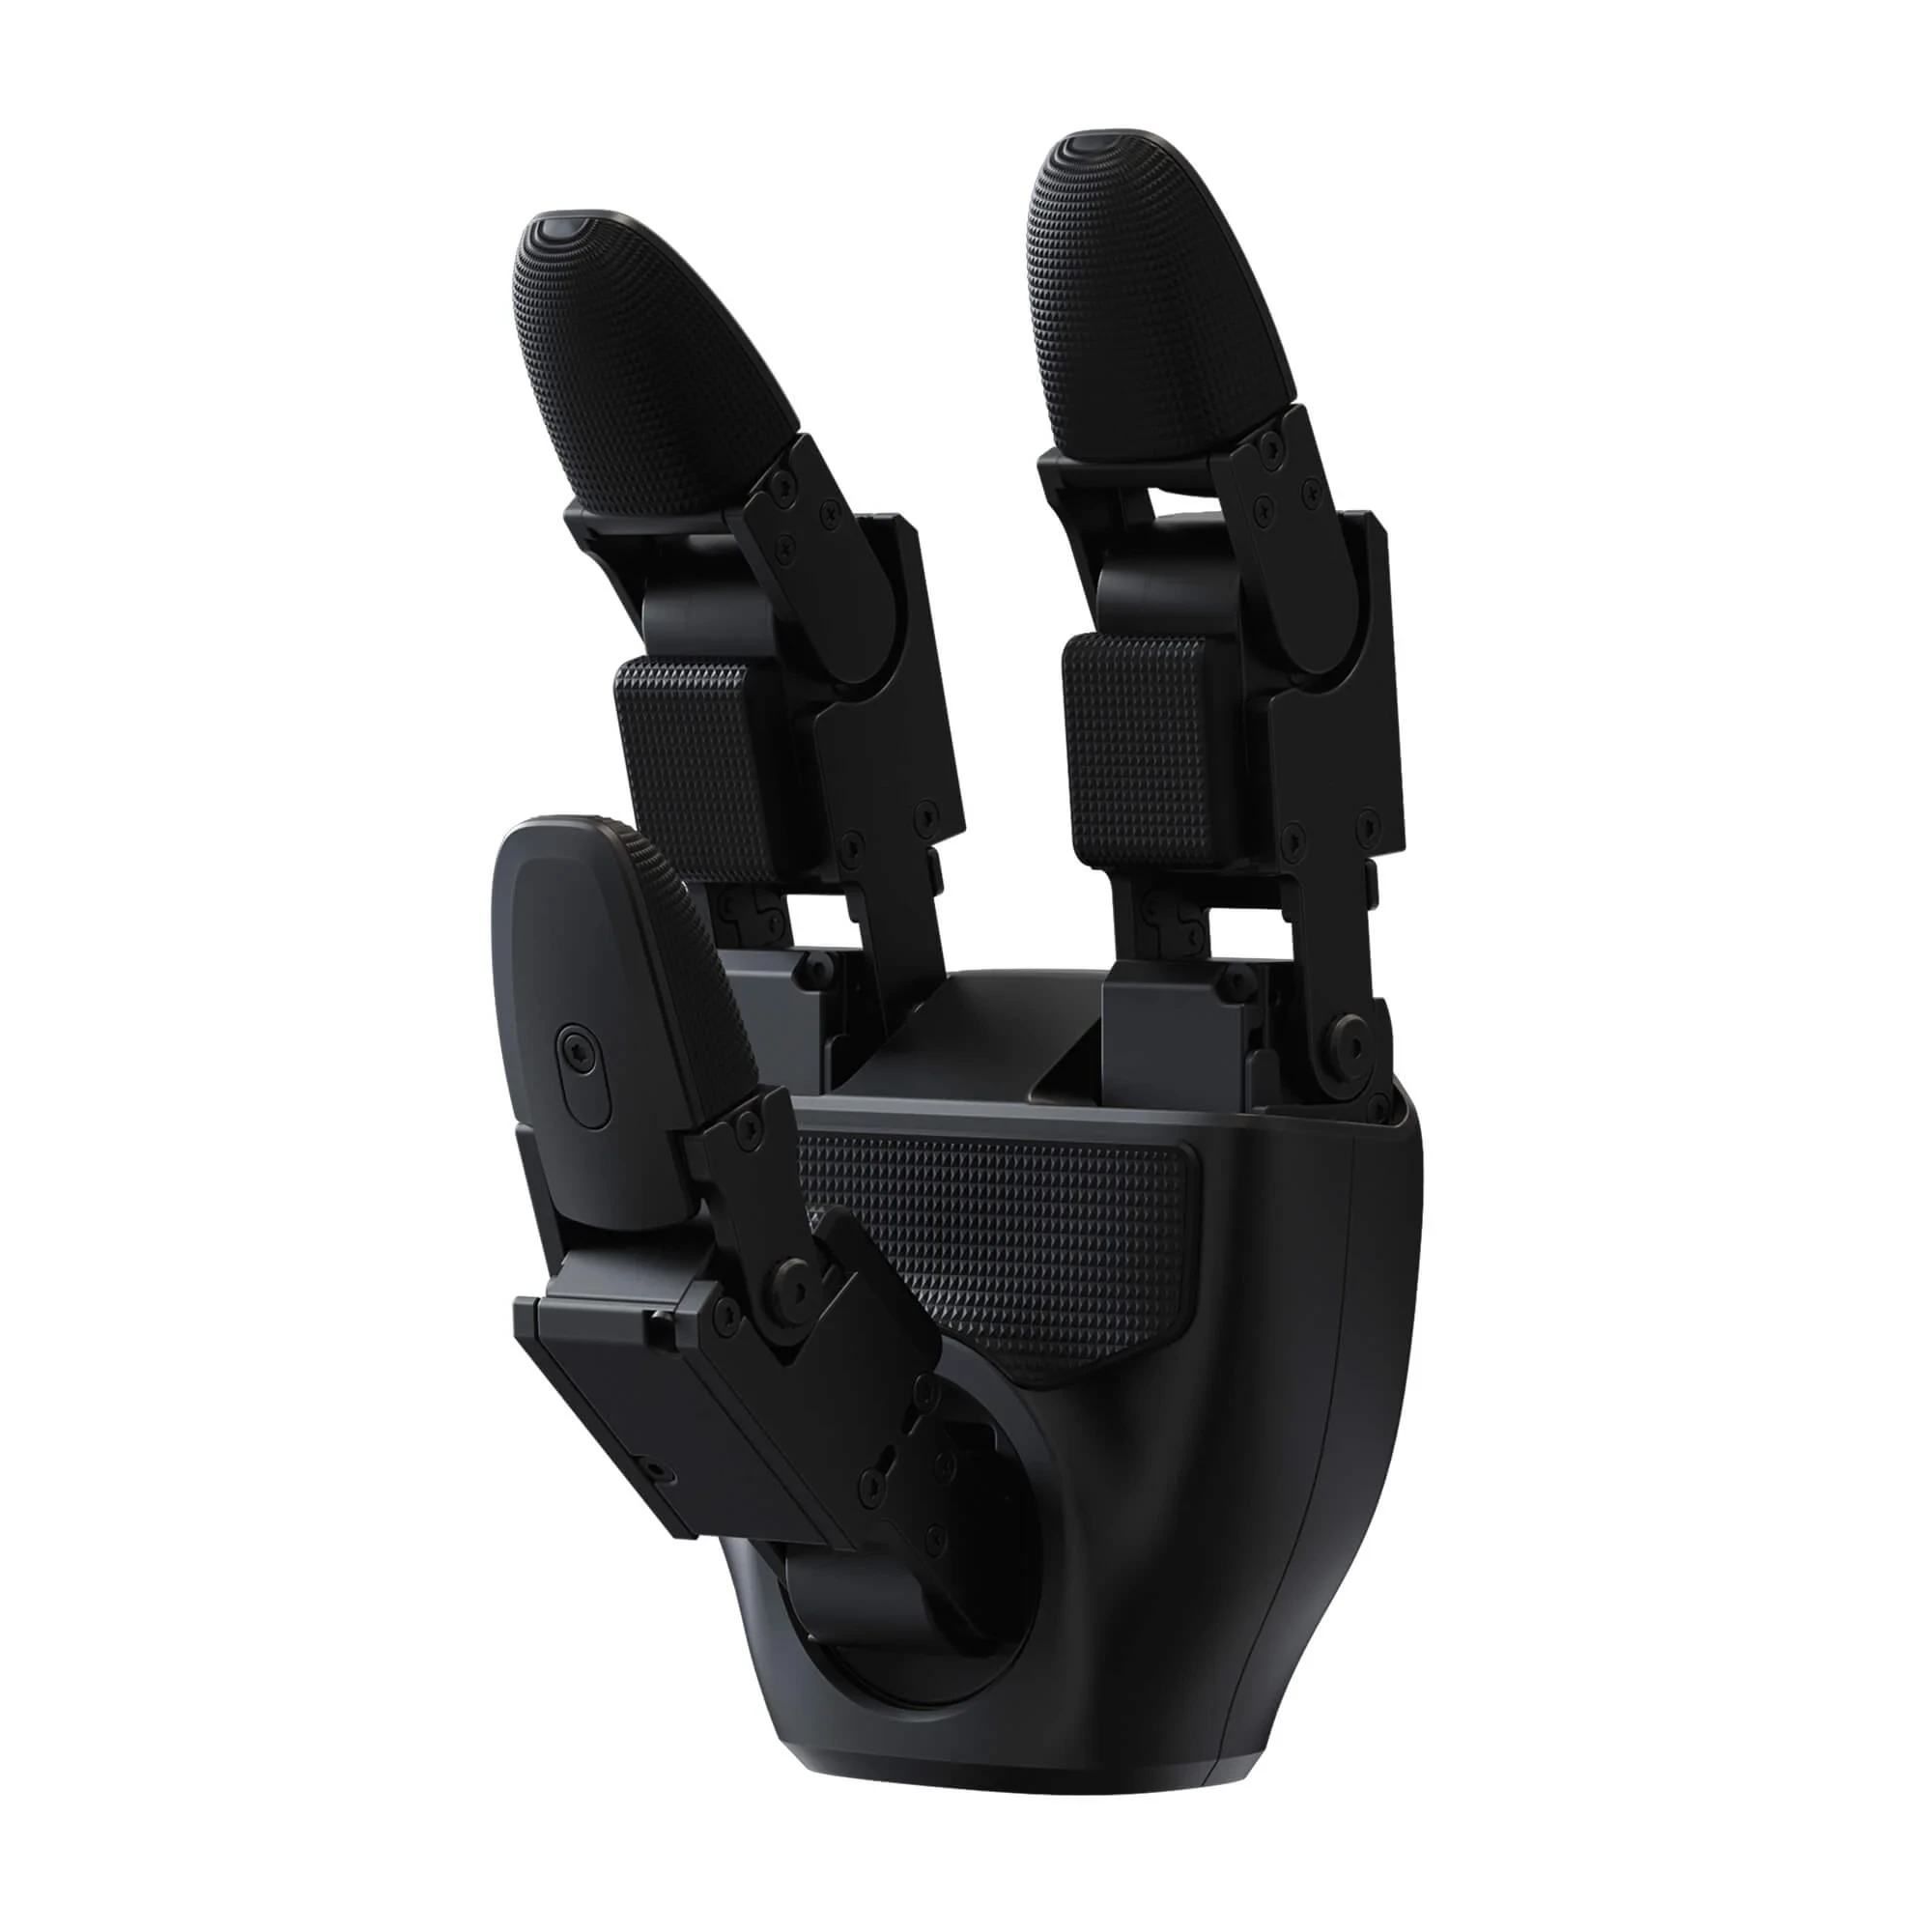
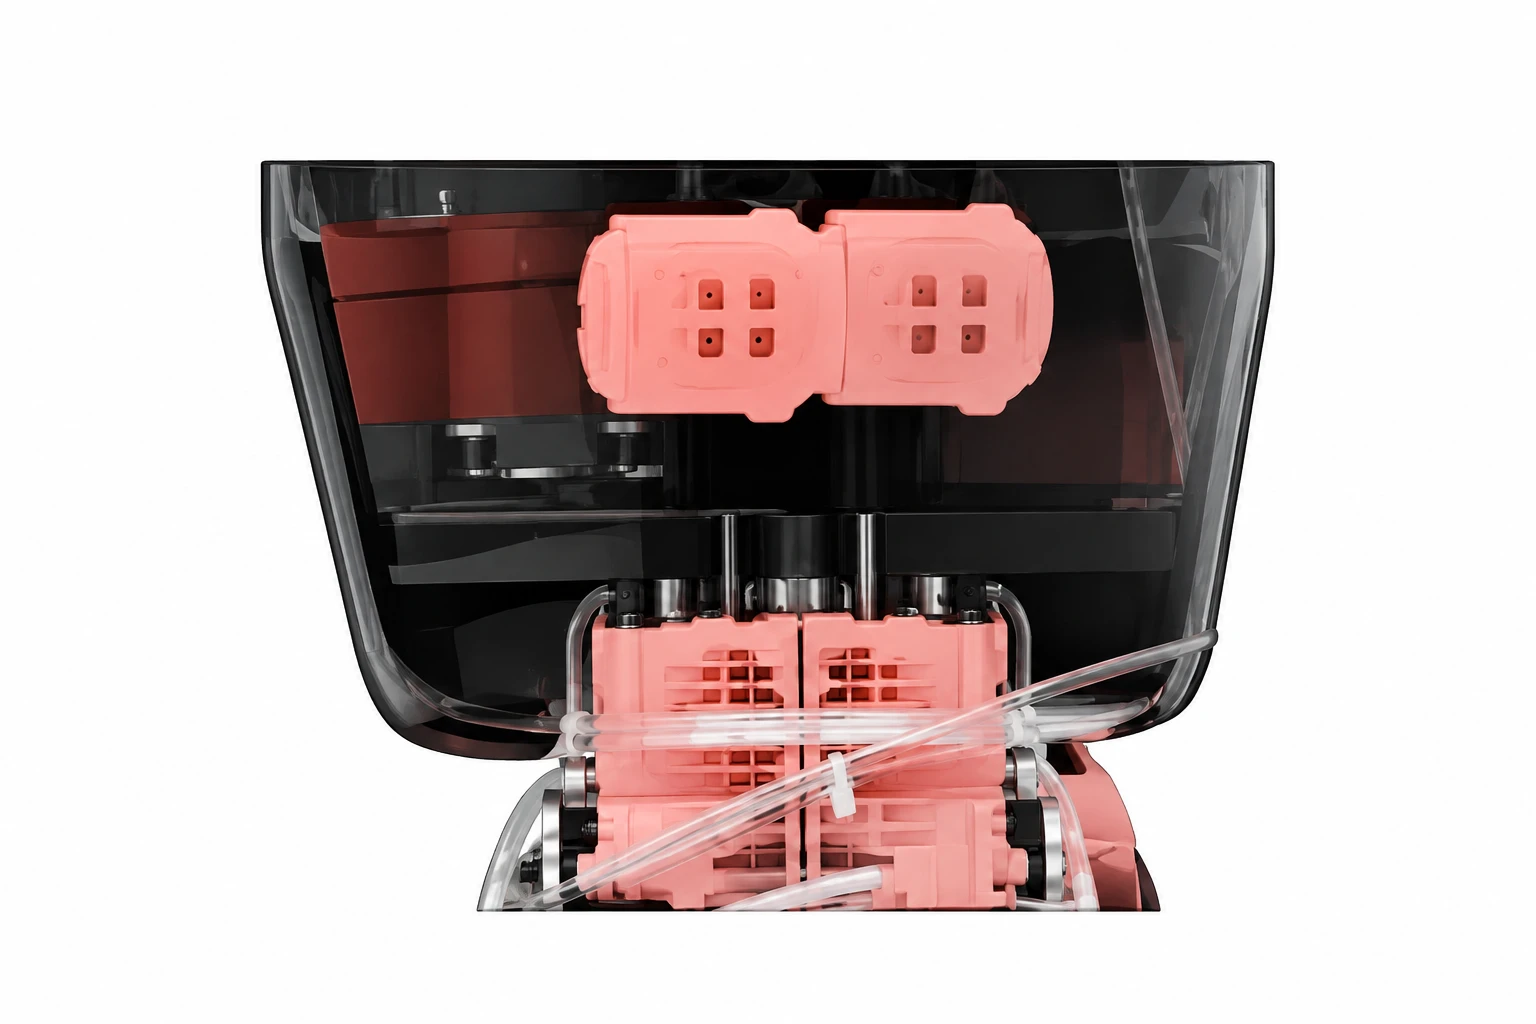
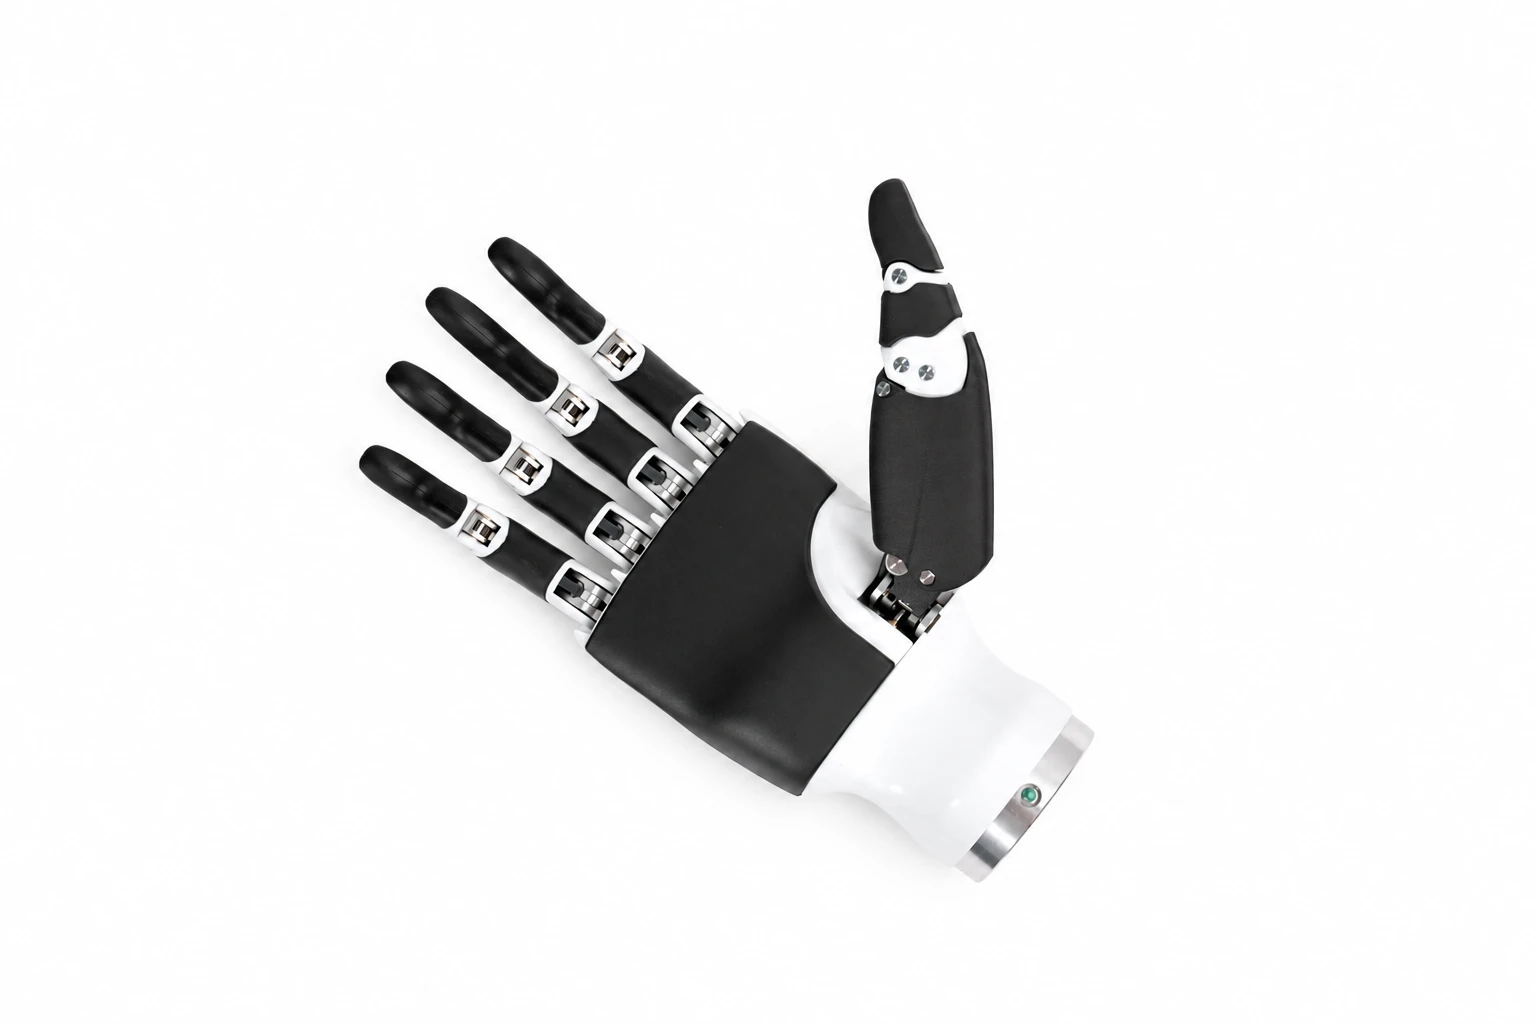
The Inspire RH56DFQ dexterous hand drives six active degrees of freedom across five fingers — two in the thumb and one in each of the four fingers — through six micro linear servo actuators acting on twelve joints. Force-position hybrid control lets the hand close on an object in under 0.4 seconds and hold it without driving through it, and the joints self-lock when power is cut, so a gripped object stays put.
Six integrated pressure sensors report contact force at 0.5 N resolution, and every actuator reports its position — so grasping pipelines get force feedback and repeatable motion (±0.20 mm repeatability) over RS485 or CAN, with ROS/ROS2 support for integration work.
- 6 active DoF, 12 joints across five fingers
- Force-position hybrid control — closes in under 0.4 s
- 6 pressure sensors with 0.5 N force resolution
RH56DFQ vs RH56DFX: Which Inspire Hand to Buy
Inspire makes two closely related five-finger hands. This page is the Inspire RH56DFQ dexterous hand — the version fitted to the higher G1 EDU tiers, the H1 and the H2 (H2-D configuration). The RH56DFX is the general-integration version of the same hand family, and the tactile-sensing RH56DFTP has its own page.
| RH56DFQ (this page) | RH56DFX | |
|---|---|---|
| Typical use | Unitree G1 EDU (U2 and higher) · H1 / H1-2 · H2 (H2-D) | General humanoid and prosthesis integration |
| Degrees of freedom | 6 active — 12 joints | 6 active — 12 joints (DFXW adds a 2-DoF wrist) |
| Max grip force | Thumb 6 N · four fingers 4 N | Thumb 15 N · four fingers 10 N |
| Four-finger flexion speed | 570°/s | 260°/s |
| Communication | RS485 or CAN · ROS/ROS2 | RS485 · ROS |
| Best for | G1 EDU / H1 / H2 (H2-D) manipulation, fast teleoperation | Custom platforms needing higher grip force or a wrist |
How to Tell the Left Hand from the Right
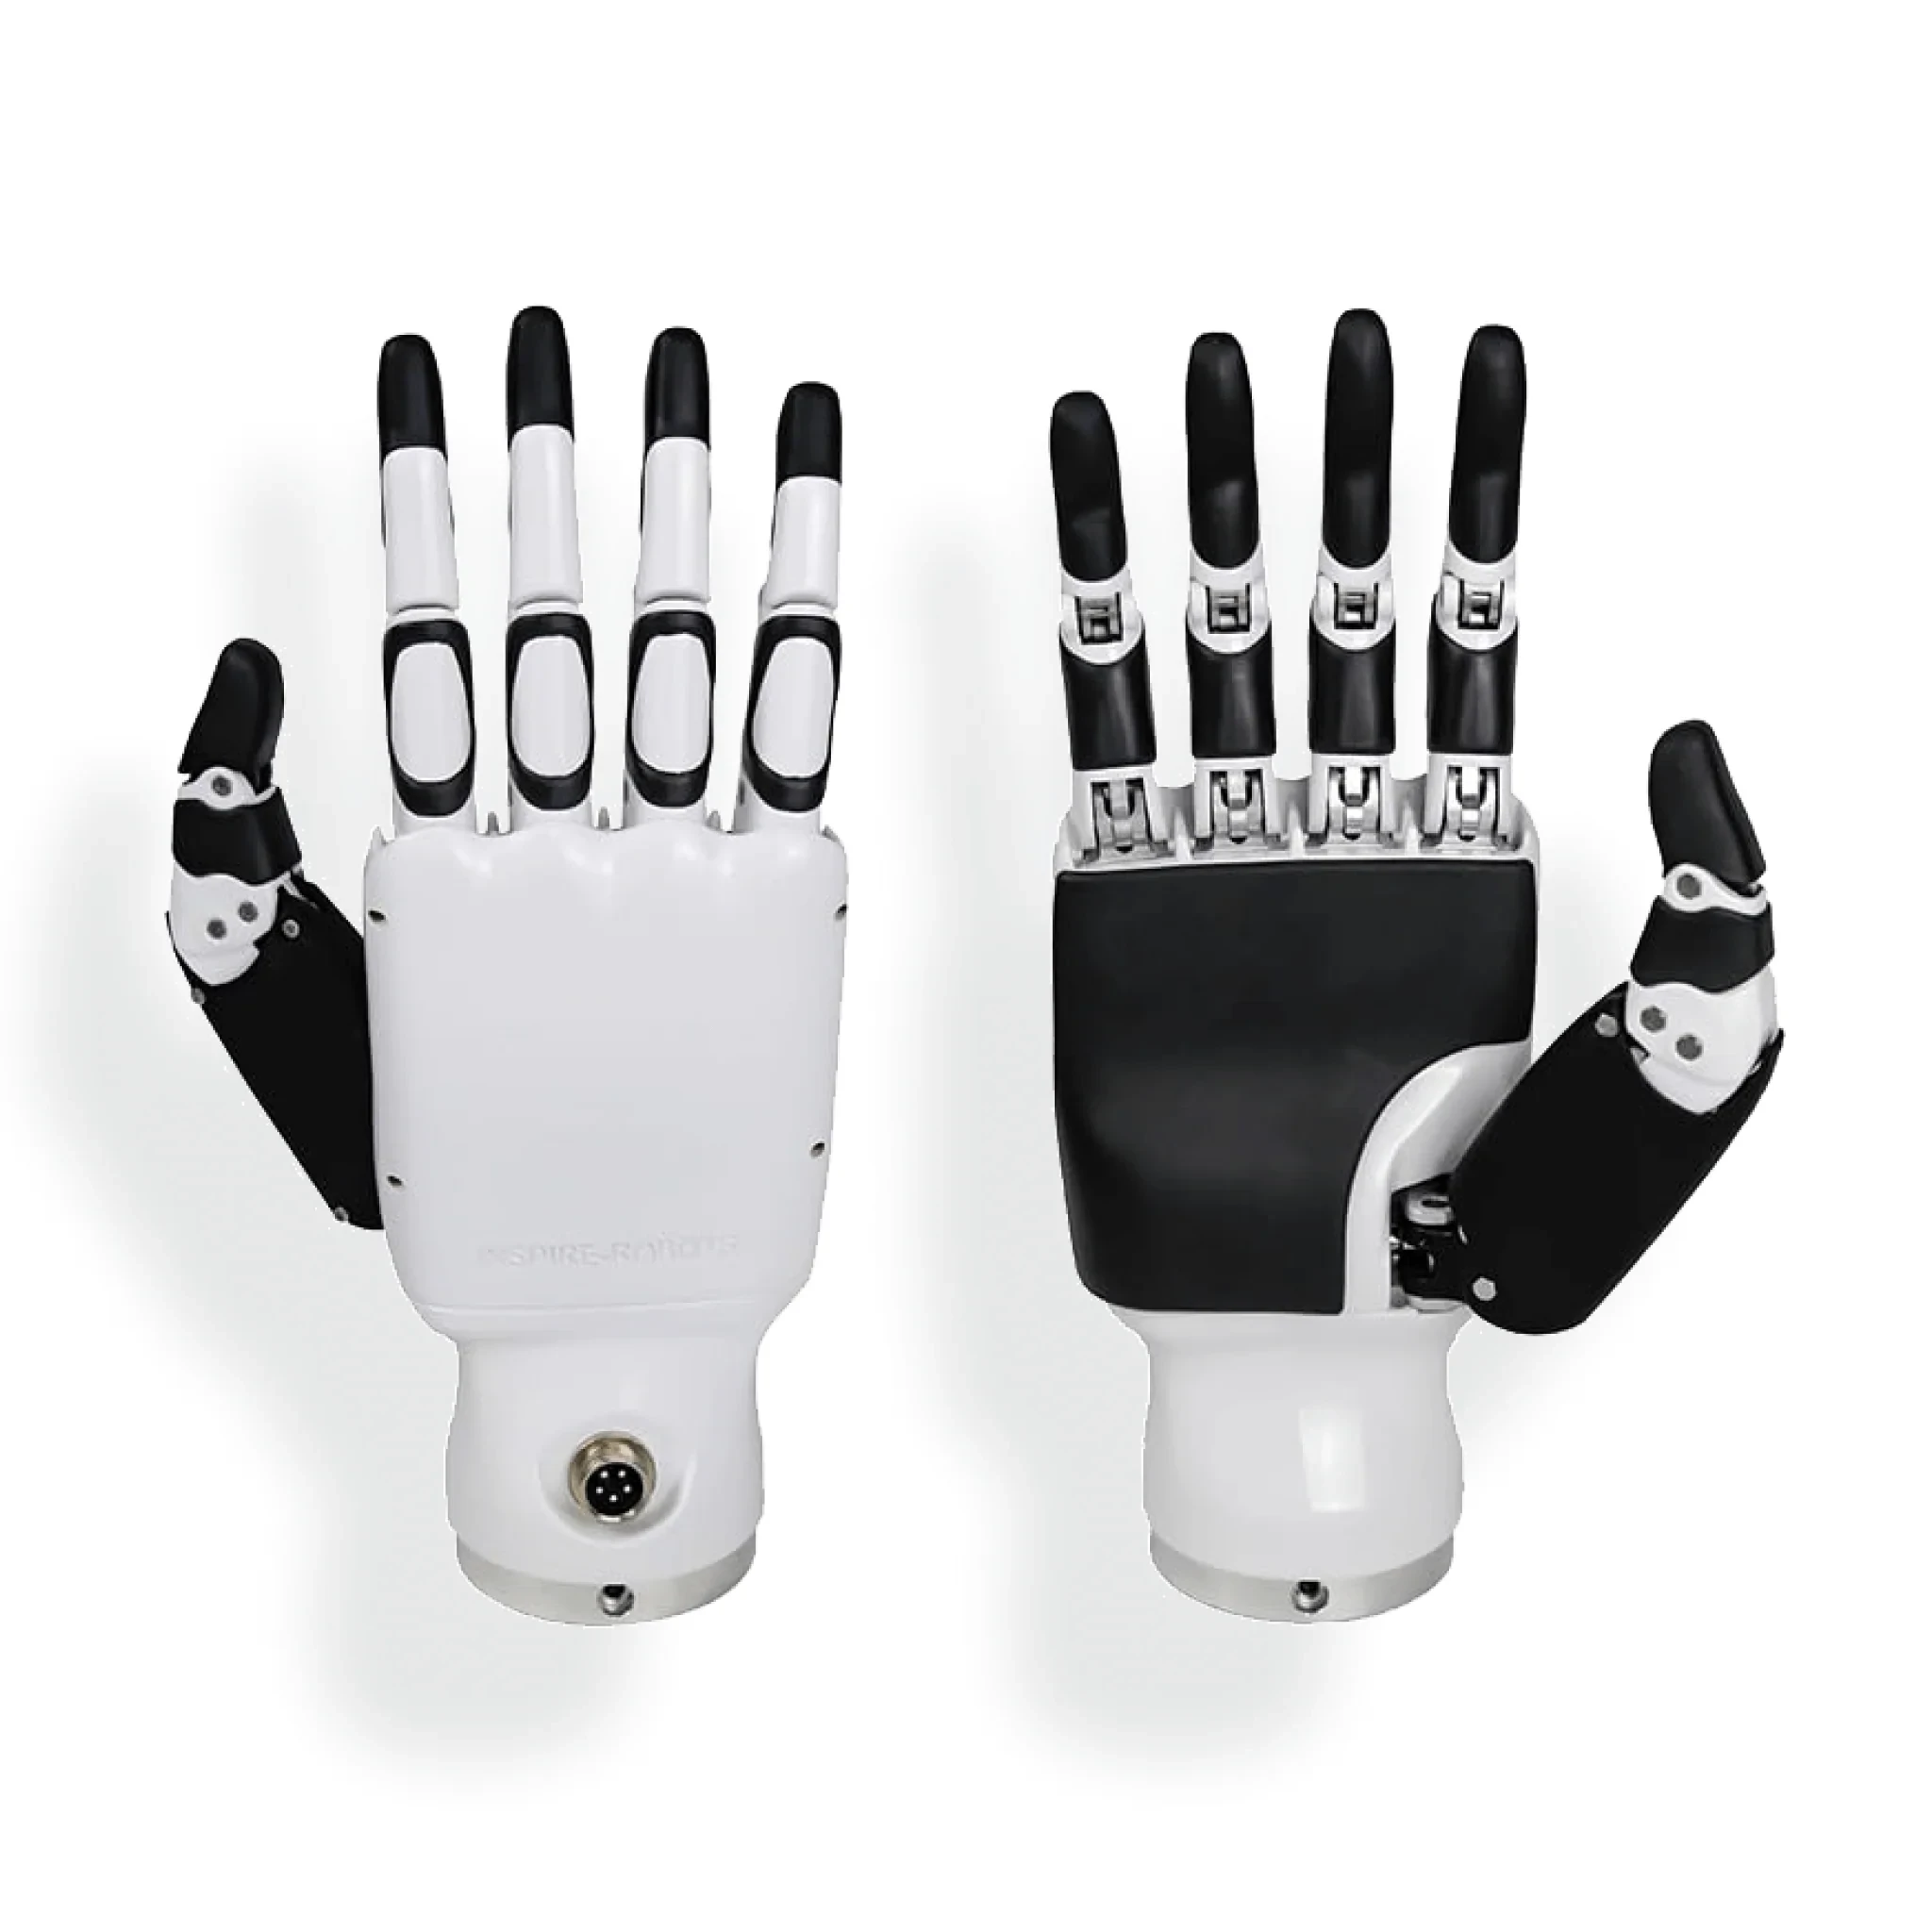
The Inspire RH56DFQ dexterous hand is sold per hand, and the two sides are mirror builds — they are not interchangeable. The model number carries the side: RH56DFQ-2L is the left hand, RH56DFQ-2R is the right hand.
Order a single hand for a replacement or for single-arm tasks. For bilateral manipulation on a G1 EDU or an H1, plan a pair — one RH56DFQ-2L and one RH56DFQ-2R, added as two line items on your quote.
- RH56DFQ-2L = left hand · RH56DFQ-2R = right hand
- Left and right are mirror builds — not interchangeable
- A full G1 EDU or H1 setup uses two — one left, one right
The Five-Finger Force-Control Hand for Unitree Humanoids
The Inspire RH56DFQ dexterous hand is the five-finger hand option for the G1 EDU family from the U2 tier up — including the EDU Ultimate A, B and C configurations — and it is the hand fitted on the H2's dexterous-hand configuration (the H2-D). On the full-size H1 and H1-2 it is the force-control member of the Inspire RH56 family, the hand line Unitree's own H1 developer documentation integrates against; the tactile RH56DFTP is its sibling on the same robots.
Each hand ships with the wrist unit that mounts it to the robot's arm, and connects over RS485 or CAN with ROS/ROS2 support for integration work. Other members of the RH56 family — such as the RH56DFXW with its own actuated 2-DoF wrist — serve general integration projects outside this listing.
Specifications
| Left Hand | Right Hand | |
|---|---|---|
| Type | Five-finger force-controlled dexterous hand | Five-finger force-controlled dexterous hand |
| Model | RH56DFQ-2L — left hand | RH56DFQ-2R — right hand |
| Degrees of freedom | 6 active (thumb ×2, four fingers ×1 each) — 12 joints total | 6 active (thumb ×2, four fingers ×1 each) — 12 joints total |
| Actuation | 6 micro linear servo actuators | 6 micro linear servo actuators |
| Force sensing | 6 integrated pressure sensors | 6 integrated pressure sensors |
| Grip force resolution | 0.5 N | 0.5 N |
| Max grip force | Thumb 6 N · four fingers 4 N | Thumb 6 N · four fingers 4 N |
| Repeatability | ±0.20 mm | ±0.20 mm |
| Closing time | Under 0.4 s | Under 0.4 s |
| Thumb lateral rotation | > 65° | > 65° |
| Motion speed | Thumb side swing 235°/s · thumb flexion 150°/s · four-finger flexion 570°/s | Thumb side swing 235°/s · thumb flexion 150°/s · four-finger flexion 570°/s |
| Control | Force–position hybrid control, power-off self-locking | Force–position hybrid control, power-off self-locking |
| Communication | RS485 or CAN · ROS/ROS2 support | RS485 or CAN · ROS/ROS2 support |
| Operating voltage | DC 12–48 V | DC 12–48 V |
| Weight | 540 g | 540 g |
| Fits | Unitree G1 EDU (U2 and higher tiers) · Unitree H1 / H1-2 · Unitree H2 (H2-D configuration) | Unitree G1 EDU (U2 and higher tiers) · Unitree H1 / H1-2 · Unitree H2 (H2-D configuration) |
| In the box | Inspire RH56DFQ-2L dexterous hand — left hand | Inspire RH56DFQ-2R dexterous hand — right hand |
Shipping & Service
The hand ships worldwide by DHL or FedEx in protective industrial packaging; exact transit time is confirmed with your quote.
Every unit is 100% quality-inspected before it ships, so it arrives in perfect working order.
Last updated: October 2026.
Frequently Asked Questions
Can't find what you're looking for? Contact our