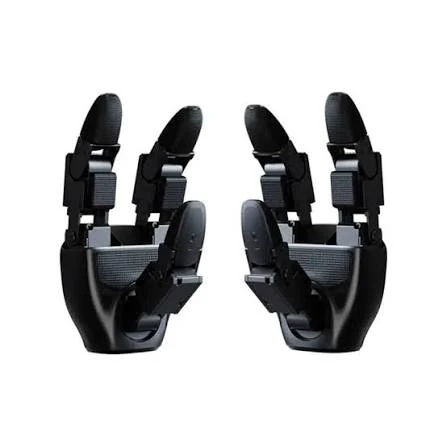
Unitree Dex3-1 Dexterous Hand
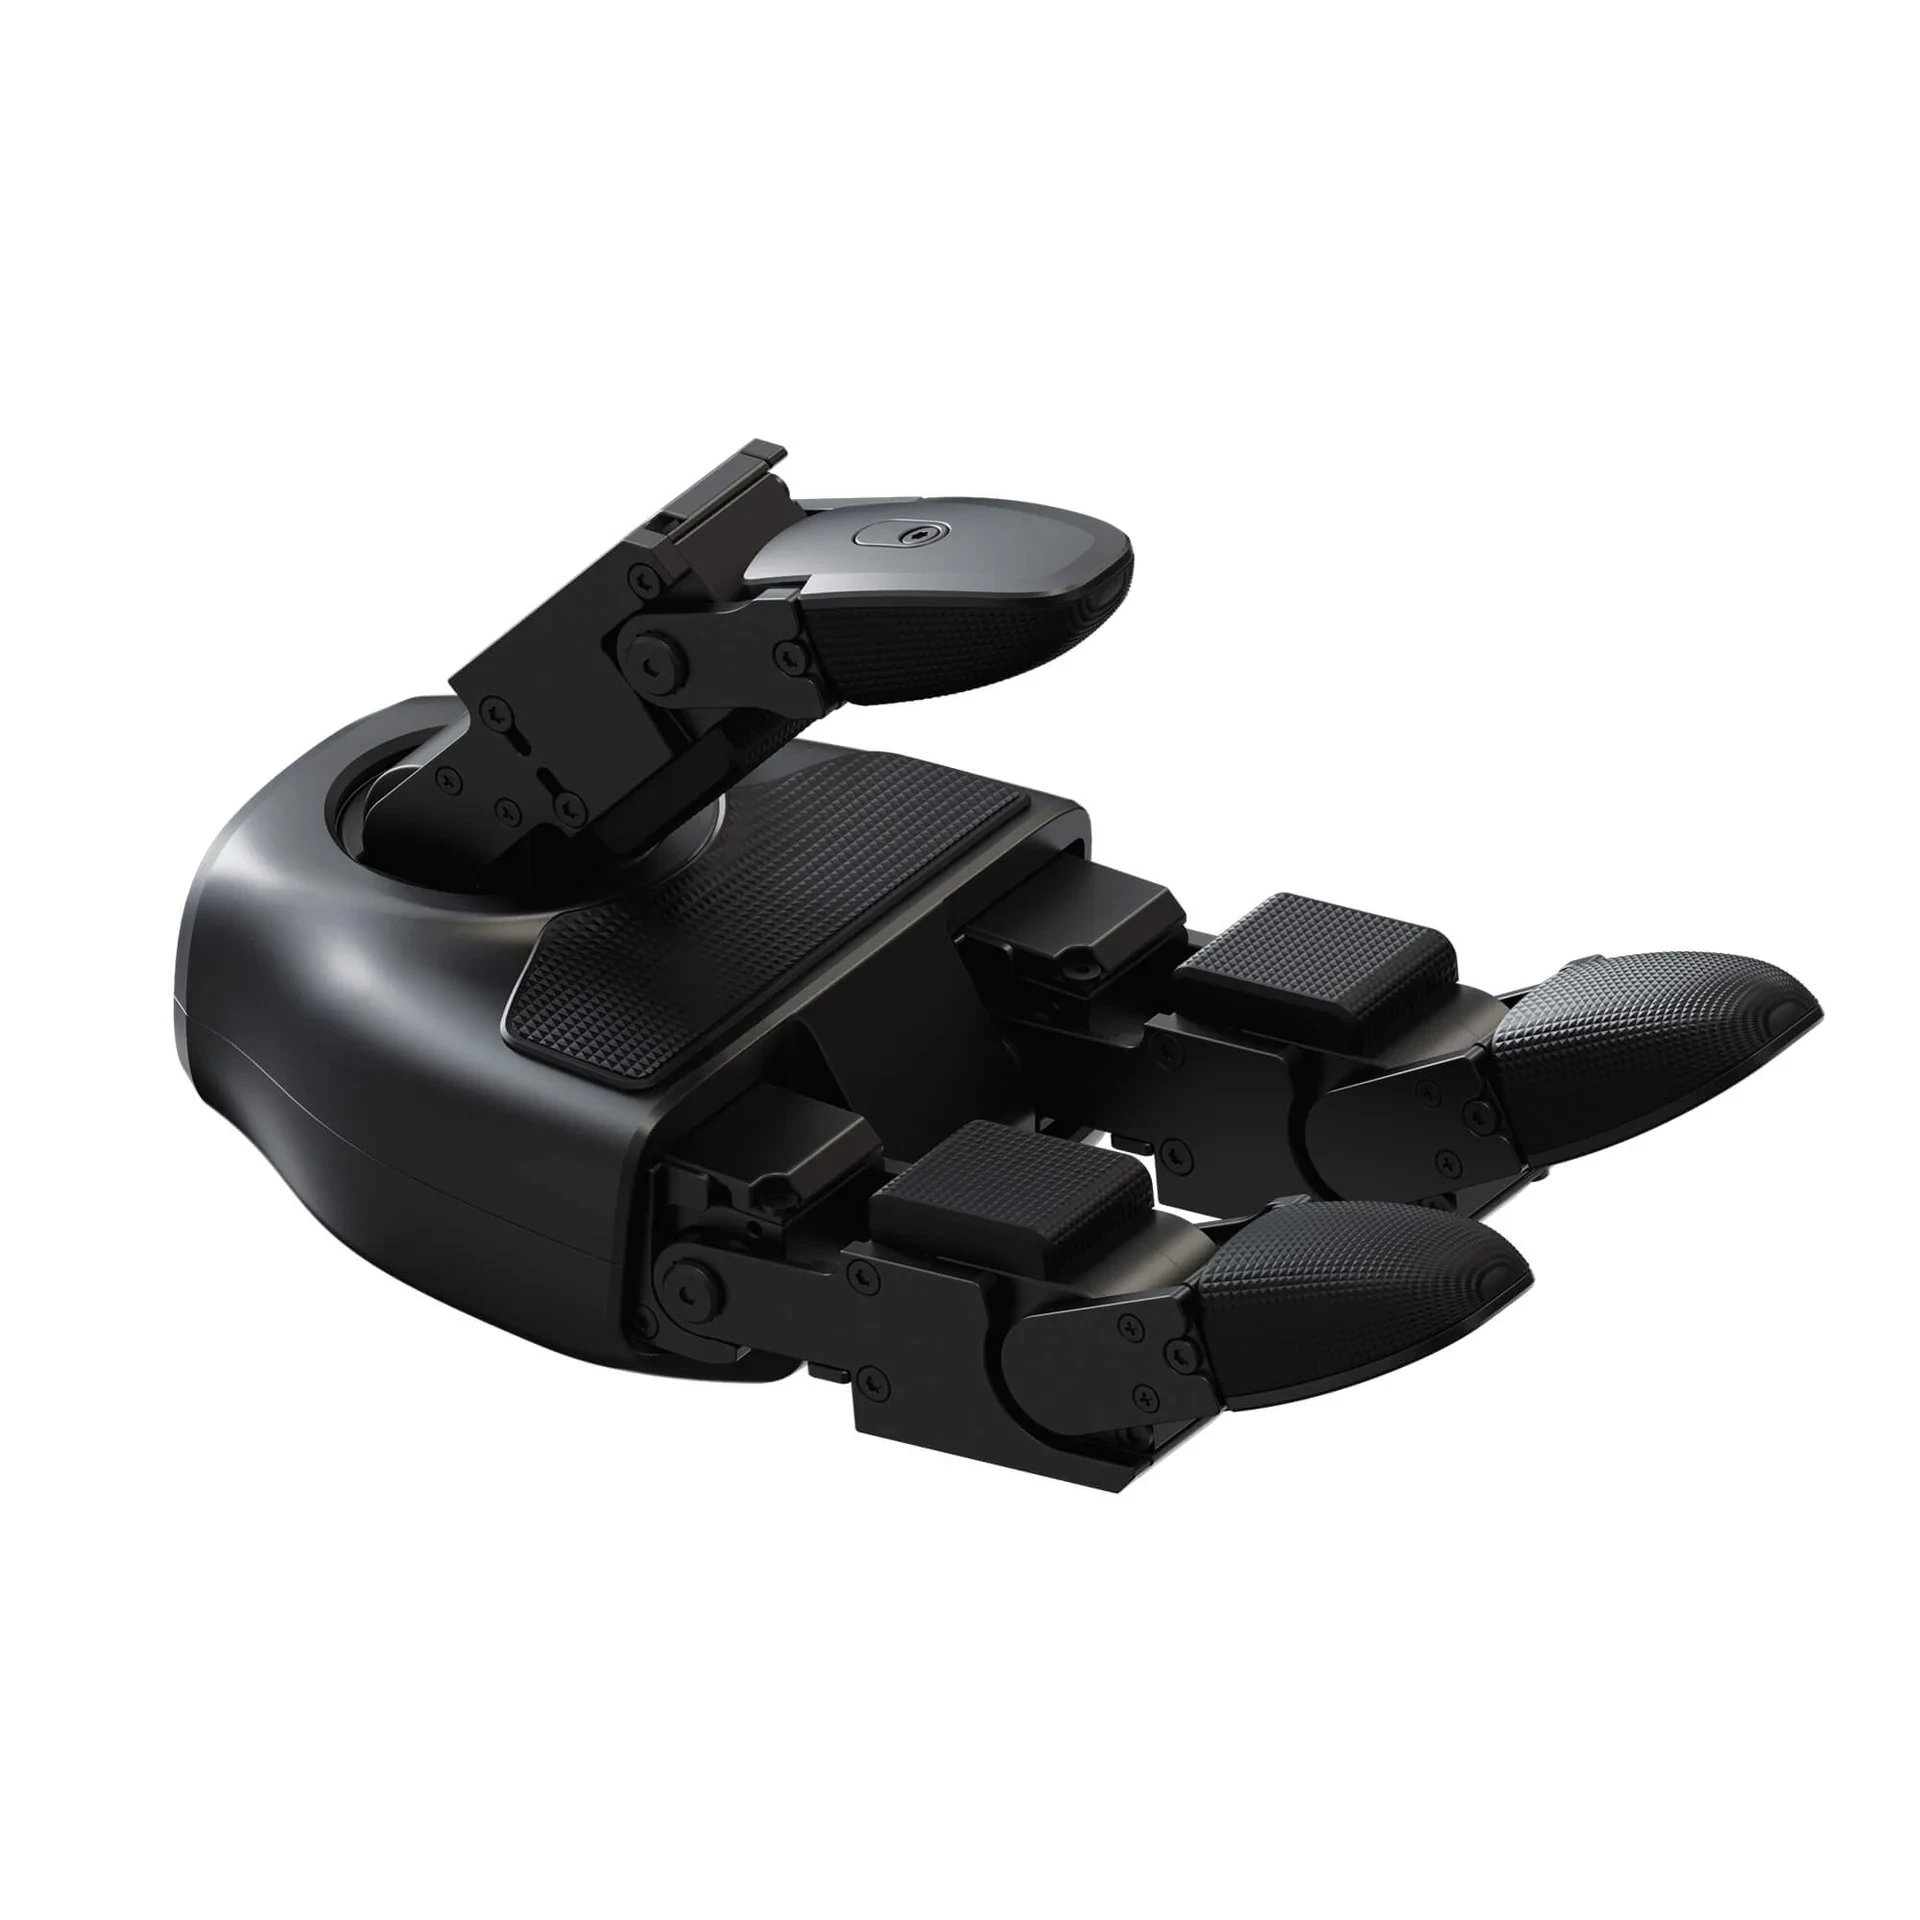
Unitree Dex3-1 dexterous hand — a three-finger, force-controlled hand for the G1 EDU and H2. This listing is the left hand; the right hand is one click away.
- Unitree G1 EDU
- Unitree H2
About the Unitree Dex3-1 Dexterous Hand
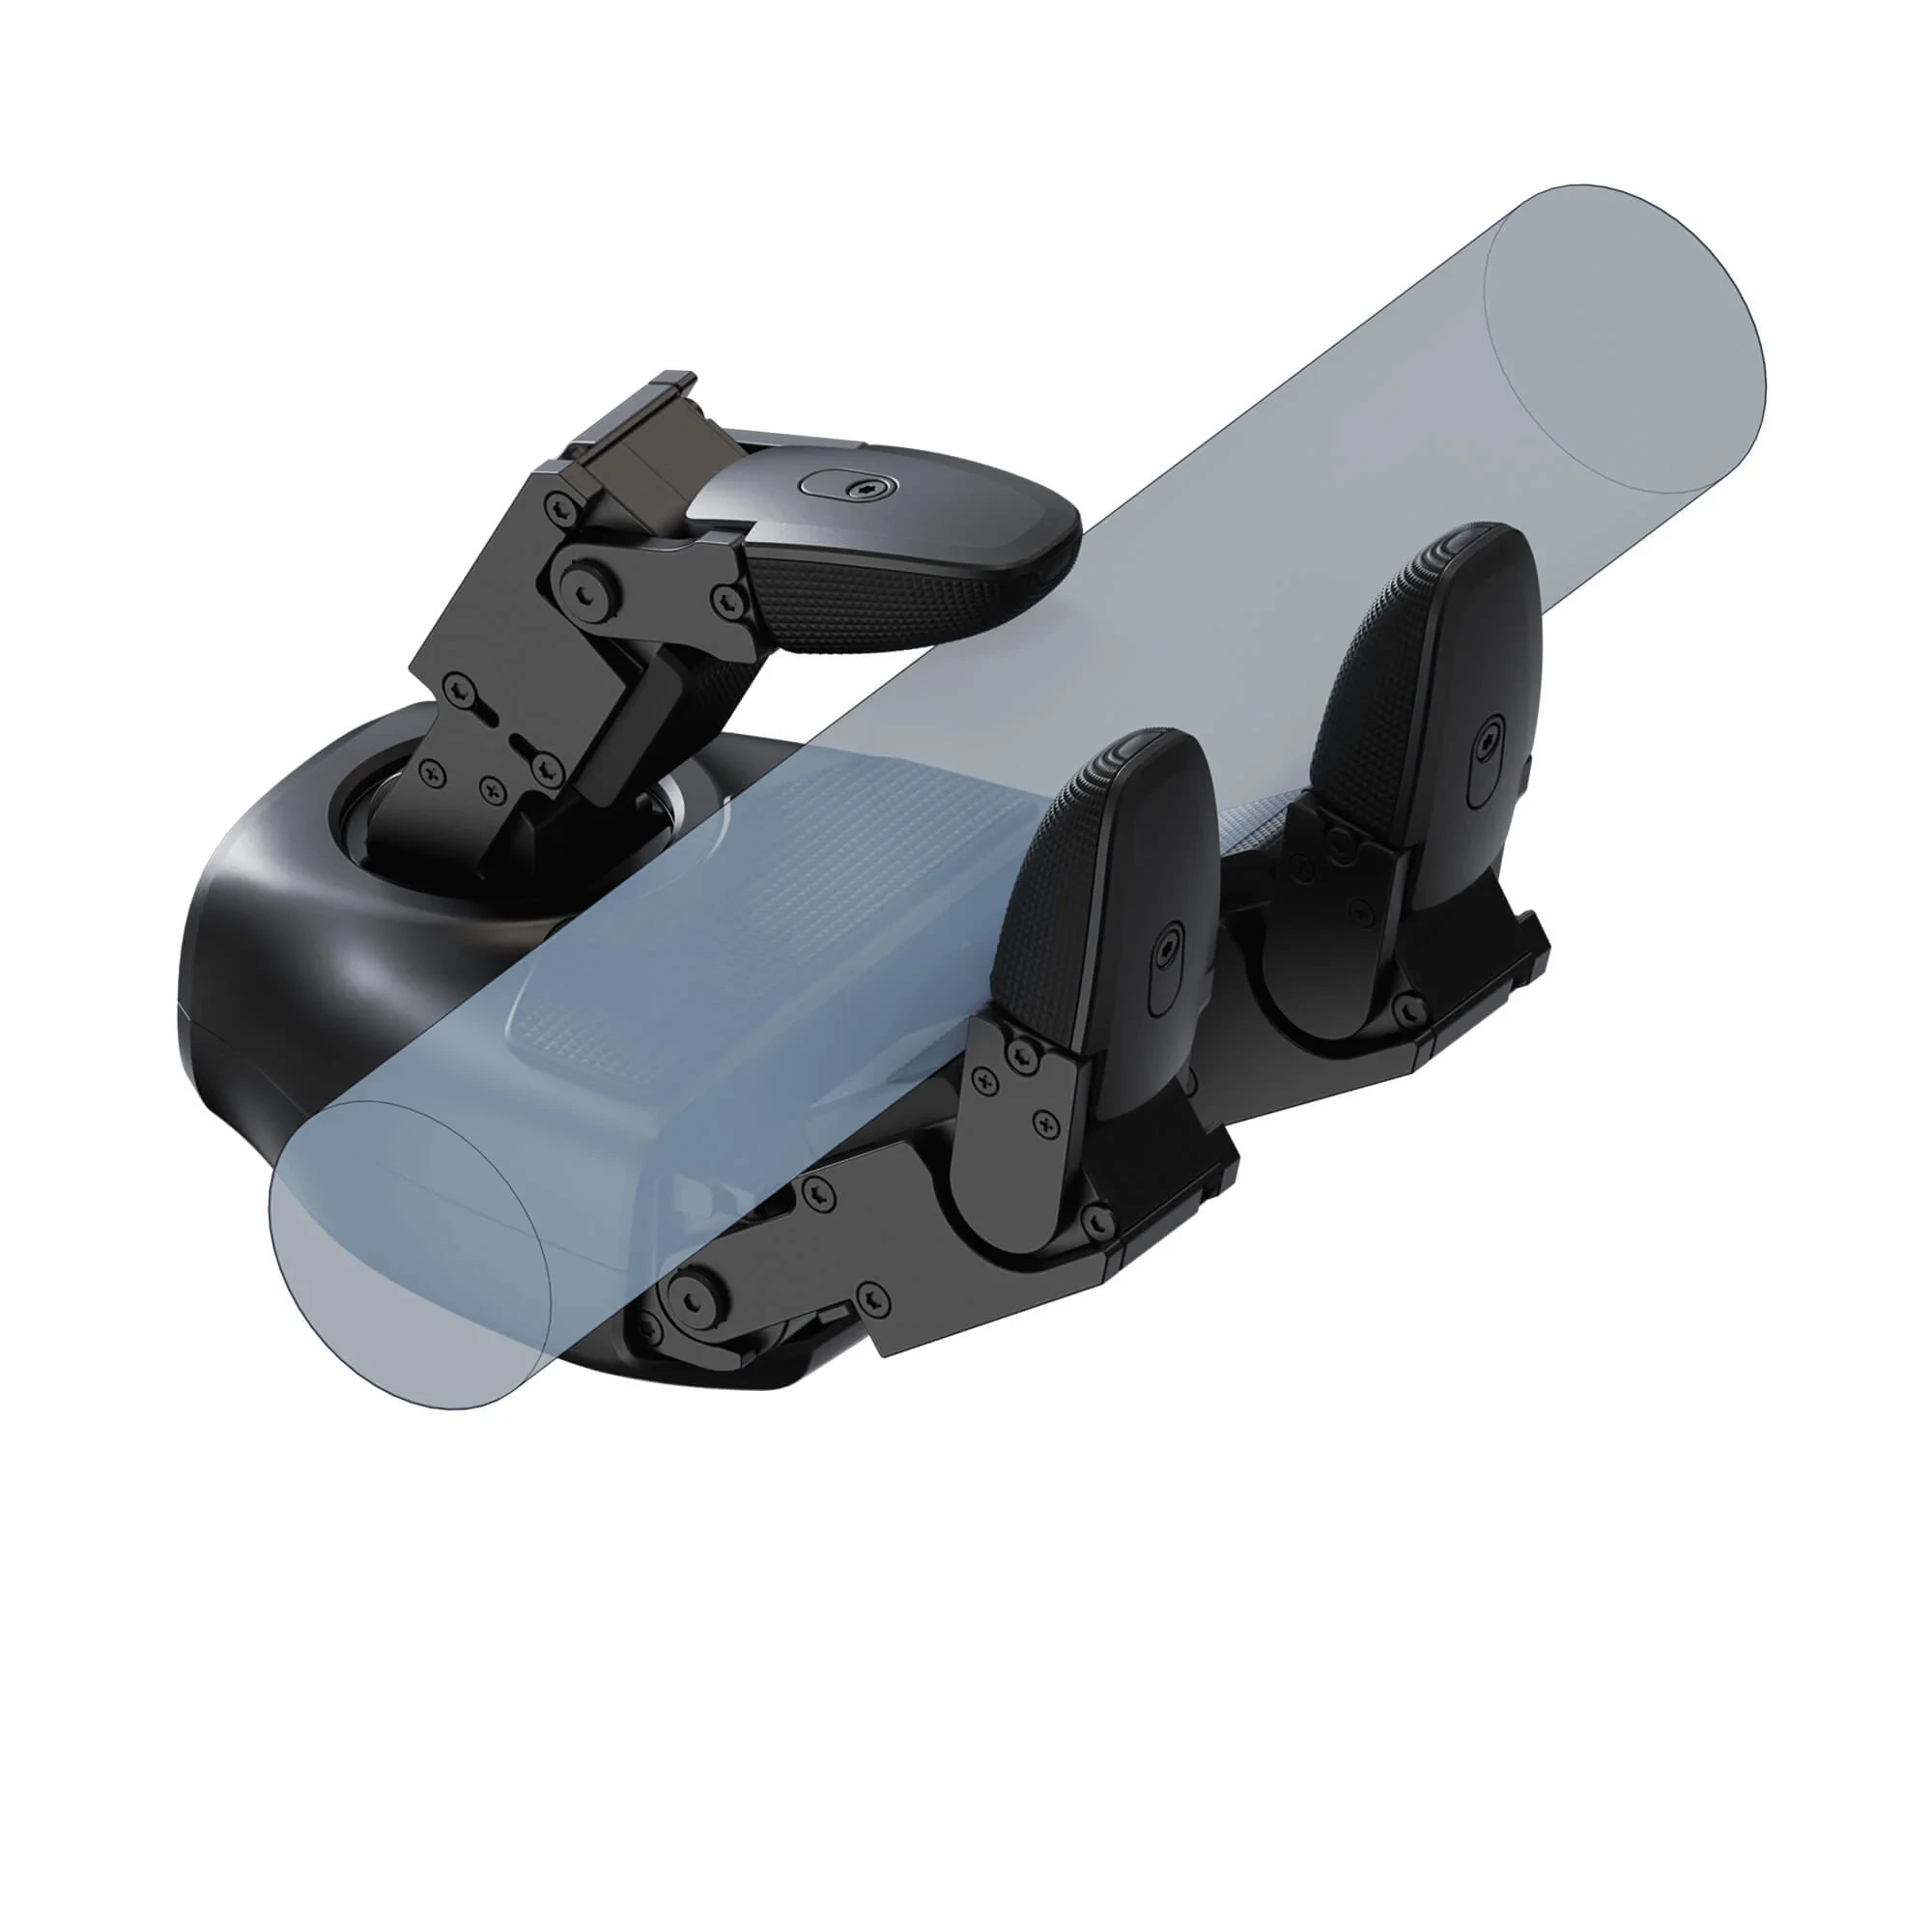
The Unitree Dex3-1 dexterous hand is the three-finger, force-controlled end effector for the Unitree G1 EDU and H2 humanoids. It is sold per hand — left or right — for new robot configurations, replacements and development work.
For labs and developers, it is the manipulation option behind grasping work on the G1 EDU and H2: pick-and-place, tool handling, and collecting demonstration data through teleoperation and retargeting.
Seven Driven Joints, Force Control at 1,000 Hz
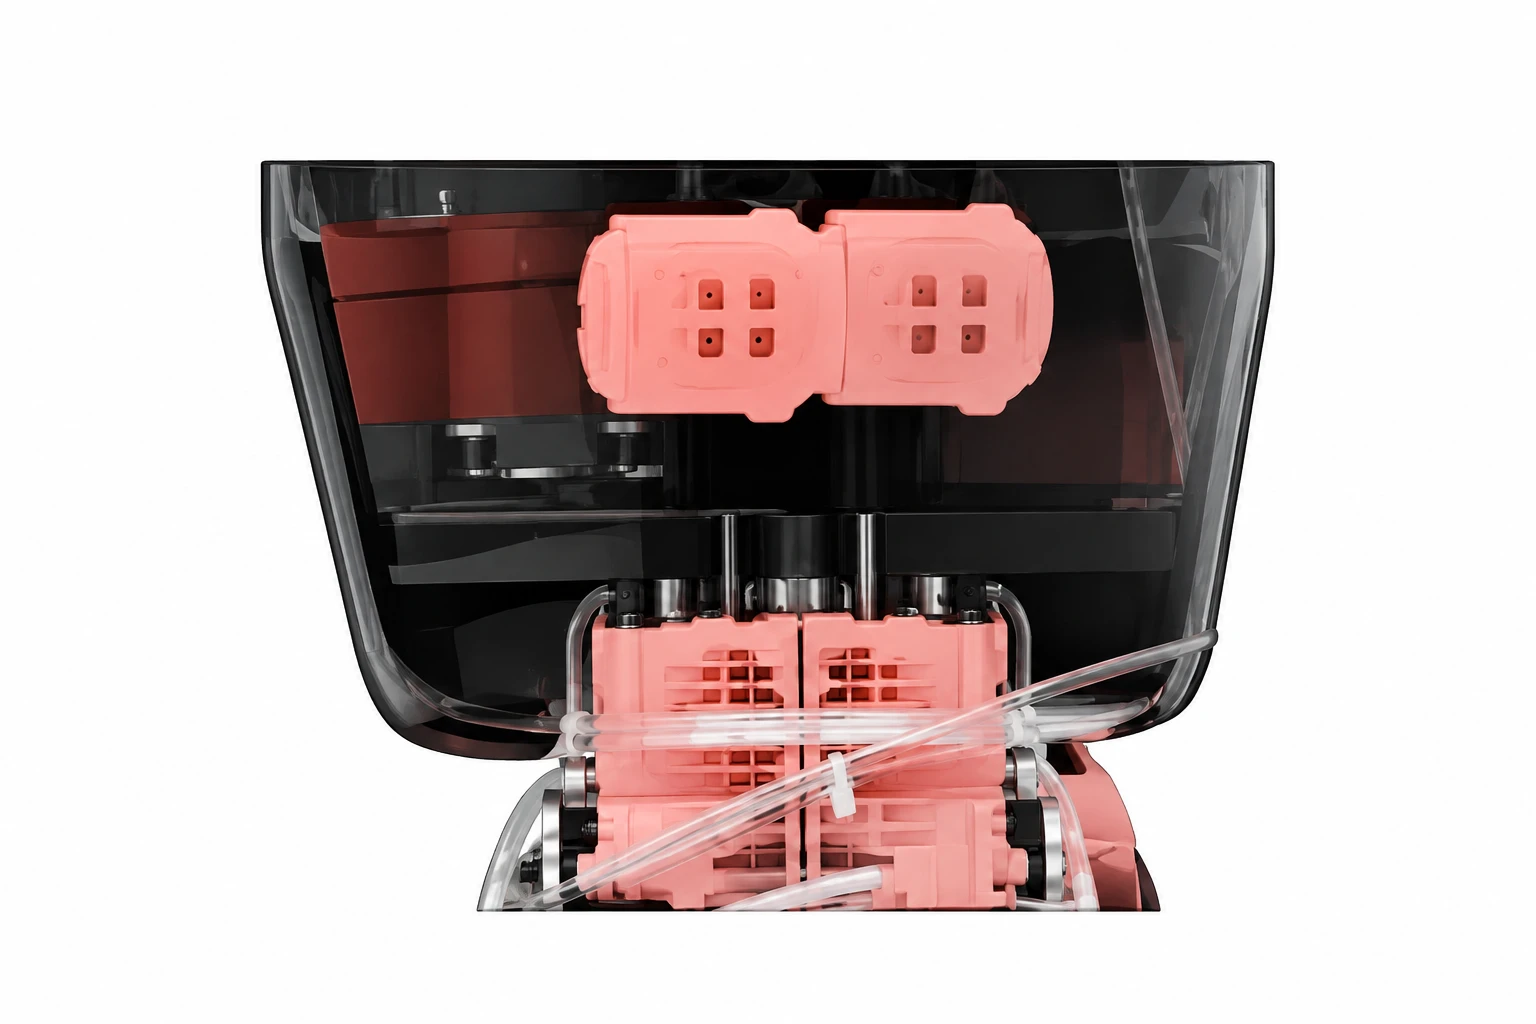
The Unitree Dex3-1 dexterous hand drives seven joints across three fingers — three in the thumb, two each in the index and middle fingers. Six joints are direct-drive micro brushless force-control units and one is gear-driven, all running force-position hybrid control at 1,000 Hz.
Every joint reports position, velocity, torque and temperature, and stiffness and damping are programmable per joint — so the fingers comply when they meet an object instead of driving through it. That is what makes repeatable pinch and tripod grasps possible: ±2 mm fingertip repeatability, a 500 g grasping load, and 400 W of peak power for quick firmer grips.
- 7 DoF across three fingers — thumb ×3, index ×2, middle ×2
- Direct-drive force-control joints with torque feedback
- Programmable stiffness & damping for compliant contact
Standard vs Tactile: Which Dex3-1 to Buy
Unitree makes the Dex3-1 in two versions. This page is the standard version — the tactile version adds a sensor skin on the same hand.
| Standard (this page) | Tactile | |
|---|---|---|
| Force control | 7-DoF hybrid force/position control | Same 7-DoF force-control stack |
| Tactile sensing | 33 pressure sensors across palm, finger pads and fingertips | |
| Feedback data | Joint position, velocity, torque, temperature | Adds pressure-array and IMU data |
| Best for | Grasping pipelines, teleoperation, replacement | Contact-rich research — slip detection, force estimation, tactile policy training |
| Sold as | Per hand — left or right | Per hand — left or right |
How to Tell the Left Hand from the Right
The Dex3-1 is sold per hand, and the left and right hands are mirror builds — they are not interchangeable. To identify a hand in the lab, check the engraving at the base of the thumb: L for left, R for right. The power cable also exits toward the hand's own side.
Order a single hand for a replacement or for single-arm tasks. For bilateral manipulation on the G1 EDU or H2, plan a pair — one left hand and one right hand, added as two line items on your quote.
- L / R engraved at the base of the thumb
- Cable exits toward the hand's own side
- A full two-arm setup (G1 EDU, H2) uses two — one left, one right
The Dexterous-Hand Option for the G1 EDU and H2
The Unitree Dex3-1 dexterous hand is the three-finger hand option Unitree lists for the G1 EDU family, and it fits every G1 EDU configuration from the U1 tier up. On the H2 it is the three-finger member of the dexterous-hand options in Unitree's official H2 specification. The hand mounts at the wrist interface and connects over USB.
The R1 EDU and the G1-D take their own dedicated Dex3-1 packages, which add a wrist-mounted RGB camera — this listing is the standard hand for the G1 EDU and H2.
Specifications
| Left Hand | Right Hand | |
|---|---|---|
| Type | Three-finger force-controlled dexterous hand | Three-finger force-controlled dexterous hand |
| Hand | Left (L engraved at the base of the thumb) | Right (R engraved at the base of the thumb) |
| Version | Standard — without tactile sensor array | Standard — without tactile sensor array |
| Degrees of freedom | 7 — thumb ×3 · index ×2 · middle ×2 | 7 — thumb ×3 · index ×2 · middle ×2 |
| Actuation | 6 direct-drive micro brushless joints + 1 gear-driven joint | 6 direct-drive micro brushless joints + 1 gear-driven joint |
| Weight | 710 g | 710 g |
| Dimensions | 175 × 88 × 77 mm (flat state) | 175 × 88 × 77 mm (flat state) |
| Thumb joint range | J0 −60°~60° · J1 −35°~60° · J2 0~100° | J0 −60°~60° · J1 −35°~60° · J2 0~100° |
| Index joint range | J0 0~90° · J1 0~100° | J0 0~90° · J1 0~100° |
| Middle joint range | J0 0~90° · J1 0~100° | J0 0~90° · J1 0~100° |
| Fingertip repeatability | ±2 mm | ±2 mm |
| Max grasping load | 500 g (5 cm round rigid object, palm facing down or sideways) | 500 g (5 cm round rigid object, palm facing down or sideways) |
| Peak power | 400 W (3 s max) | 400 W (3 s max) |
| Operating voltage | 12–58 V | 12–58 V |
| Static current | 0.2 A @ 58 V | 0.2 A @ 58 V |
| Max current | 10 A | 10 A |
| Communication | USB 2.0 · 1,000 Hz | USB 2.0 · 1,000 Hz |
| Joint feedback | Position · velocity · torque · temperature; adjustable stiffness & damping | Position · velocity · torque · temperature; adjustable stiffness & damping |
| Joint modules | F-1515-108 / F-1515-214 — 45 g, rotor absolute encoder | F-1515-108 / F-1515-214 — 45 g, rotor absolute encoder |
| Operating temperature | −20 °C to 60 °C | −20 °C to 60 °C |
| Fits | Unitree G1 EDU (U1 and higher tiers) · Unitree H2 | Unitree G1 EDU (U1 and higher tiers) · Unitree H2 |
| In the box | Unitree Dex3-1 dexterous hand — left hand | Unitree Dex3-1 dexterous hand — right hand |
Shipping & Service
The hand ships worldwide by DHL or FedEx in protective industrial packaging; exact transit time is confirmed with your quote.
Every unit is 100% quality-inspected before it ships, so it arrives in perfect working order.
Last updated: September 2026.
Frequently Asked Questions
Can't find what you're looking for? Contact our