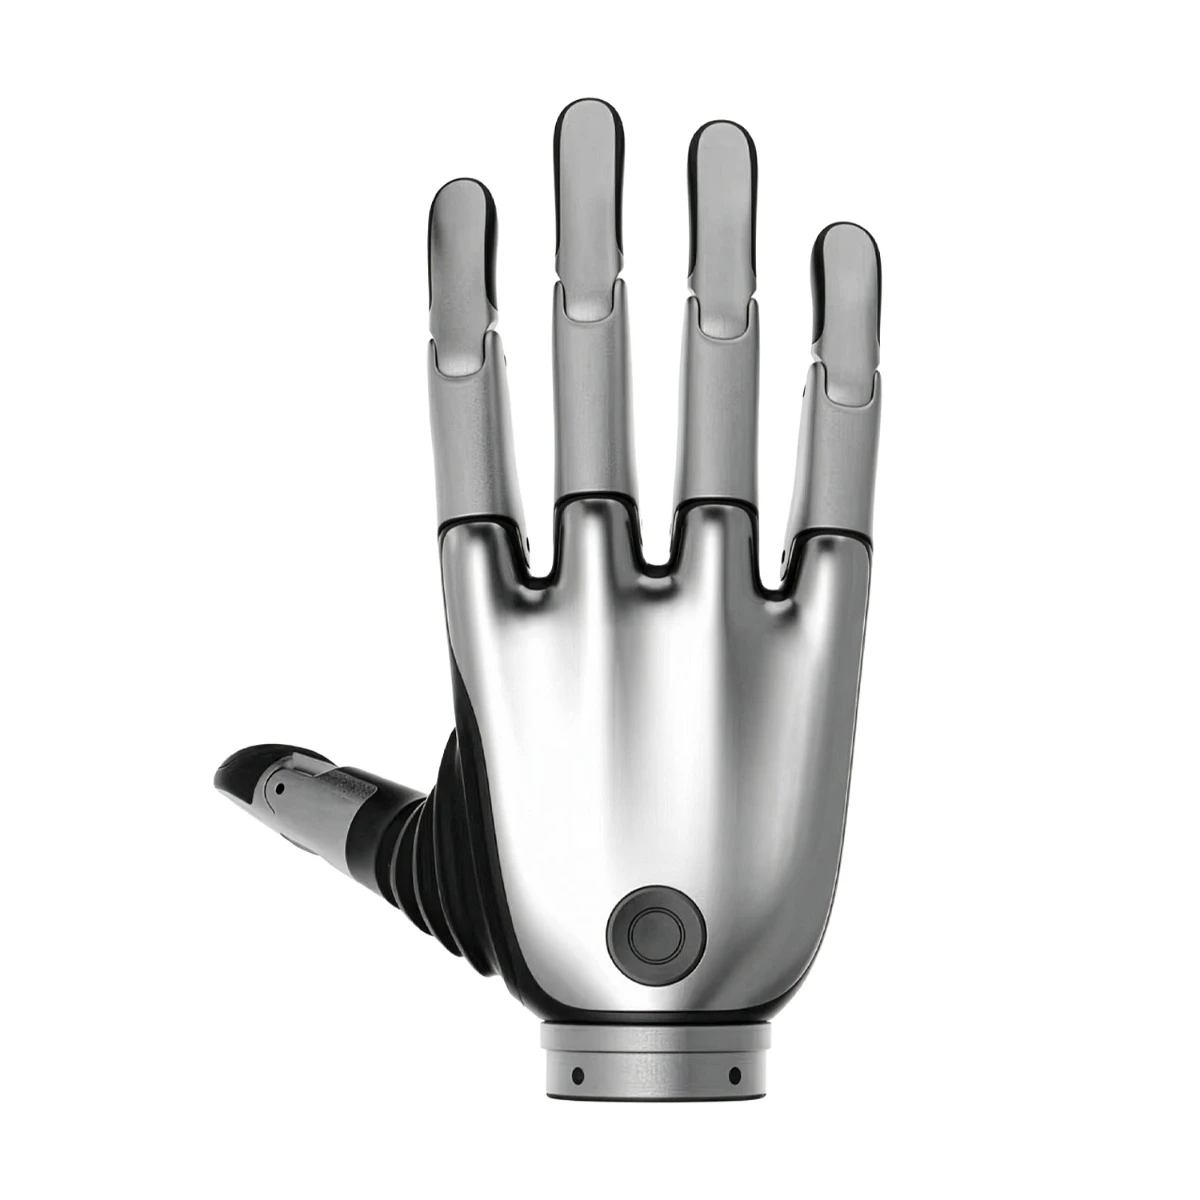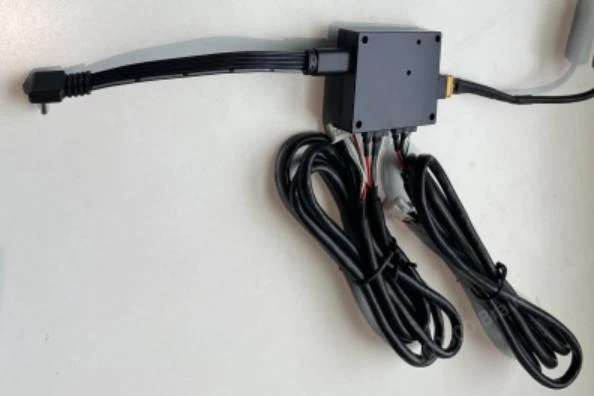
BrainCo Revo 2 485-USB Debugging Module
BrainCo Revo 2 485-USB debugging module — the dual-port RS485-to-USB converter kit for bench-debugging any Revo 2 hand (Basic, Pro or Touch) from your PC, including the Revo 2 Touch XTL/XTR hands fitted to Unitree R1.
- Unitree G1 (with Revo 2 hands)
- Unitree R1 (with Revo 2 Touch XTL/XTR)
- Unitree H2 (with Revo 2 hands)
About the BrainCo Revo 2 485-USB Debugging Module
The BrainCo Revo 2 485-USB debugging module is BrainCo's optional debugging tool for the Revo 2 dexterous hand: a dual-port RS485-to-USB converter kit that carries the hand's RS485 traffic to a PC over USB. On the bench it connects a Revo 2 hand to the stark-serialport SDK, so the position, speed and current commands you would otherwise route through the robot can be exercised directly from Linux, Windows or ROS.
It exists because the hand does not ship with one. BrainCo's Revo 2 packaging list puts the Revo 2 485-USB debugging module among the optional tools, separate from the communication and power cables packed with every hand — so labs that debug over RS485 add the Revo 2 485-USB debugging module to the order alongside the hand, or pick one up when a bench setup comes together. Typical buyers run Revo 2 hands on Unitree G1, R1 and H2 platforms, including the Revo 2 Touch XTL/XTR hands configured on R1.
How the Debugging Chain Runs
On a Pro or Touch hand, RS485 leaves the wrist through the A1257WV-S-2P-6T connector — the Basic version keeps its own BM05B connector under the wrist — and that is where the Revo 2 485-USB debugging module picks the signal up. One of the two 485 communication cables runs from the hand to the converter, and the Type-C cable runs from the converter to your PC, where the port shows up as a USB serial device.
From there you are on BrainCo's documented toolchain: the stark-serialport examples on GitHub cover opening the port, finding the hand and sending position, speed and current commands, and the Python and C SDK guides on BrainCo's documentation portal carry the same flow into a full debugging session. It is the same serial interface the robot harness uses, brought out to your desk.
Why the Converter Has Two Ports
The two ports mirror how Revo 2 hands are wired for robotics: left and right hands each sit on their own RS-485 run, and the G1 integration maps the pair to two separate serial ports. With the Revo 2 485-USB debugging module at the center of the bench, one converter holds both runs at once, so a pair of hands can be commanded and observed side by side in a single session.
If you run a single hand, one port is enough and the second simply stays spare; if you keep a spare hand in the drawer, the second port takes it without re-patching cables. Either way, one kit covers the bench.
485, CAN FD or EtherCAT — Pick the Right Debugging Module
BrainCo's optional-tool list has one debugging module per hand interface. The Revo 2 485-USB debugging module is the RS485 one — the interface every Revo 2 version carries. The CAN FD-USB debugging module is a single-channel USB-CAN(FD) analyzer for CAN runs, and the EtherCAT debugging module is an EtherCAT-to-RJ45 cable for EtherCAT setups. If your debugging plan runs over RS485, this is the module of the three you want.
Every Revo 2 Version, over RS485
RS485 is the one communication interface every Revo 2 version carries, and BrainCo's packaging list puts the Revo 2 485-USB debugging module on the optional-tools list for all of them — the Basic (XRL/XRR), the Pro and the Touch (XTL/XTR). On Unitree R1, the dexterous-hand option is the Revo 2 Touch, so the left and right XTL/XTR hands are the pair this module most often meets; on the G1, BrainCo publishes a full adaptation guide built on the same dual RS-485 wiring.
The module follows the hand, not the robot: the same kit serves a Revo 2 hand whichever platform it is mounted on, and the optional-tools list runs parallel with the CAN FD and EtherCAT debugging modules for hands used over those interfaces.
Specifications
| Type | Revo 2 485-USB debugging module — BrainCo optional tool for the Revo 2 dexterous hand |
| Function | Dual-port RS485-to-USB converter for PC debugging over the hand's RS485 interface |
| Ports | 2× RS485 channels (dual-port converter) |
| PC connection | USB via Type-C (cable included) |
| Compatible hands | All Revo 2 versions (Basic XRL/XRR, Pro, Touch XTL/XTR) via RS485 |
| Packaging status | Optional tool — not part of any Revo 2 standard package |
| Sibling tools | CAN FD-USB Debugging Module · EtherCAT Debugging Module (separate BrainCo optional tools) |
| Typical use | Bench debugging and SDK development for Revo 2 hands on Unitree G1, R1 and H2 |
| In the box | Dual-port 485-to-USB converter ×1 · 1.15 m 485 communication cable ×2 · Type-C cable ×1 |
Shipping, Quality Guarantee & Care
The module kit ships worldwide by DHL or FedEx as standard electronic cargo — no lithium cells, no battery-class handling — with the transit time confirmed in your quote.
Every BrainCo Revo 2 485-USB debugging module is 100% quality-inspected before it ships and packed with the cables protected, so it arrives ready for the bench. Keep the converter dry and mind the connector orientation when swapping cables.
Last updated: November 2026.
Frequently Asked Questions
Can't find what you're looking for? Contact our