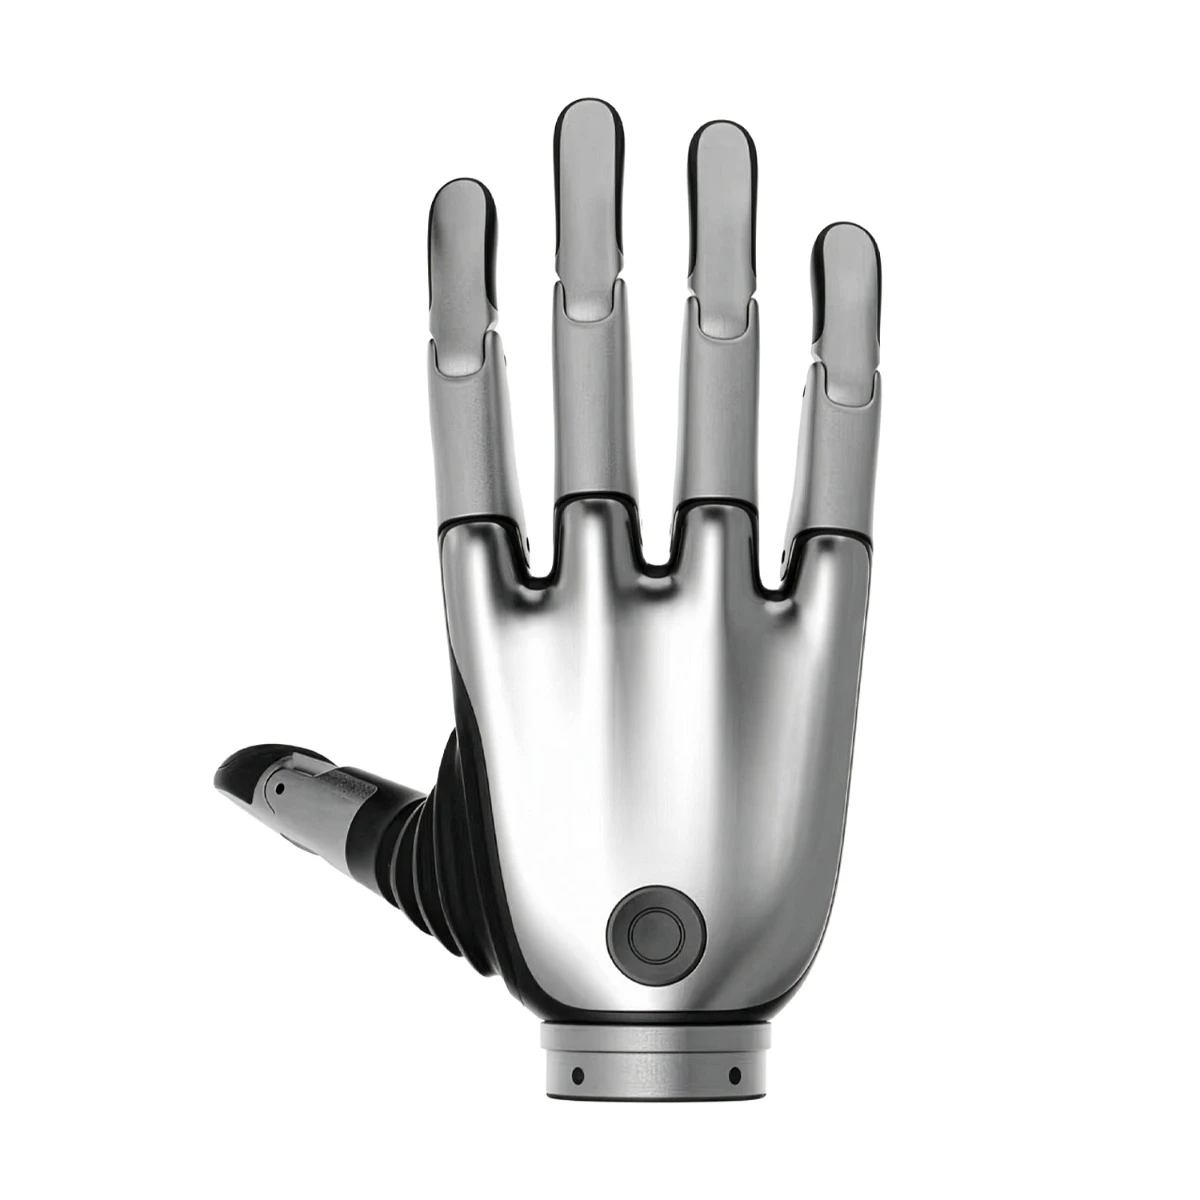
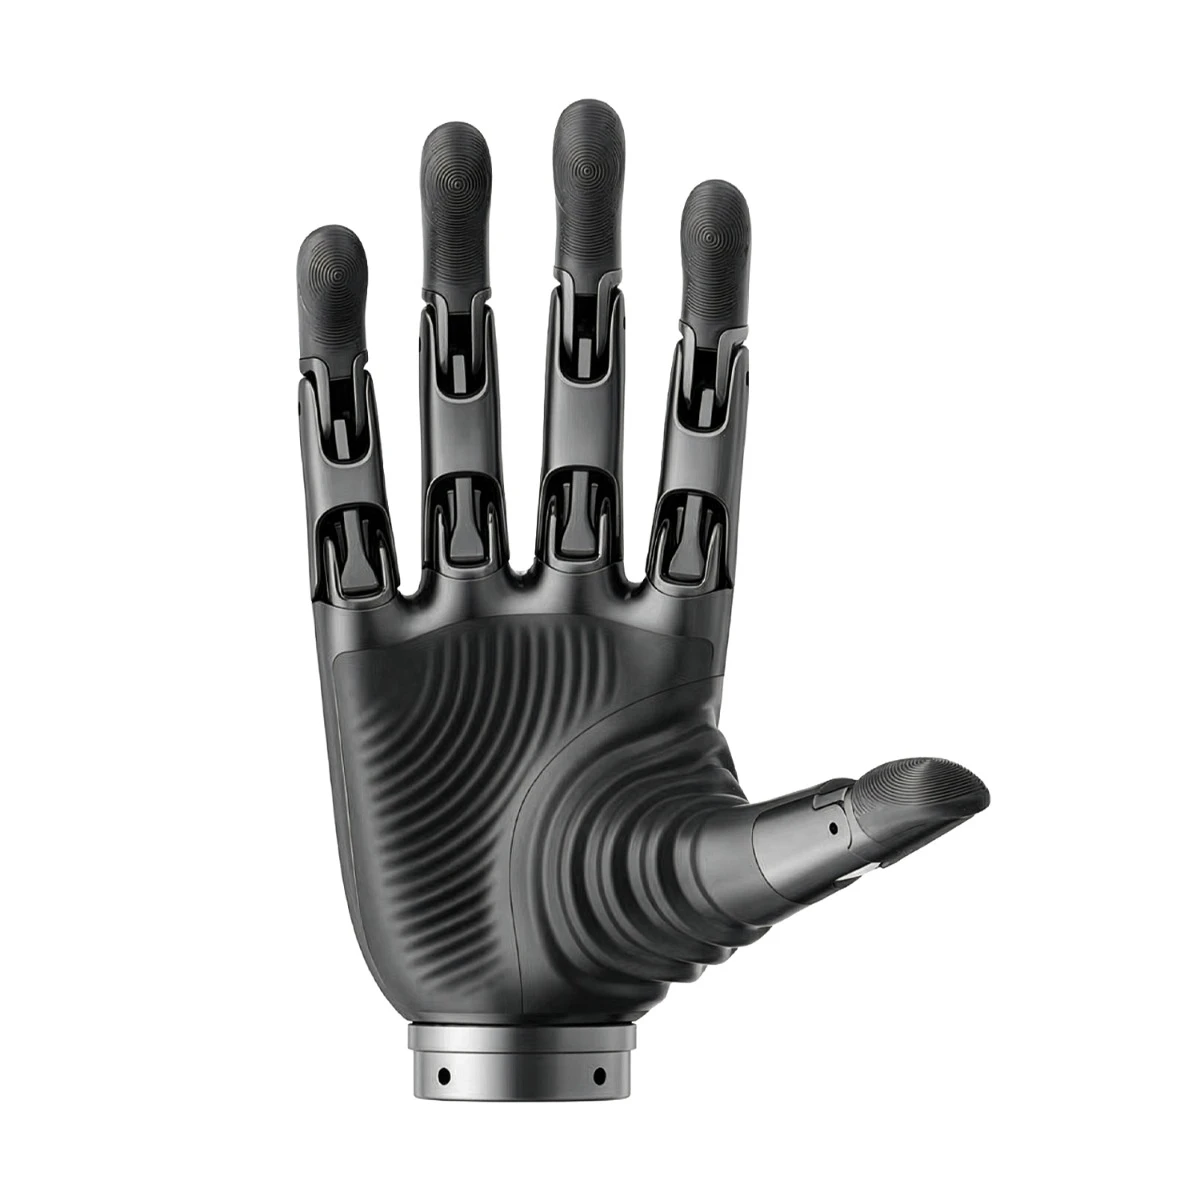
BrainCo Revo 2 Hand
BrainCo Revo 2 hand — the Basic version of the 11-DoF bionic dexterous hand: position, velocity and current control over RS485 or CAN FD, for Unitree G1 integration and research. Sold per hand, left or right.
- Unitree G1 (23-DoF and 29-DoF)
About the BrainCo Revo 2 Hand
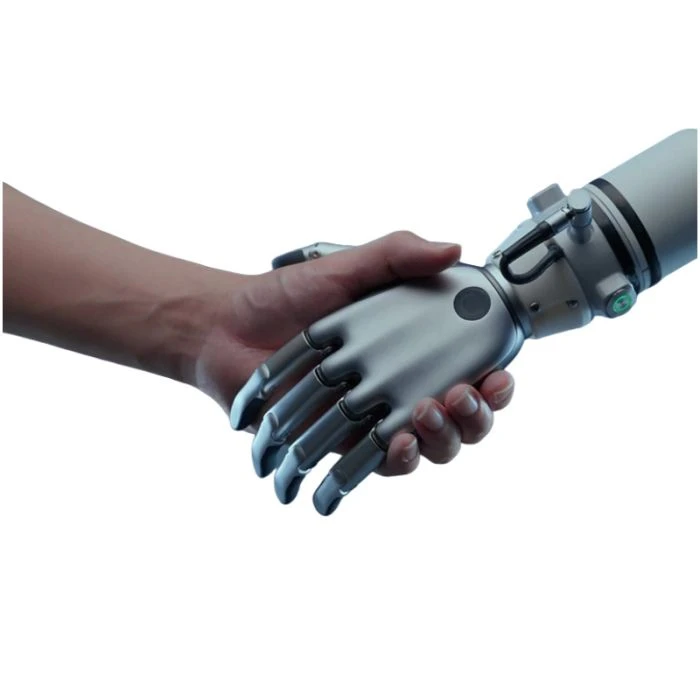
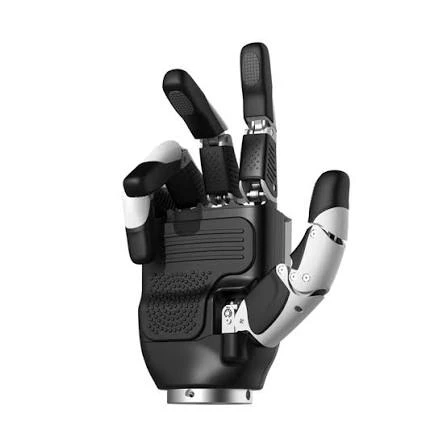
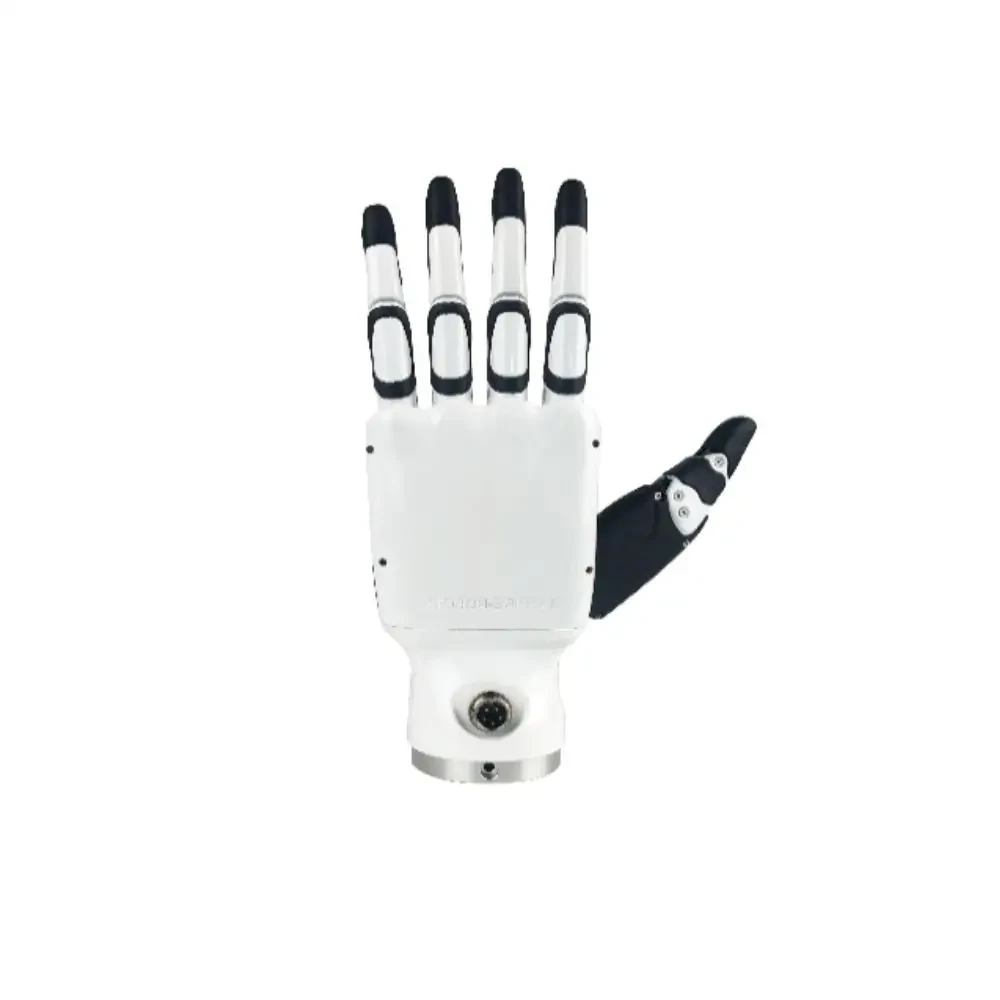
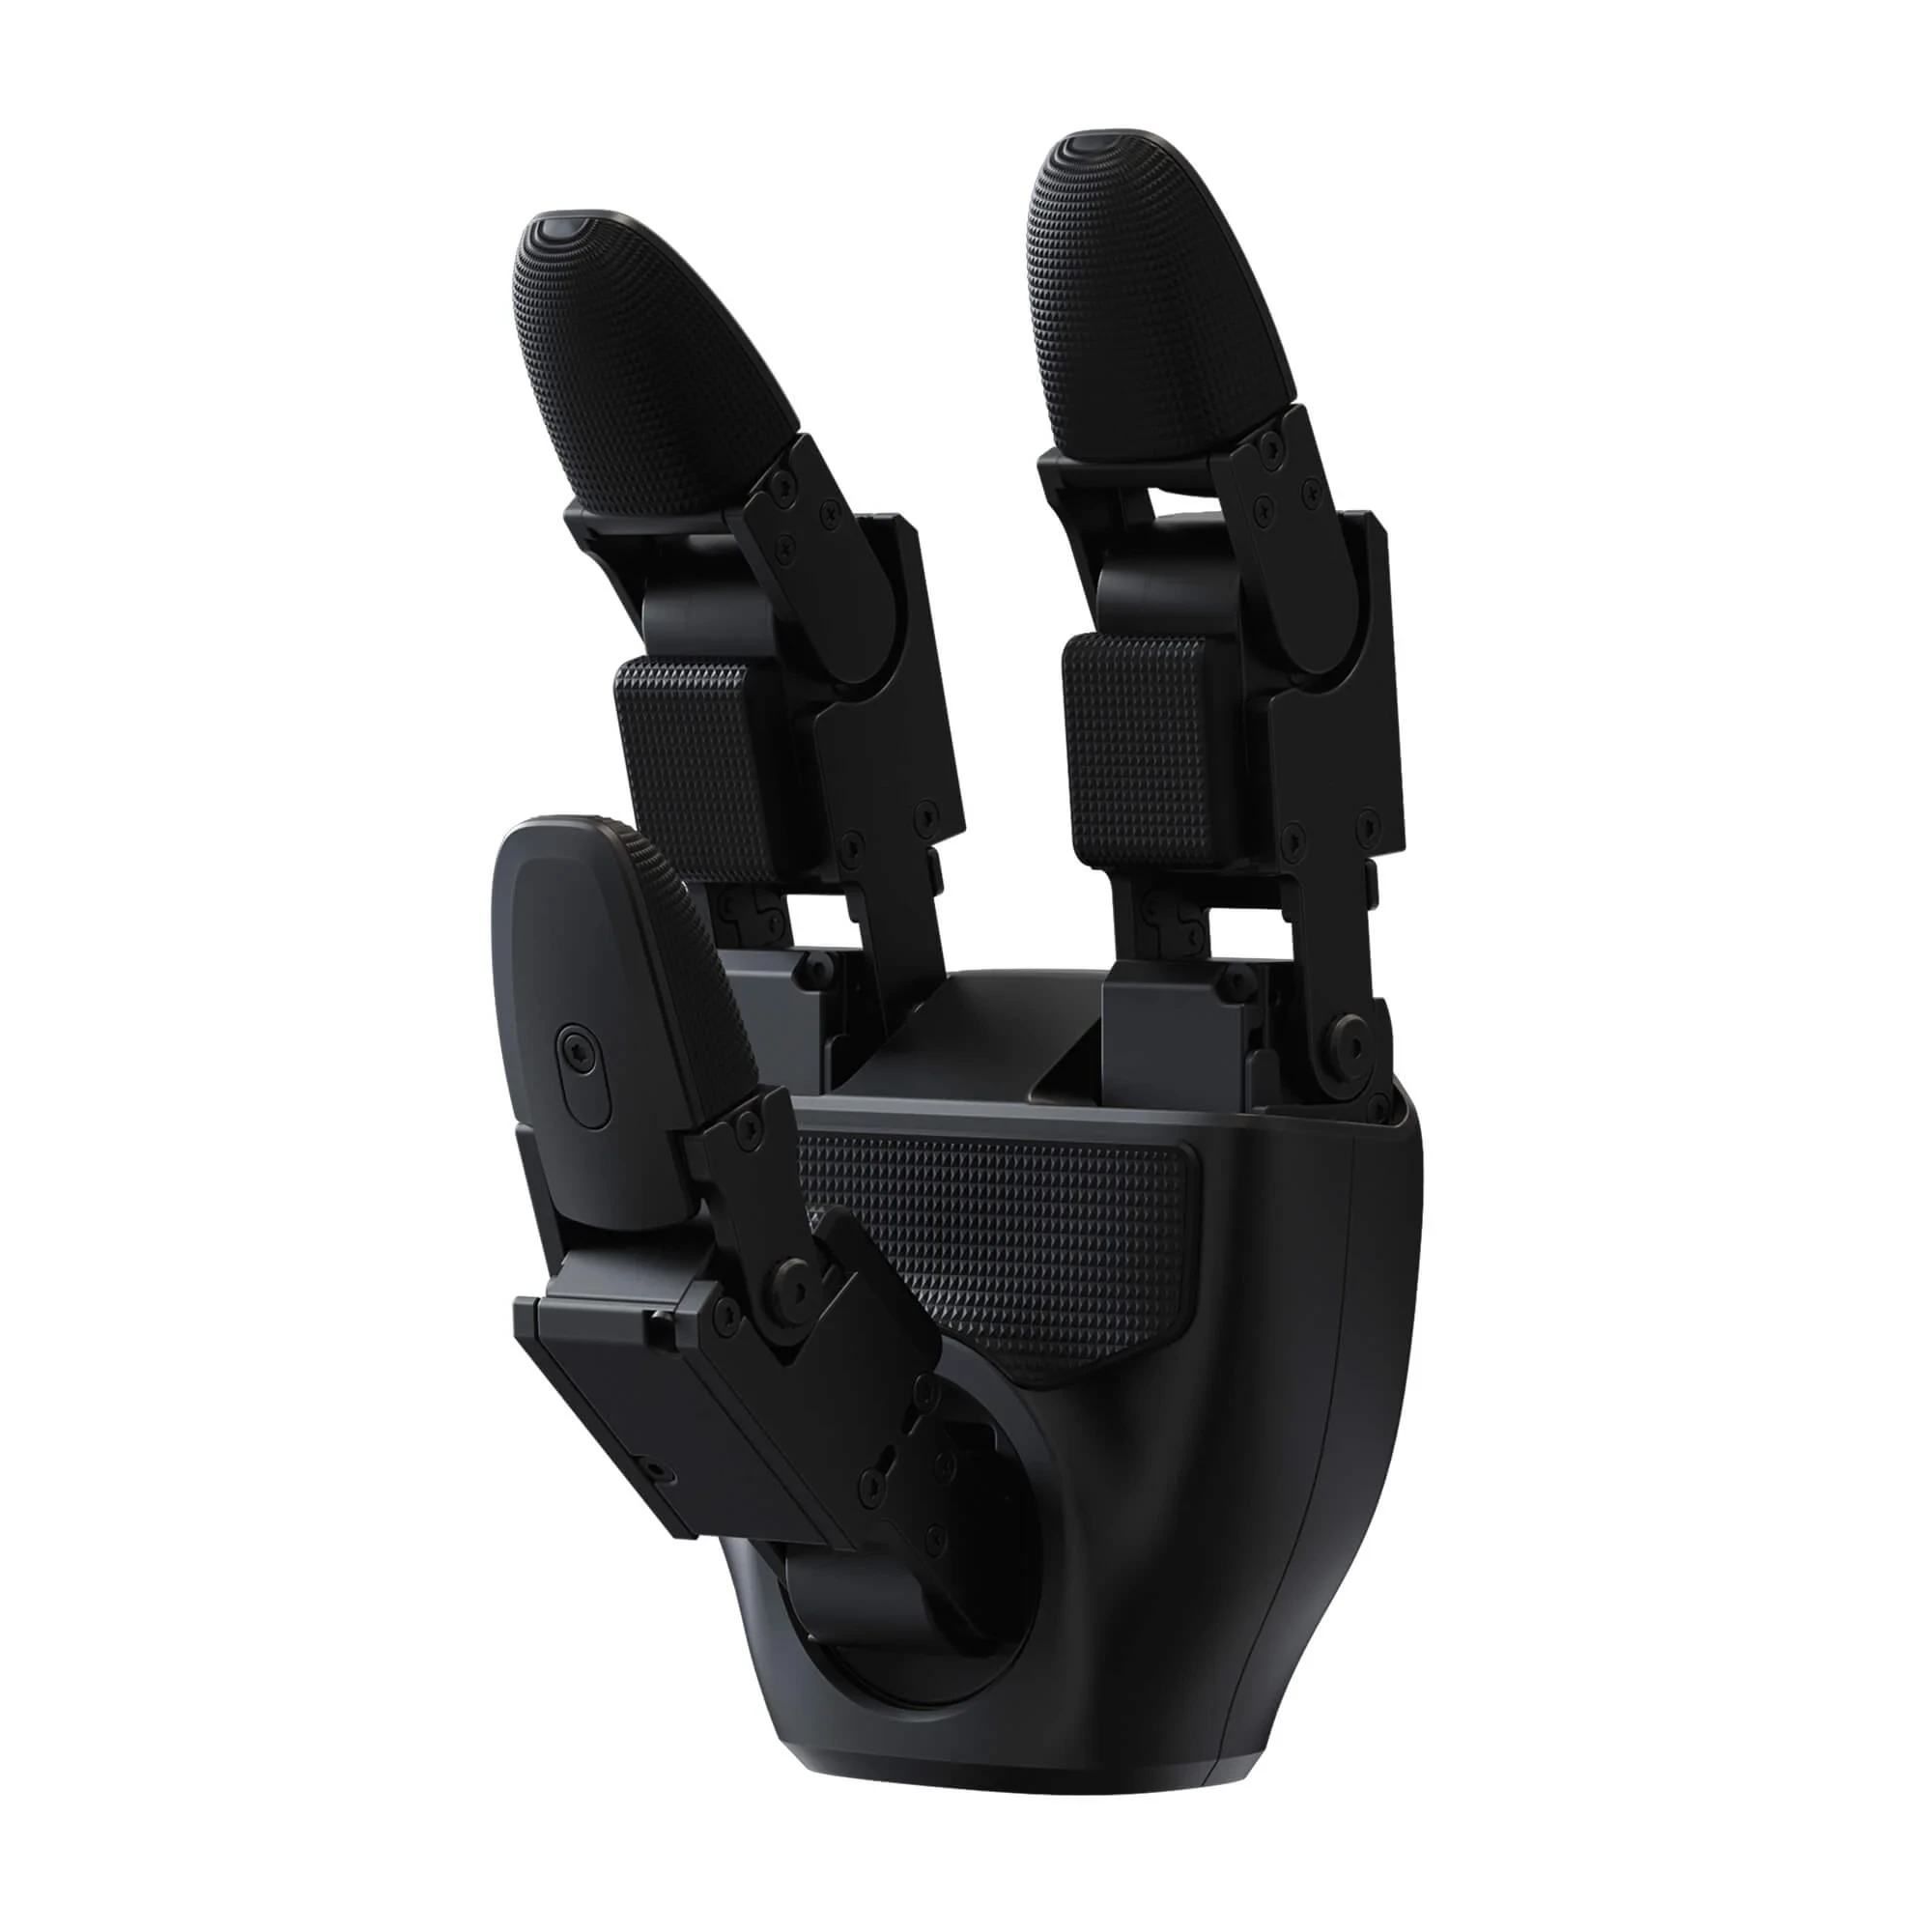
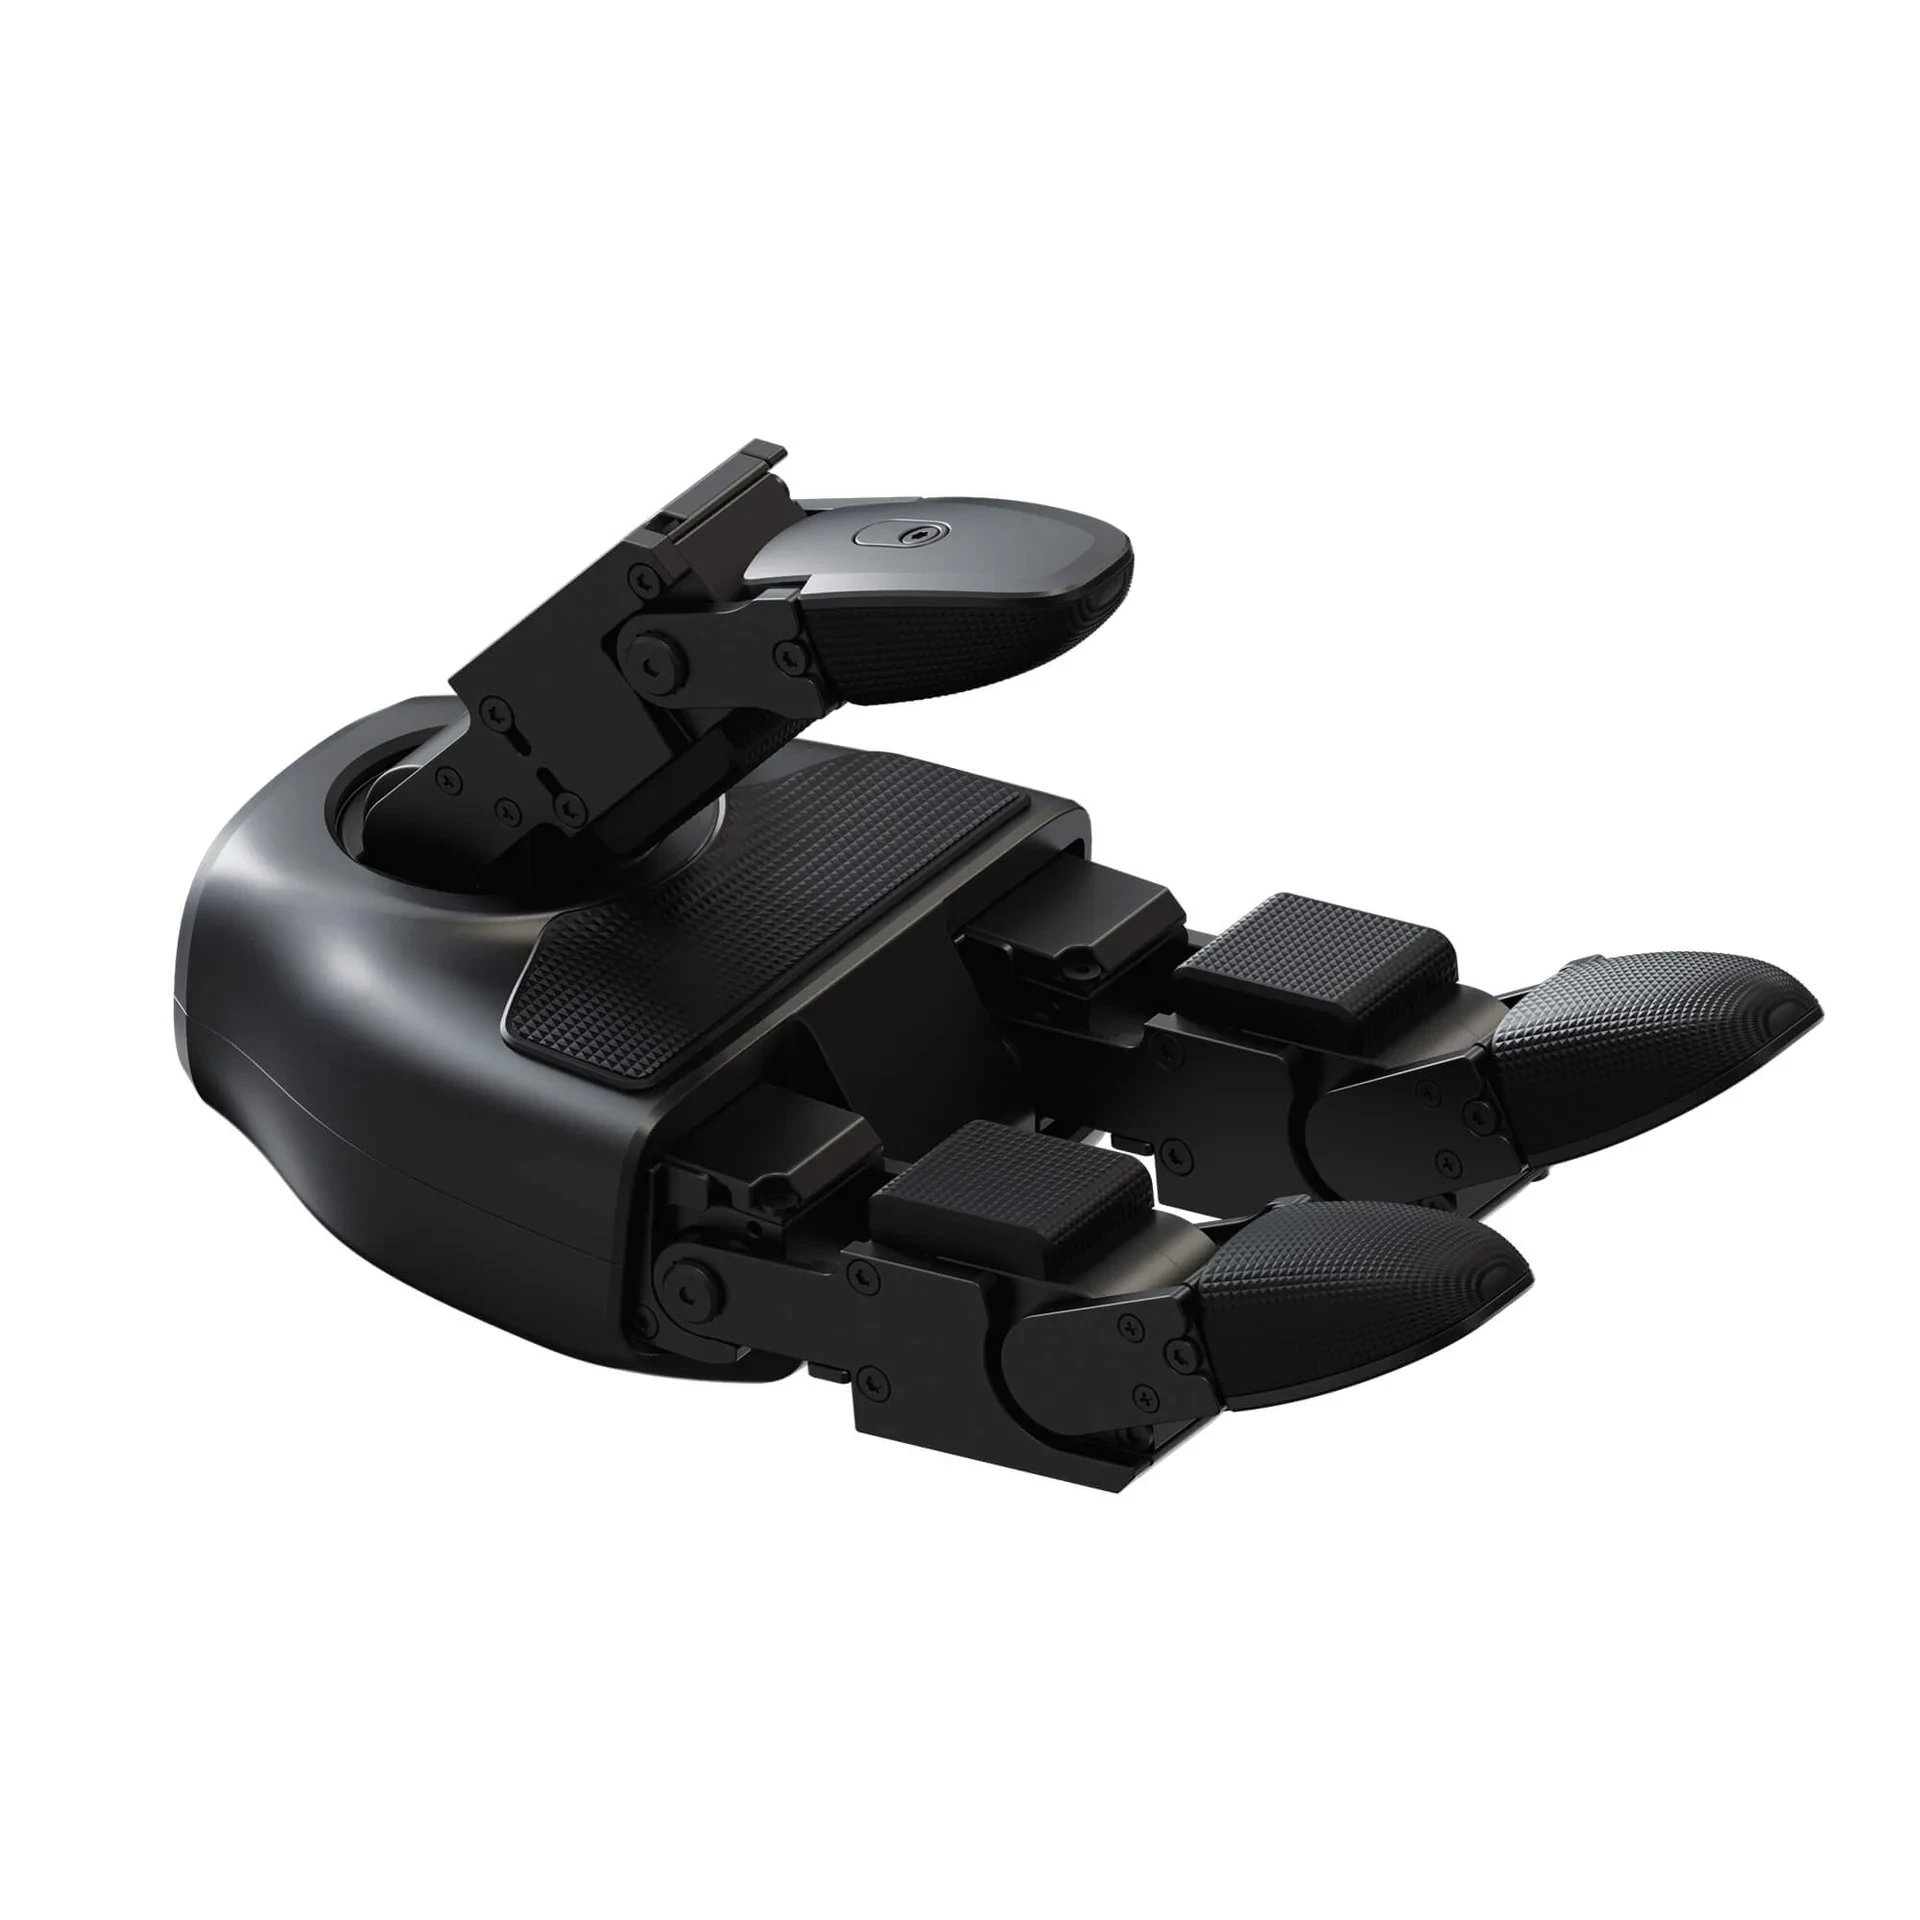
The BrainCo Revo 2 hand is an 11-DoF bionic dexterous hand for humanoid integration and manipulation research — five fingers, six active joints and a 383 g build that mounts at the wrist and closes a full fist in under a second. This page covers both versions: the Basic, built for position, speed and current control, and the Touch, which adds a capacitive fingertip tactile module and tactile adaptive control. It is sold per hand — left or right — for new robot configurations, replacements and development work.
For labs and developers, the BrainCo Revo 2 hand is the dexterous-hand option with a published Unitree G1 integration path — ROS 2 control over dual RS-485 links — plus robotic-arm flange mounting, NVIDIA Isaac Lab simulation assets and data-glove teleoperation, so it slots into existing manipulation, teleoperation and demonstration-collection pipelines.
The Touch Version Feels Contact, Not Just Position
Order the BrainCo Revo 2 hand in its Touch version and every fingertip carries a multi-dimensional capacitive tactile module. Instead of inferring contact from motor current alone, the hand senses touch directly at the fingertip — the raw signal for contact detection and stiffness recognition while the grasp is still forming.
BrainCo's adaptive-grasping example shows what that unlocks: tactile signals stream in real time, a processor classifies contact and object stiffness, and the controller adjusts finger current on the fly — so the same grip routine holds a foam block, a paper cup or a water bottle without re-tuning. The Touch version also adds EtherCAT alongside RS485 and CAN FD for deterministic, low-latency control cycles.
- Capacitive multi-dimensional tactile module at the fingertips
- Contact detection and stiffness recognition in real time
- Adaptive grasping — finger current adjusts to object stiffness
- Adds EtherCAT to RS485 / CAN FD (Touch version)
Five Control Modes Plus a Turbo Grip for Soft Objects
Every BrainCo Revo 2 hand runs five low-level control modes: move to a position within a set time, move to a position under a speed limit, run at a continuous speed, hold a target current, or hold a PWM duty cycle. Current mode is what makes the Basic version compliant without tactile sensors — the fingers close until they meet resistance and then hold a set force instead of a set angle.
On top of that sits Turbo mode: when a finger stalls against an object, the hand pauses and then keeps re-gripping at 500 ms intervals — a practical way to hold soft or shifting objects that would slowly escape a fixed grasp. Overcurrent, stall, high-temperature and anti-collision protections sit underneath every mode.
- Position + time · position + speed · speed · current · PWM
- Current mode = compliant gripping without tactile sensors
- Turbo mode re-grips stalled fingers every 500 ms
BrainCo Revo 2 Hand: Basic vs Touch (and Pro)
The BrainCo Revo 2 hand comes in three versions. This page sells the Basic and the Touch; the Pro sits between them as the wide-voltage, EtherCAT variant without tactile sensing.
| Basic (this page) | Touch (this page) | Pro | |
|---|---|---|---|
| Version code | XRL / XRR | XTL / XTR | XEL / XER |
| Tactile sensing | Capacitive fingertip tactile module | ||
| Communication | RS485 + CAN FD | RS485 + CAN FD + EtherCAT | RS485 + CAN FD + EtherCAT |
| Supply voltage | 12–28 V | 12–64 V | 12–64 V |
| Control | Position, velocity, current feedback | Adds cascaded, compliance and tactile adaptive control | Adds cascaded and compliance control |
| Best for | Manipulation and teleoperation on a budget | Contact-rich research and adaptive grasping | EtherCAT integration without tactile |
Sold per Hand — How to Pick Left or Right
The BrainCo Revo 2 hand is sold per hand, and the two sides are mirror builds — they are not interchangeable. The version code carries the side: in every version, the L suffix is the left hand and the R suffix is the right — XRL/XRR for Basic, XTL/XTR for Touch. On the bus, a left hand ships with device ID 126 and a right hand with 127, both re-assignable between 1 and 254 when you run a pair.
Order a single hand for a replacement or for single-arm tasks. For bilateral manipulation, plan a pair — one left hand and one right hand, added as two line items on your quote.
- L = left · R = right, in every version code
- Default device IDs: left 126 · right 127 — re-assignable 1–254
- A full humanoid setup uses two — one left, one right
A Published Integration Path for the Unitree G1
The BrainCo Revo 2 hand has a published Unitree G1 adaptation: BrainCo's integration guide covers both the 23-DoF and the 29-DoF G1, with the hands mounted at the wrist and driven over dual RS-485 serial links — one per hand — under ROS 2, including teleoperation task domains. The same ecosystem covers robotic-arm flange mounting, NVIDIA Isaac Lab simulation assets and data-glove teleoperation.
Revo 2 builds dedicated to the Unitree H2 and R1 also exist as robot-specific SKUs; the hands on this page are the standard XRL/XRR and XTL/XTR versions.
Specifications
| Basic | Touch | |
|---|---|---|
| Type | Five-finger bionic dexterous hand | Five-finger bionic dexterous hand with tactile sensing |
| Version | Basic (XRL left / XRR right) | Touch (XTL left / XTR right) |
| Degrees of freedom | 11 — 6 active + 5 passive | 11 — 6 active + 5 passive |
| Active joints | Thumb flexion · thumb abduction · one per finger (4) | Thumb flexion · thumb abduction · one per finger (4) |
| Joint range of motion | Thumb flex 0–59° · thumb abduction 0–90° · four fingers 0–81° each | Thumb flex 0–59° · thumb abduction 0–90° · four fingers 0–81° each |
| Weight | 383 g | 383 g |
| Height | 160 mm (palm base to middle fingertip) | 160 mm (palm base to middle fingertip) |
| Full-fist grip force | ≥50 N | ≥50 N |
| Single-finger pinch force | ≥15 N | ≥15 N |
| Max payload | ≥20 kg | ≥20 kg |
| Flexion/extension speed | ≤0.65 s full close or open | ≤0.65 s full close or open |
| Repetitive control precision | 0.1° | 0.1° |
| Max opening distance | 100 mm (thumb to index fingertip) | 100 mm (thumb to index fingertip) |
| Operating noise | ≤50 dB at 50 cm | ≤50 dB at 50 cm |
| Control modes | Position + time · position + speed · speed · current · PWM · Turbo (stall-hold) | Position + time · position + speed · speed · current · PWM · Turbo (stall-hold) |
| Smart control | Position, velocity and current feedback control | Cascaded + compliance control · tactile adaptive control |
| Tactile module | Not equipped — tactile sensing is exclusive to the Touch version | Multi-dimensional capacitive fingertip tactile module |
| Communication | RS485 or CAN FD (DIP-switch selectable) | RS485 + CAN FD + EtherCAT |
| Supply voltage | DC 12–28 V | DC 12–64 V |
| Current | 65 mA static · 350 mA no-load · 4.6 A max (@24 V) | 115 mA static · 390 mA no-load · 4.65 A max (@24 V) |
| Connector | BM05B-PASS-TFT (wrist underside) | A1257WV-S-2P-6T (485 / CAN FD) · A1257WV-S-5P-6T (EtherCAT) · XT30UPB-M power |
| Smart protection | Overcurrent · stall · high-temperature · anti-collision | Overcurrent · stall · high-temperature · anti-collision |
| SDK | Python / C++ SDK — Linux, Windows and ROS | Python / C++ SDK — Linux, Windows and ROS |
| Firmware | OTA online upgrades | OTA online upgrades |
| Operating temperature | −10 to 40 °C · ≤90% RH | −10 to 40 °C · ≤90% RH |
| Colors | Space Gray / Silver | Space Gray / Silver |
| Fits | Unitree G1 (23-DoF and 29-DoF) | Unitree G1 (23-DoF and 29-DoF) |
| In the box | BrainCo Revo 2 Basic dexterous hand — left (XRL) or right (XRR) as ordered | BrainCo Revo 2 Touch dexterous hand — left (XTL) or right (XTR) as ordered |
Shipping & Service
The hand ships worldwide by DHL or FedEx in protective industrial packaging; exact transit time is confirmed with your quote.
Every unit is 100% quality-inspected before it ships, so it arrives in perfect working order.
Last updated: October 2026.
Frequently Asked Questions
Can't find what you're looking for? Contact our