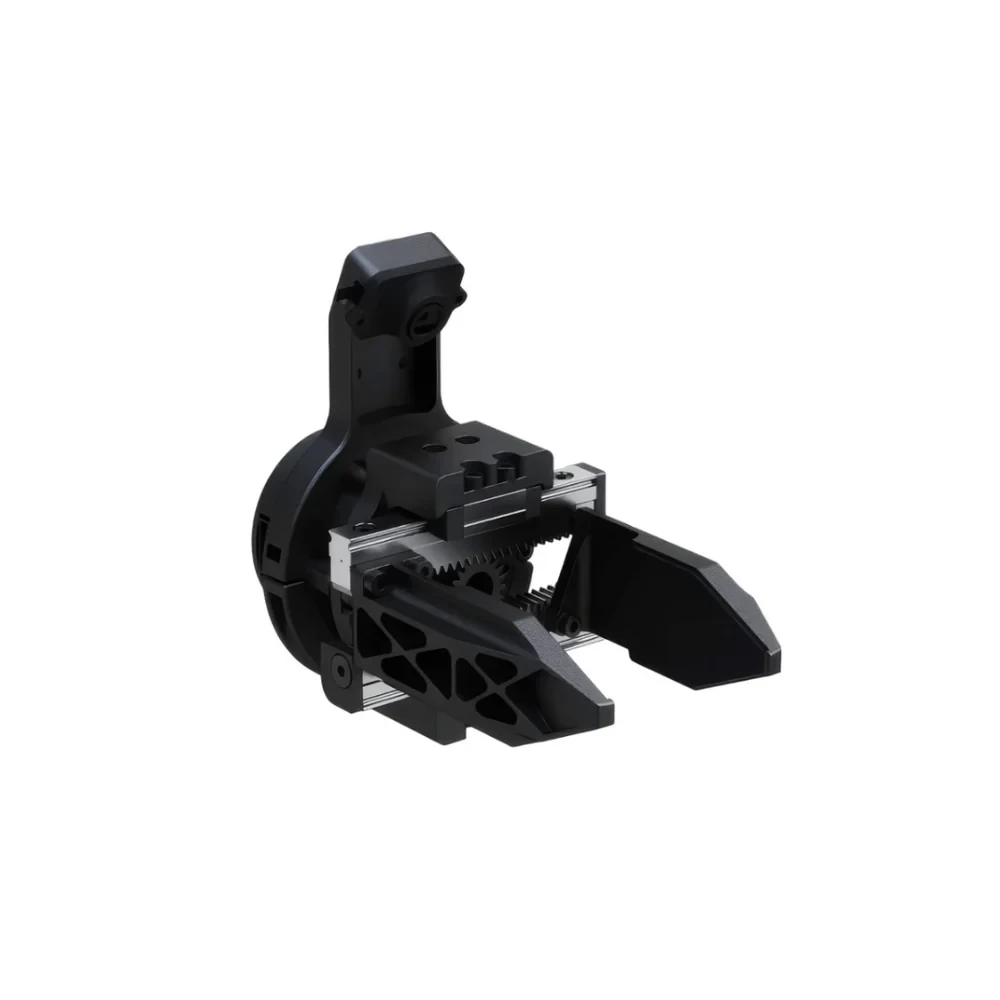
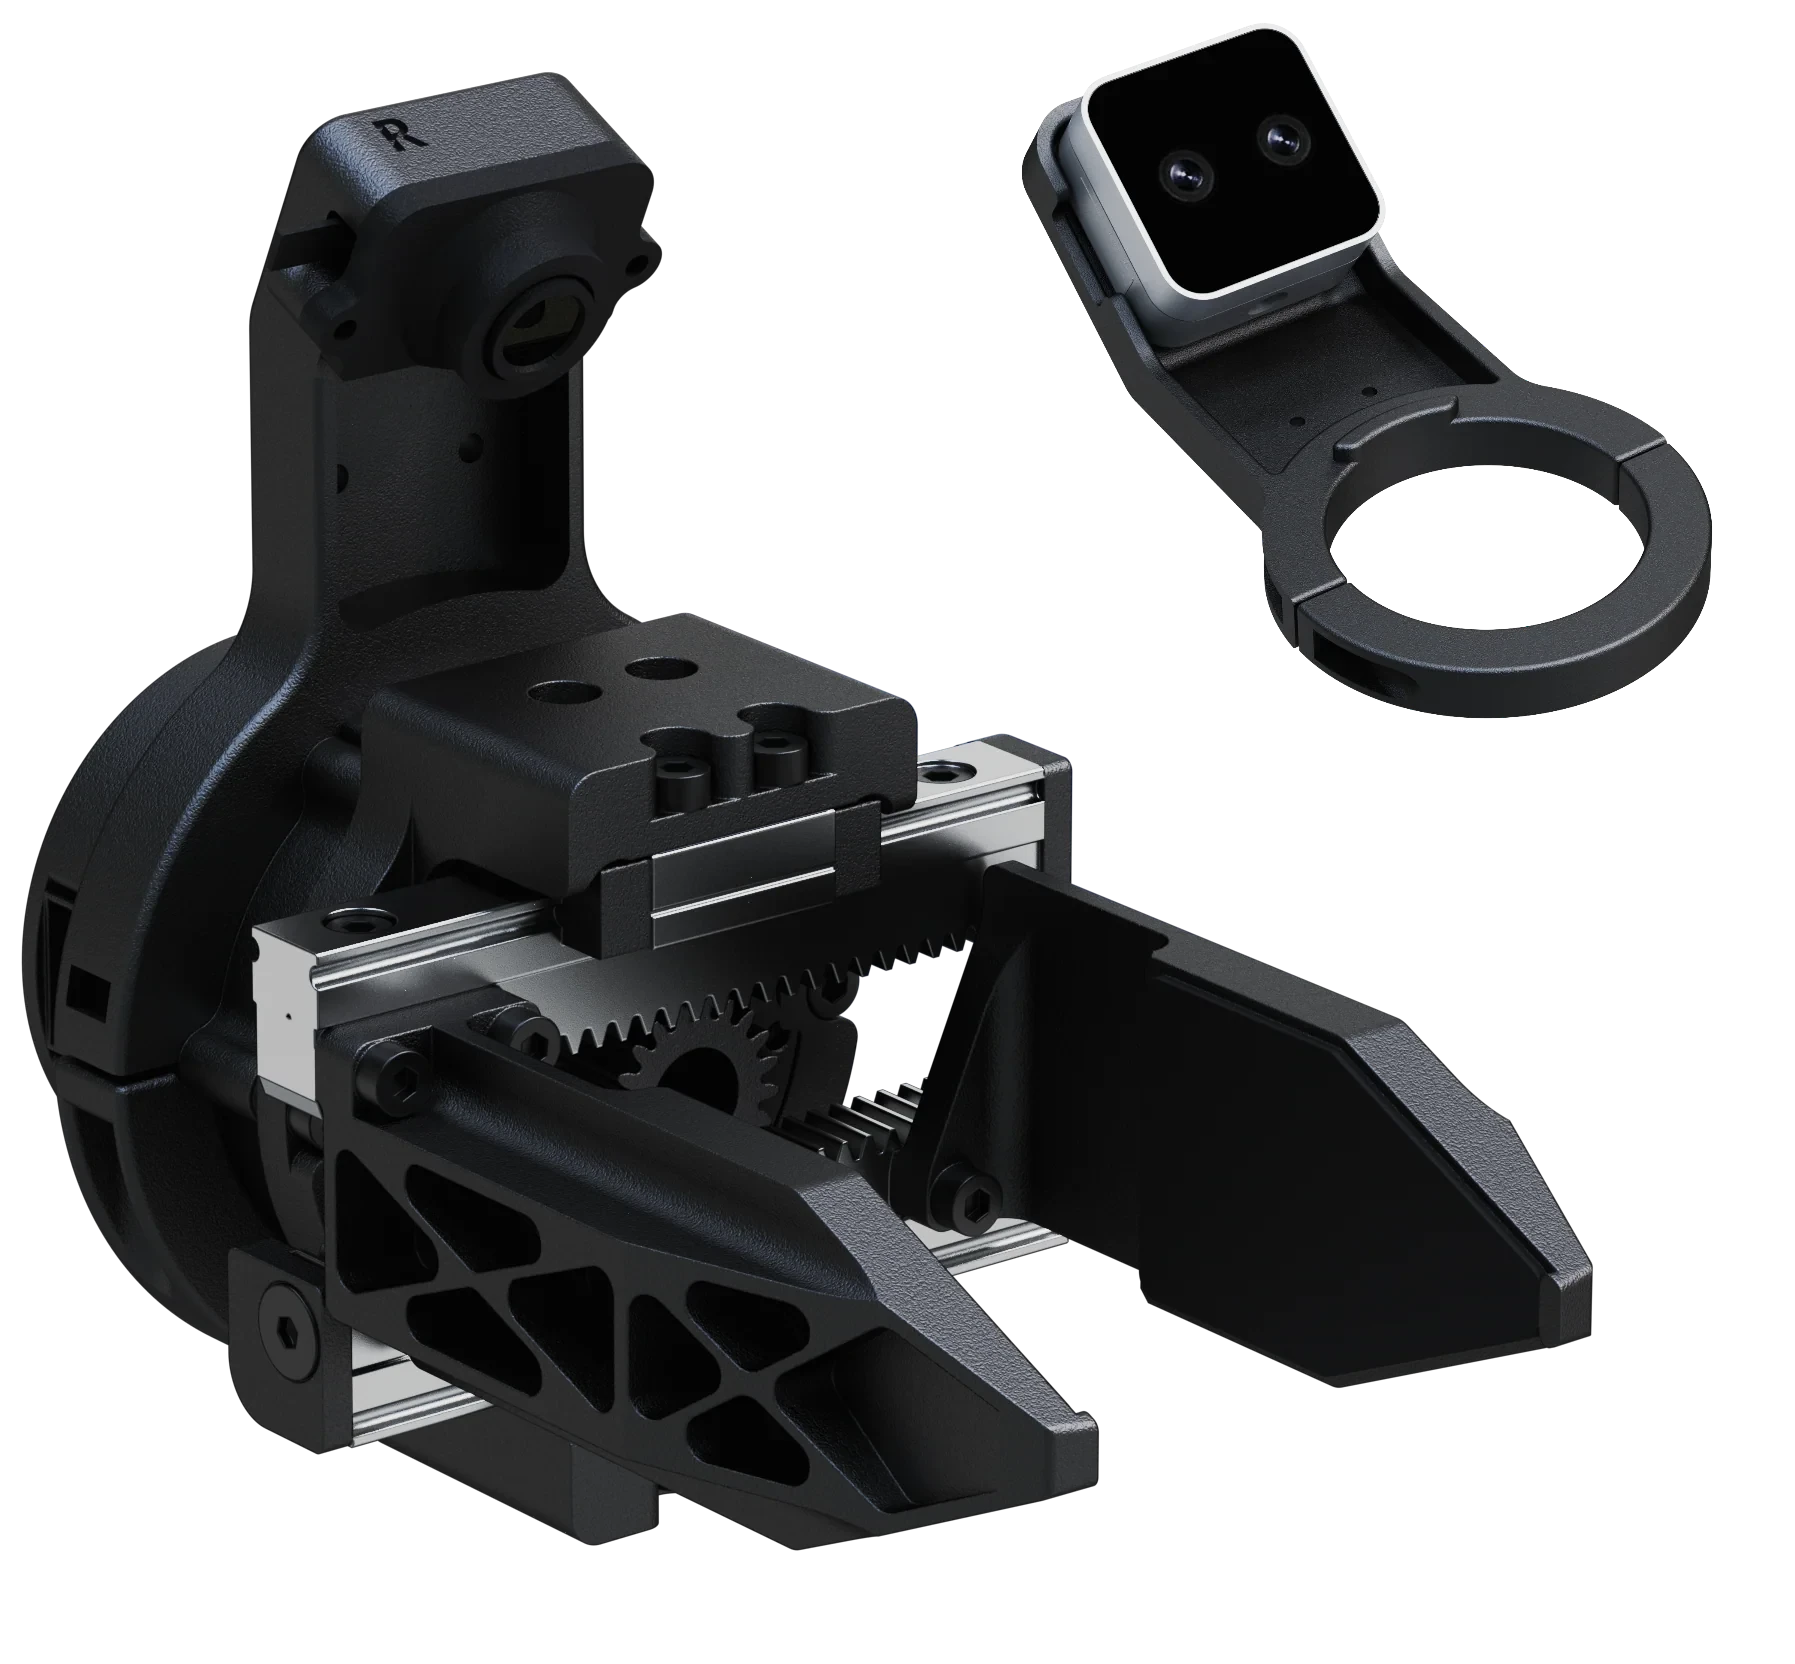
Unitree Dex1-1 Gripper
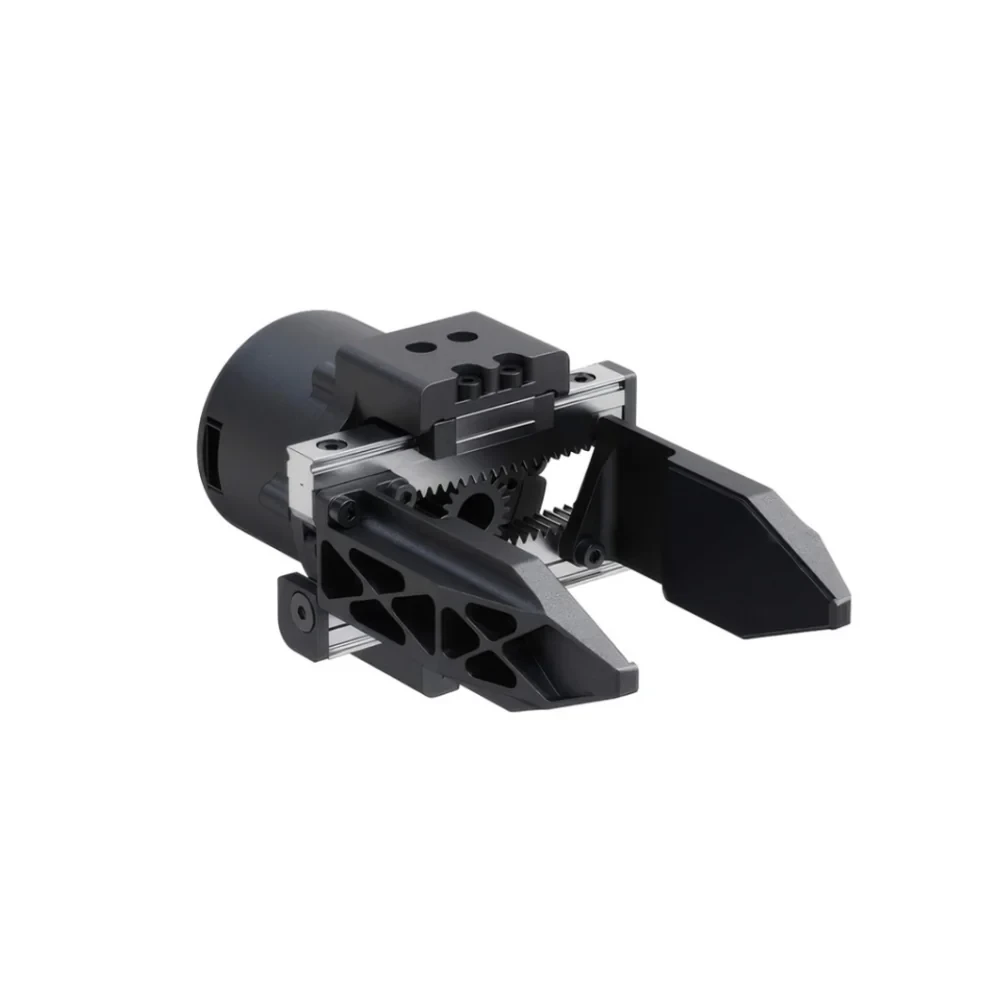
Unitree Dex1-1 gripper — a two-finger parallel electric gripper for the G1, R1 and H2. This listing is the Standard version; Advanced and Ultimate are one click away.
- Unitree G1
- Unitree R1
- Unitree H2
About the Unitree Dex1-1 Gripper
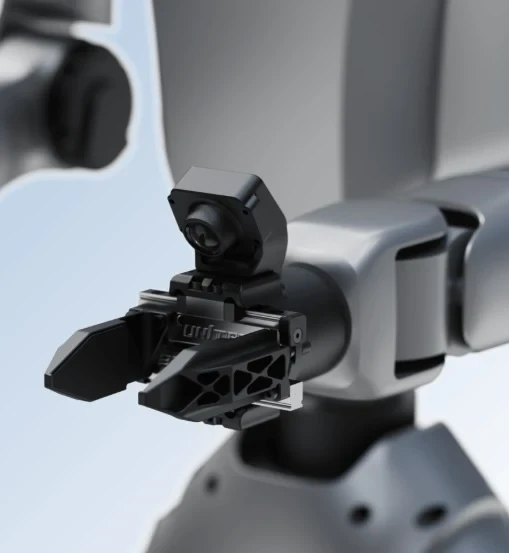
The Unitree Dex1-1 gripper is Unitree's two-finger parallel electric gripper for embodied AI work — the end effector behind pick-and-place, sorting and teleoperated data collection on the G1, R1 and H2 humanoids. It is sold per gripper for new robot configurations, replacements and development work.
The Standard, Advanced and Ultimate versions share the same gripper body and differ only in the bundled vision hardware, so the choice comes down to how much perception you want at the wrist. The version comparison below walks through what each one adds.
Standard, Advanced or Ultimate: Which Dex1-1 to Buy
The Unitree Dex1-1 gripper comes in three versions that share the same body, stroke and force control. The only difference is the vision hardware bundled at the wrist — pick by what your pipeline needs to see.
| Standard | Advanced | Ultimate | |
|---|---|---|---|
| Gripper body | Dex1-1 two-finger gripper | Same Dex1-1 body | Same Dex1-1 body |
| RGB camera | 1080p RGB with mount, included | 1080p RGB with mount, included | |
| Depth camera | D405 mount included, camera not included | D405 mount included, camera not included | Intel RealSense D405 with mount, included |
| 485-to-USB board | Included | Included | Included |
| Best for | Pure grasping pipelines, replacements, teams adding their own vision | Vision-guided grasping and teleoperation with a wrist RGB feed | RGB-D data collection, 3D grasp planning, depth-aware manipulation |
| Upgrade path | Adds cameras later — D405 mount already in the box | Adds a D405 later — mount already in the box | Complete out of the box |
Adjustable Force, 0.1 mm Resolution, 1,000 Hz Control
The Unitree Dex1-1 gripper closes its two jaws over a 90 mm stroke with 0.1 mm position resolution at the fingertips. Gripping force adjusts from 5 to 120 N and closing speed from 50 to 375 mm/s, so the same gripper handles delicate components and firm industrial grasps — a full-stroke close takes as little as 0.24 s.
Control runs over high-speed RS-485 at 6 Mbps with a 1,000 Hz control frequency. The drive motor delivers 5 N·m of peak torque through a 1:25 reduction with a 15-bit absolute encoder, reports angle, angular velocity, torque and temperature, and accepts angle, speed, torque, stiffness and damping commands — so grasp behavior is programmable per task.
Rated grasp load is 20 kg in a form-fitting hold — the maximum horizontal load the jaws can hold without losing grip — and 5 kg by friction, measured as the maximum vertical load held on a square steel block without slipping. Force, speed and closing-time figures are measured across the 24–64 V operating range and vary with stiffness and damping settings.
- 90 mm stroke with 0.1 mm fingertip resolution
- 5–120 N adjustable force · 50–375 mm/s adjustable speed
- Programmable stiffness and damping for compliant contact
RGB and Depth Sensing at the Wrist
The Advanced version mounts a 1080p RGB camera at the wrist — 30 or 60 fps with a 118° horizontal field of view — giving teleoperation and policy training an eye-in-hand view of every grasp.
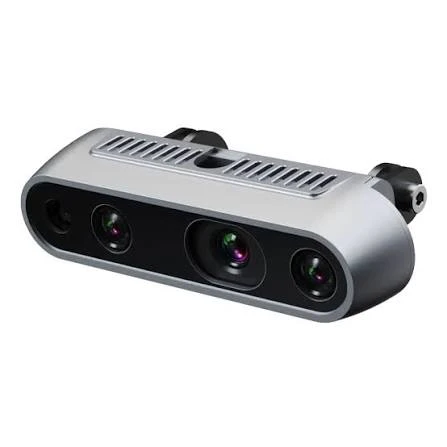
The Ultimate version adds an Intel RealSense D405 depth camera on its dedicated mount, turning the Unitree Dex1-1 gripper into an RGB-D end effector for 3D grasp planning and depth-aware data collection. The Standard version already ships with the D405 mounting bracket in the box, so moving up to depth sensing later is a bolt-on upgrade.
Fits G1, R1 and H2 — or Runs Standalone
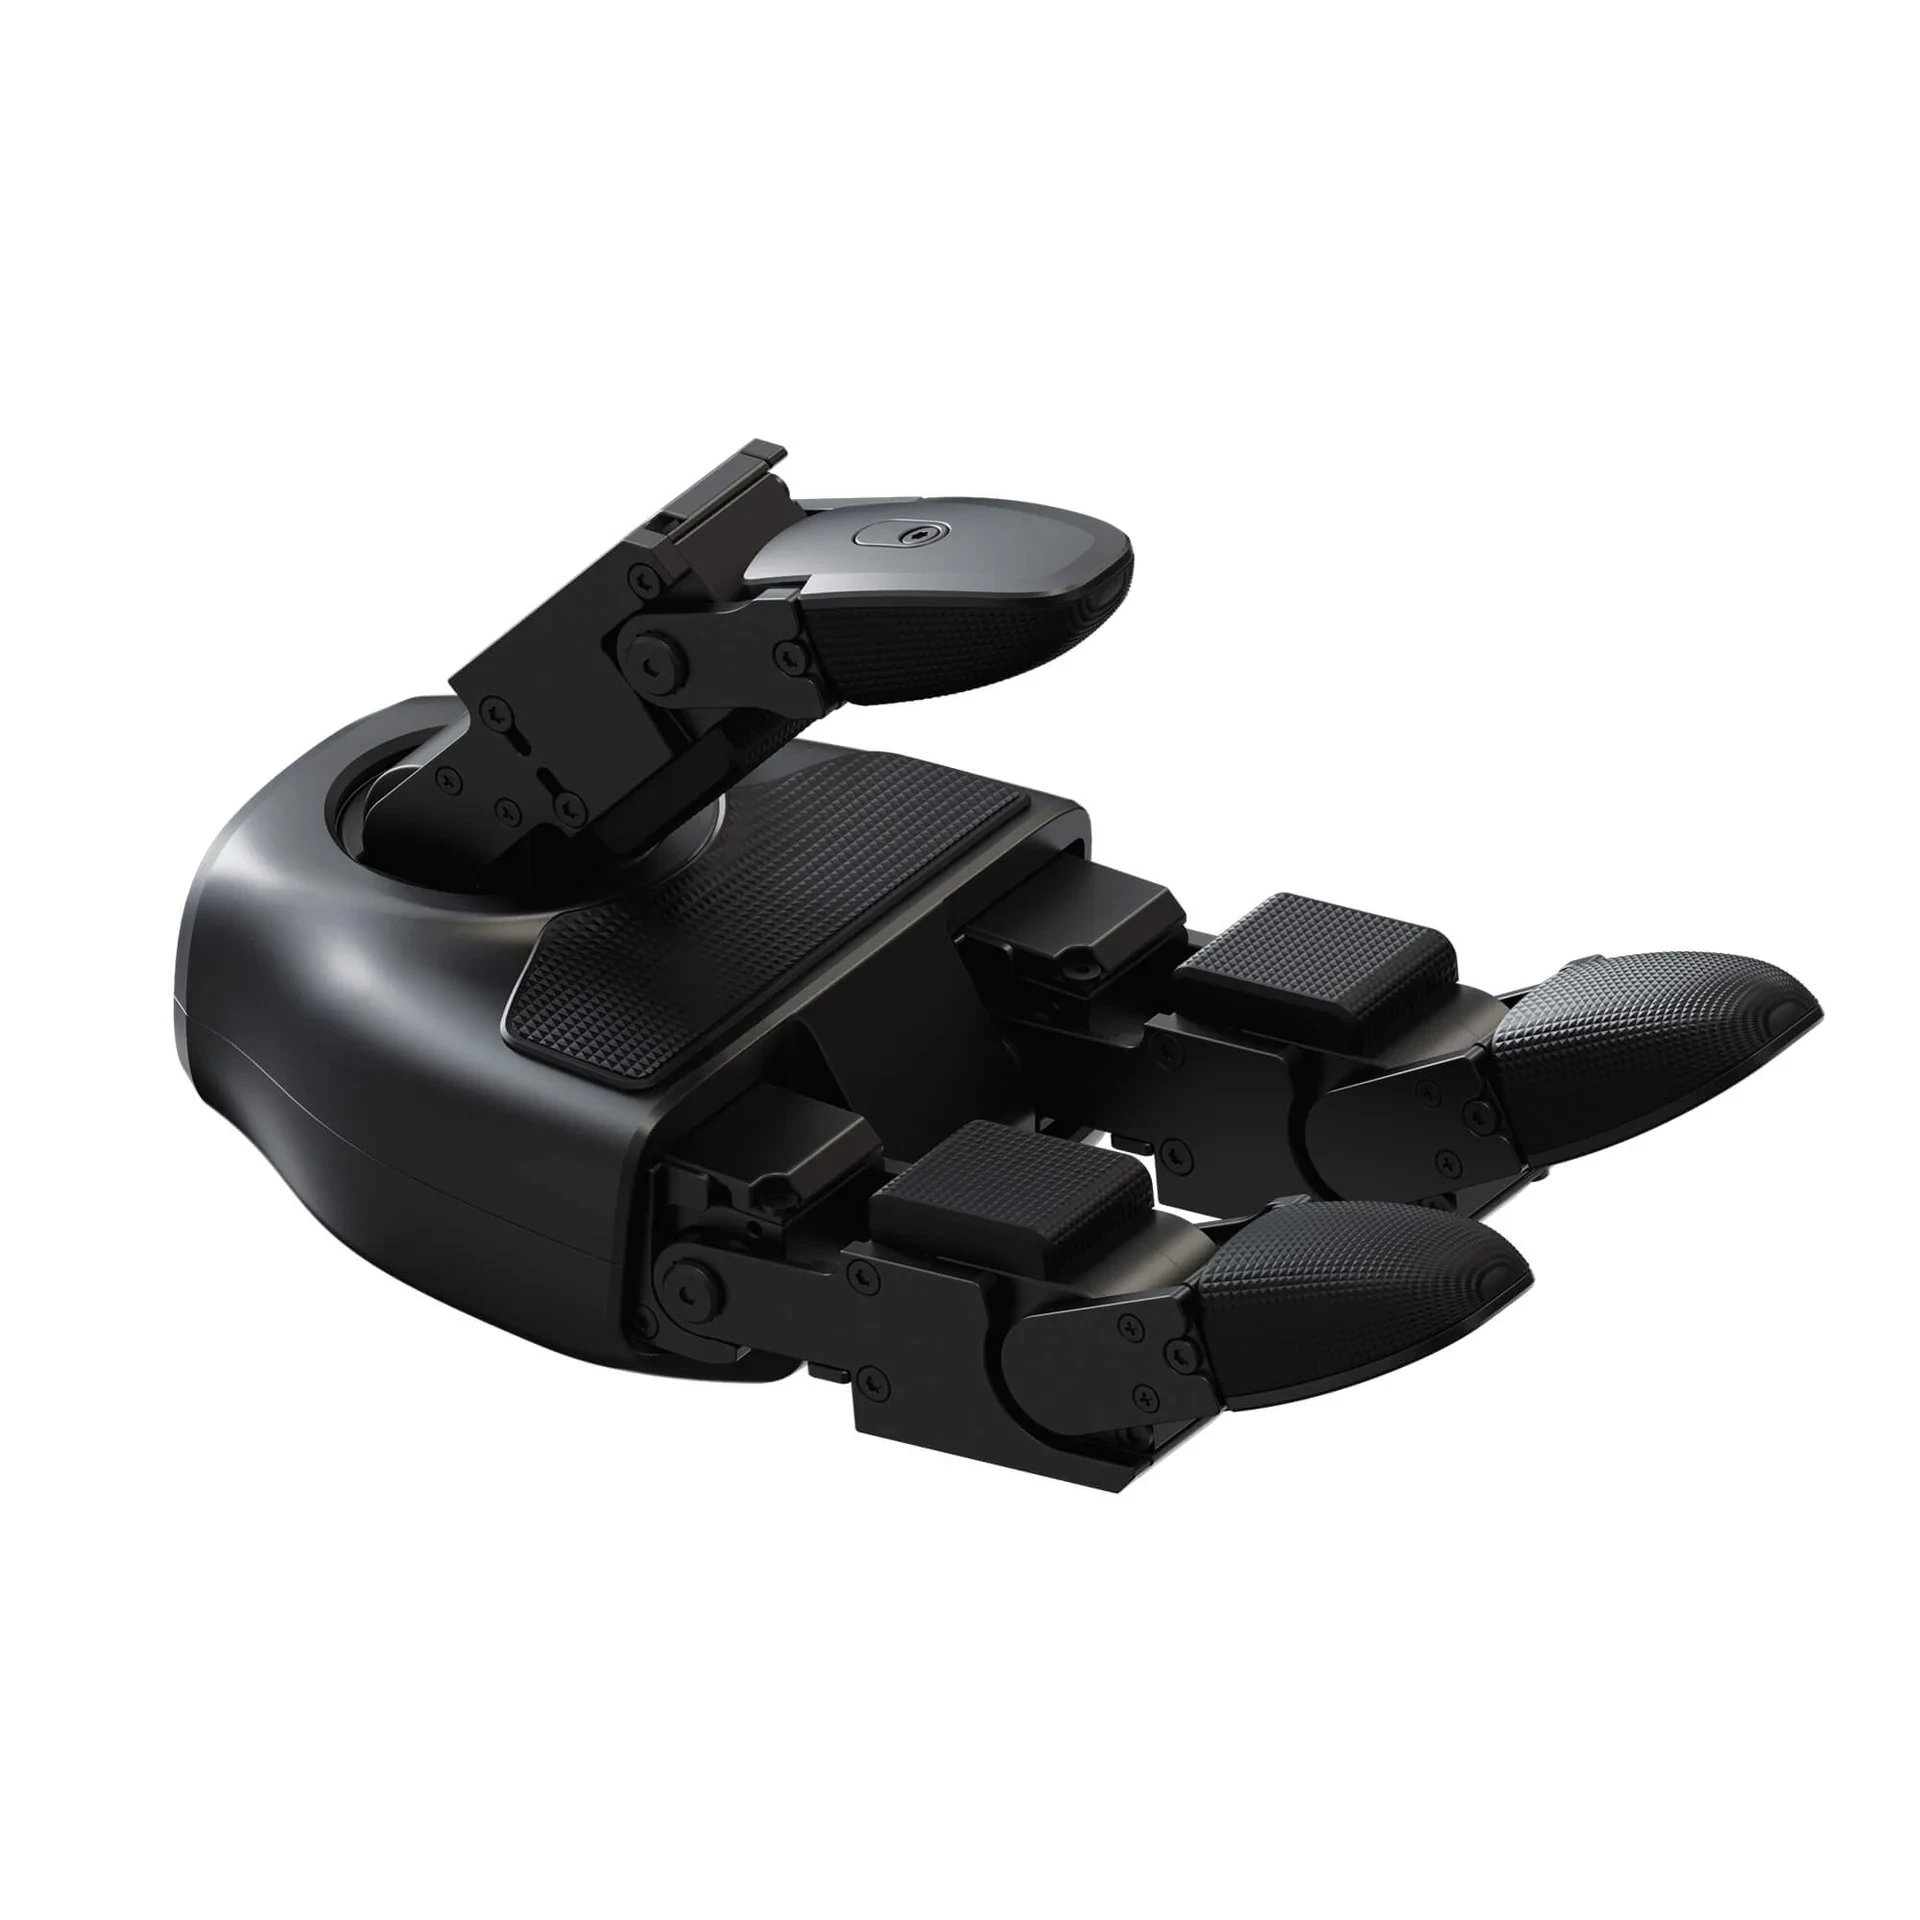
Unitree lists the Dex1-1 for three humanoid platforms — the G1, the R1 and the H2 — where it mounts at the wrist interface as the two-finger alternative to the Dex3-1 dexterous hand.
Off the robot, the included 485-to-USB conversion board connects the Unitree Dex1-1 gripper directly to a PC, so it works as a standalone end effector for bench testing, custom arms and secondary development through Unitree's robotics interfaces.
Specifications
| Standard | Advanced | Ultimate | |
|---|---|---|---|
| Type | Two-finger parallel electric gripper | Two-finger parallel electric gripper | Two-finger parallel electric gripper |
| Version | Standard — without cameras, D405 mounting bracket included | Advanced — with 1080p RGB camera | Ultimate — with 1080p RGB camera and D405 depth camera |
| Dimensions | 143 × 78 × 67 mm (half-open; 120 mm wide fully open) | 143 × 78 × 67 mm (gripper body, half-open; 120 mm wide fully open) | 143 × 78 × 67 mm (gripper body, half-open; 120 mm wide fully open) |
| Weight | 550 g | 550 g (gripper body) | 550 g (gripper body) |
| Stroke | 90 mm | 90 mm | 90 mm |
| Gripping force | 5–120 N (adjustable) | 5–120 N (adjustable) | 5–120 N (adjustable) |
| Speed | 50–375 mm/s (adjustable) | 50–375 mm/s (adjustable) | 50–375 mm/s (adjustable) |
| Fingertip position resolution | 0.1 mm | 0.1 mm | 0.1 mm |
| Grasp load (form-fitting) | 20 kg — max horizontal load without losing grip | 20 kg — max horizontal load without losing grip | 20 kg — max horizontal load without losing grip |
| Grasp load (friction) | 5 kg — max vertical load without slipping (square steel block) | 5 kg — max vertical load without slipping (square steel block) | 5 kg — max vertical load without slipping (square steel block) |
| Full-stroke closing time | 0.24 s (fastest, full stroke) | 0.24 s (fastest, full stroke) | 0.24 s (fastest, full stroke) |
| Jaw length | 80 mm | 80 mm | 80 mm |
| Communication | High-speed RS-485 · 6 Mbps · 1,000 Hz control frequency | High-speed RS-485 · 6 Mbps · 1,000 Hz control frequency | High-speed RS-485 · 6 Mbps · 1,000 Hz control frequency |
| Operating voltage | 24–64 V DC (24/48 V recommended) | 24–64 V DC (24/48 V recommended) | 24–64 V DC (24/48 V recommended) |
| Static current | 0.03 A | 0.03 A | 0.03 A |
| Peak line current | 3.5 A | 3.5 A | 3.5 A |
| Motor | 5 N·m peak torque · 27 rad/s max speed (at 64 V) · 1:25 reduction | 5 N·m peak torque · 27 rad/s max speed (at 64 V) · 1:25 reduction | 5 N·m peak torque · 27 rad/s max speed (at 64 V) · 1:25 reduction |
| Encoder | 15-bit absolute encoder | 15-bit absolute encoder | 15-bit absolute encoder |
| Motor feedback | Angle · angular velocity · torque · temperature | Angle · angular velocity · torque · temperature | Angle · angular velocity · torque · temperature |
| Control commands | Angle · angular velocity · torque · stiffness · damping | Angle · angular velocity · torque · stiffness · damping | Angle · angular velocity · torque · stiffness · damping |
| Operating temperature | −20 °C to 60 °C | −20 °C to 60 °C | −20 °C to 60 °C |
| Fits | Unitree G1 / R1 / H2 · standalone via 485-to-USB board | Unitree G1 / R1 / H2 · standalone via 485-to-USB board | Unitree G1 / R1 / H2 · standalone via 485-to-USB board |
| RGB camera | — | 1080p · 30/60 fps · FOV H 118° / V 87° / D 140° | 1080p · 30/60 fps · FOV H 118° / V 87° / D 140° |
| Depth camera | — | — | Intel RealSense D405 with dedicated mount |
| In the box | Unitree Dex1-1 gripper · D405 depth camera mounting bracket (camera not included) · 485-to-USB conversion board · Cable and accessory set | Unitree Dex1-1 gripper · 1080p RGB camera with mount · D405 depth camera mounting bracket (camera not included) · 485-to-USB conversion board · Cable and accessory set | Unitree Dex1-1 gripper · 1080p RGB camera with mount · Intel RealSense D405 depth camera with dedicated mount · 485-to-USB conversion board · Cable and accessory set |
Shipping & Service
The gripper ships worldwide by DHL or FedEx in protective industrial packaging; exact transit time is confirmed with your quote.
Every unit is 100% quality-inspected before it ships, so it arrives in perfect working order.
Last updated: October 2026.
Frequently Asked Questions
Can't find what you're looking for? Contact our