Unitree Tendon-Driven Dexterous Hand (Dex2/5)
Unitree tendon-driven dexterous hand (Dex2/5) — a five-finger, tendon-driven hand for the Unitree G1 EDU and R1. Sold per hand; a full humanoid setup uses two.
- Unitree G1 EDU
- Unitree R1
About the Unitree Tendon-Driven Dexterous Hand (Dex2/5)
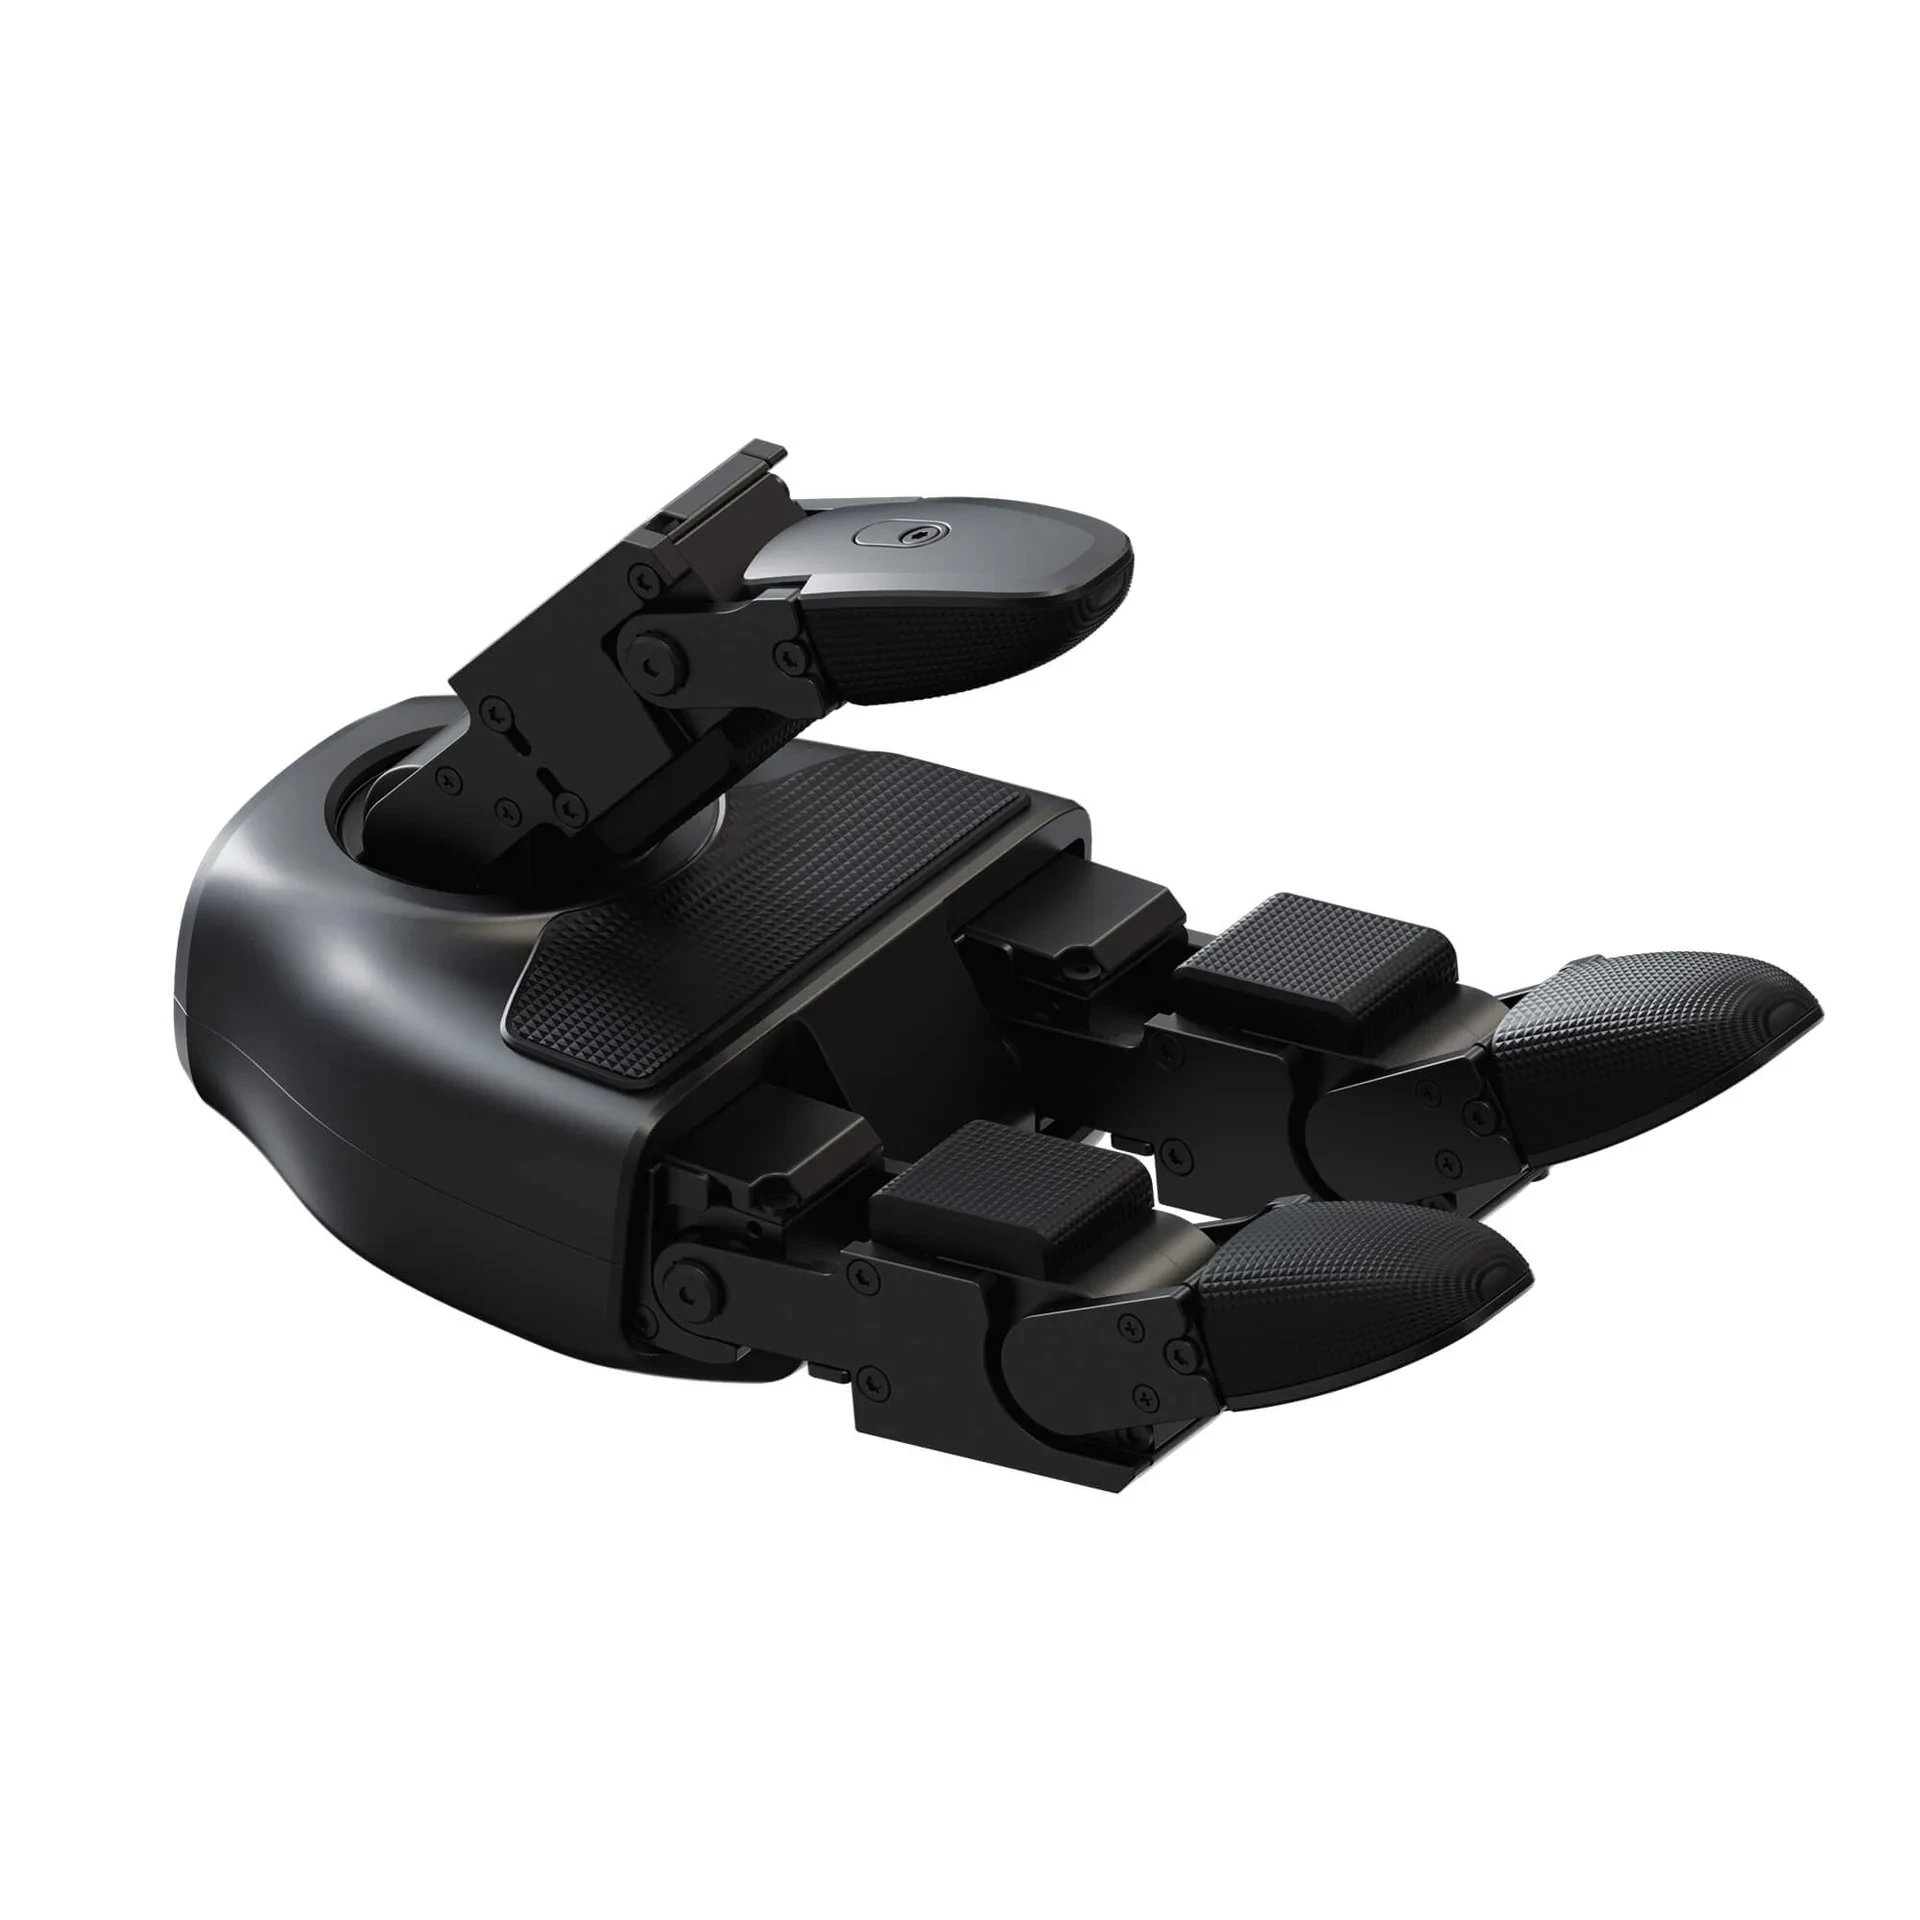
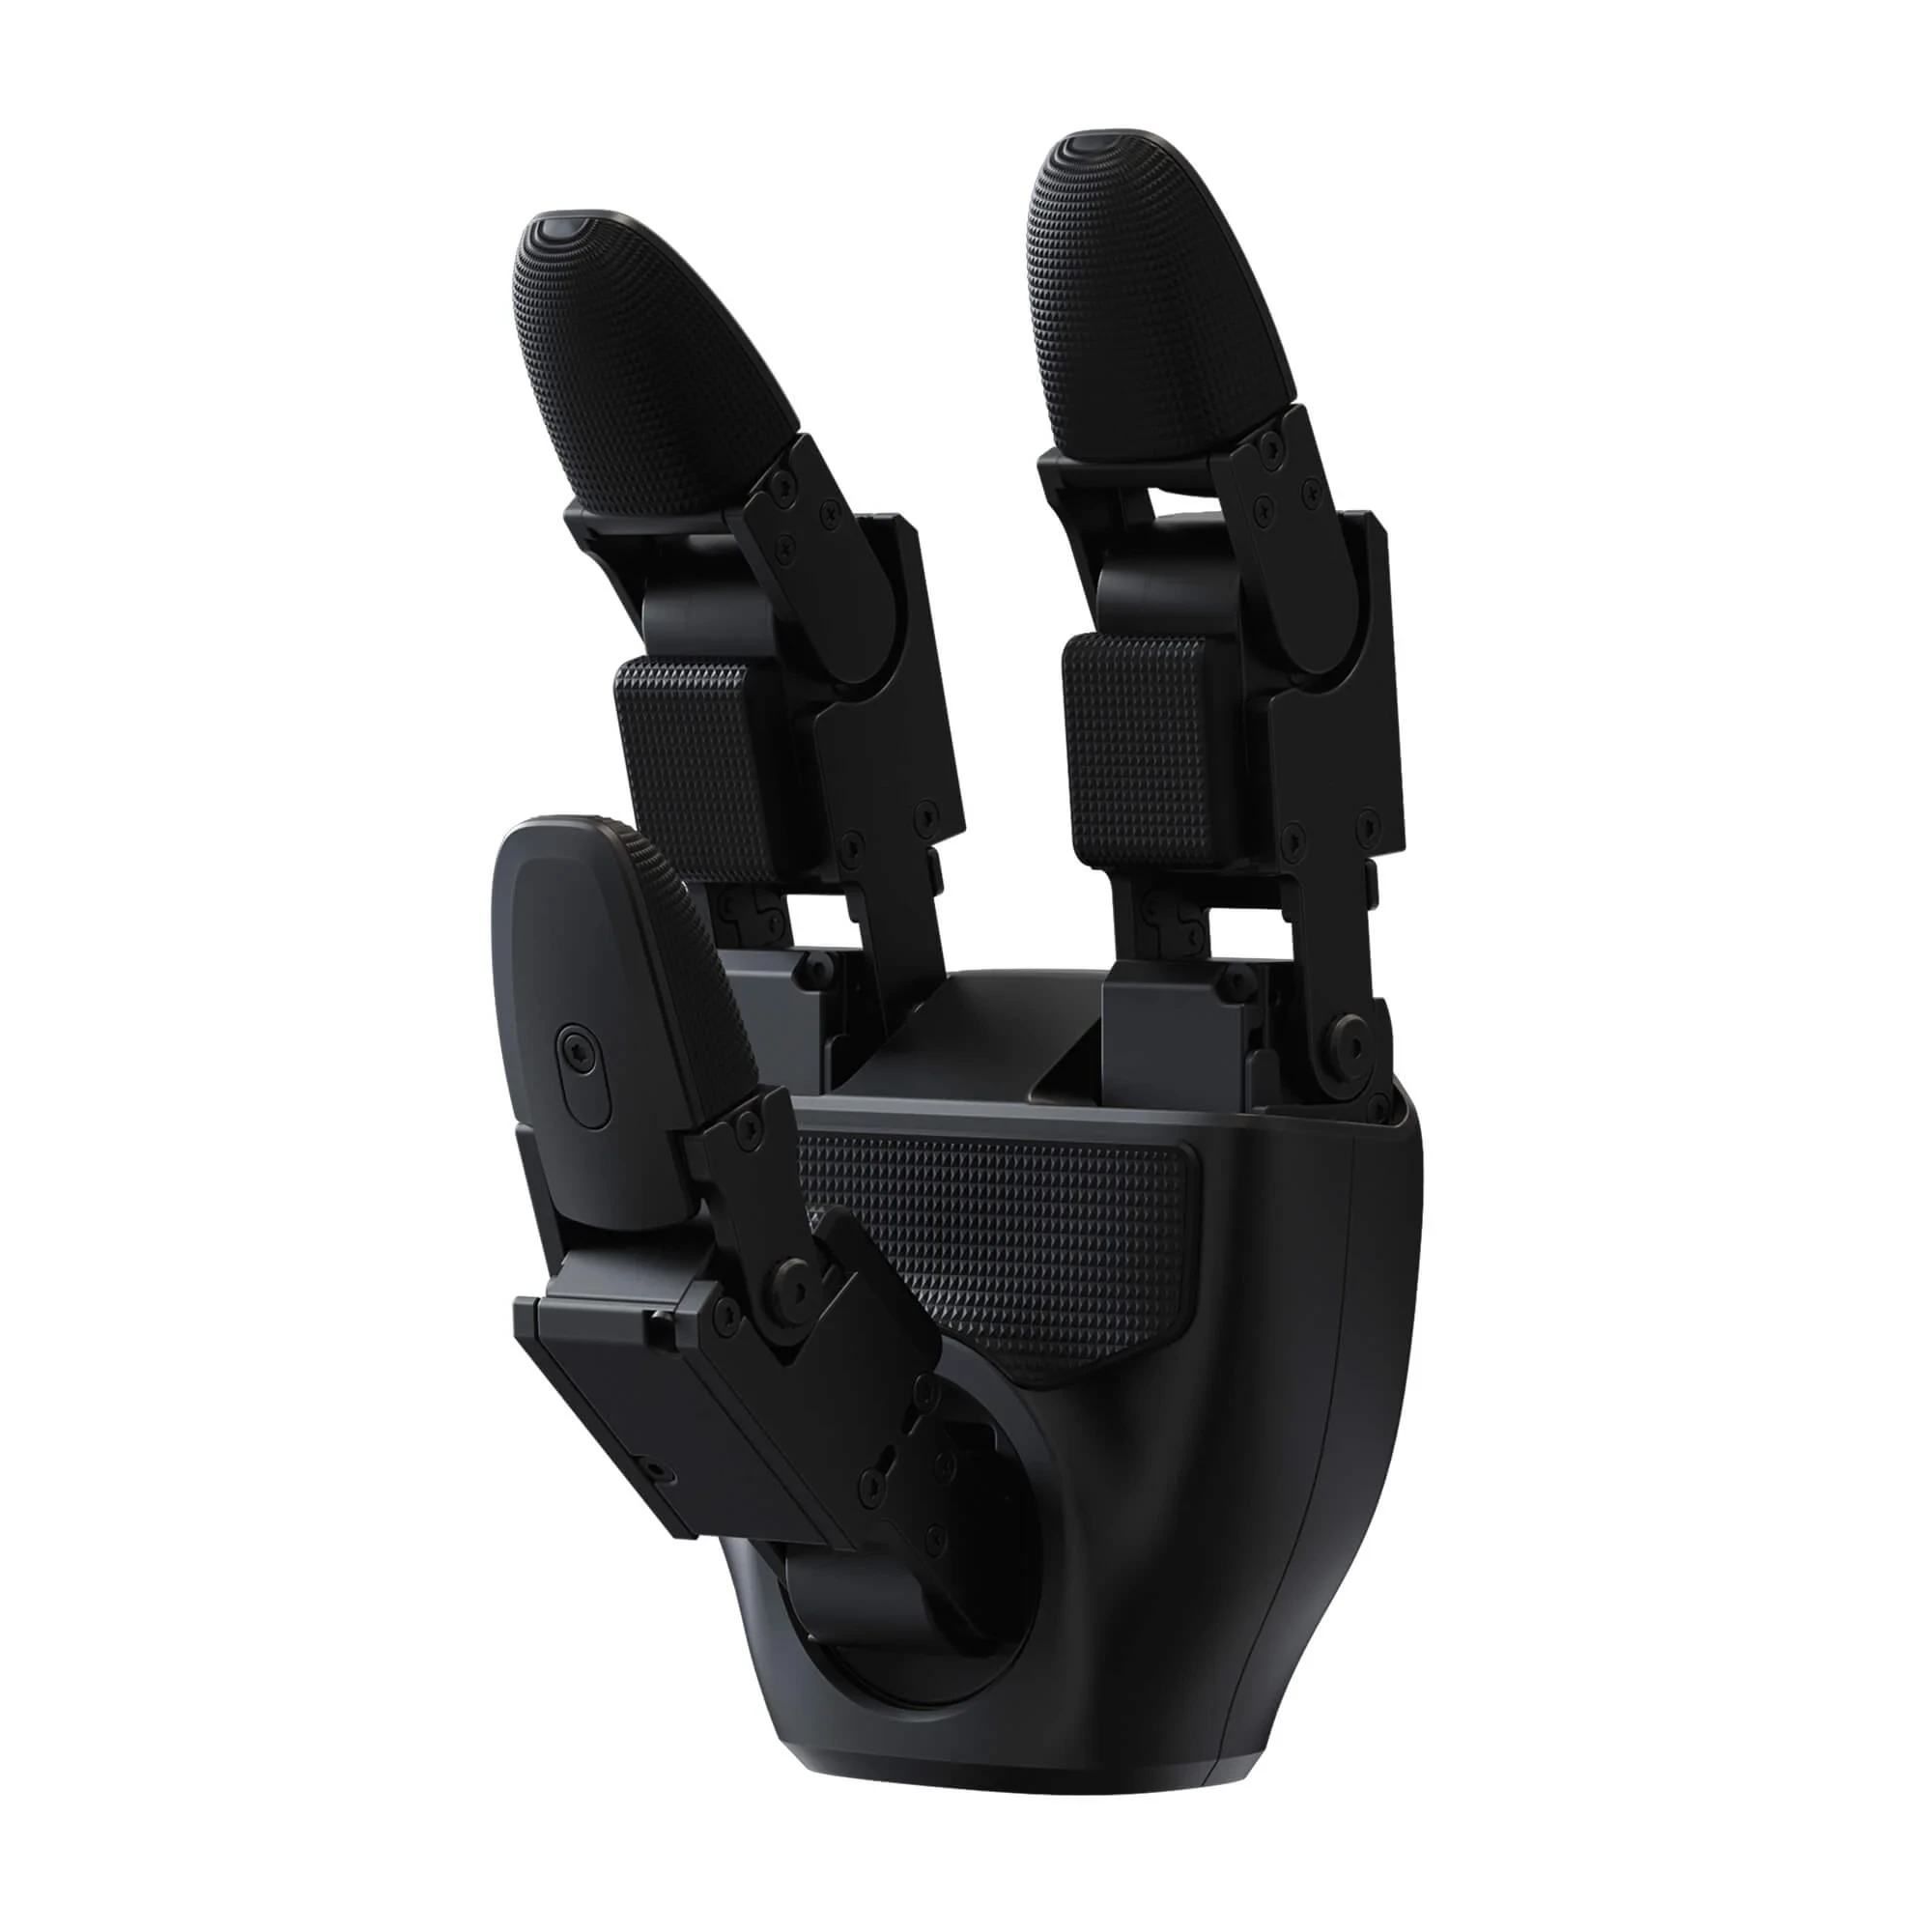
The Unitree tendon-driven dexterous hand (Dex2/5) is the five-finger hand option for the Unitree G1 EDU and R1 humanoids. It runs a gear-tendon rope drive: two actuated degrees of freedom drive ten joints, so the four fingers close together in a coordinated, enveloping grasp while the thumb opposes them. It is sold per hand — for new robot configurations, replacements and development work.
For labs and integrators, the Unitree tendon-driven dexterous hand is the lightweight, durable way to put a five-finger hand on a G1 or R1. It is built for repeated daily grasping rather than delicate per-finger manipulation, with all wiring hidden inside the shell.
Two Channels, Ten Joints: How the Tendon Drive Works
The Unitree tendon-driven dexterous hand uses a gear-tendon rope drive instead of a motor per finger. Two actuated degrees of freedom drive ten joints: the thumb runs on its own channel, and the index, middle, ring and little fingers share a second channel. When the hand closes, the four fingers curl together and wrap around the object — an adaptive, enveloping power grasp that needs no per-finger servos. That is the deliberate tradeoff: no independent finger control, but far fewer motors, which is how the hand gets to 365 g and its price point.
The layout is built to be knocked around. The entire hand has passed over 100,000 fatigue cycles and more than 100 drop tests, and all wiring runs hidden inside the shell — there are no exposed cables to snag. A full fist closes in 0.5 seconds, the thumb delivers 15 N of fingertip force with another 15 N across the four fingers, and the hand holds up to 1.5 kg around a 5 cm round object.
- Gear-tendon rope drive — two channels: thumb, and all four fingers together
- 100,000+ fatigue cycles and 100+ drop tests — built for daily knocks
- 0.5 s fist clench · 15 N thumb, 15 N across the four fingers
Dex2/5 vs Dex3-1 vs Dex1-1: Which Unitree Hand to Buy
Unitree's end effectors solve three different problems. This page is the Unitree tendon-driven dexterous hand — here is how it sits against the force-controlled Dex3-1 and the Dex1-1 parallel gripper.
| Dex2/5 (this page) | Dex3-1 | Dex1-1 | |
|---|---|---|---|
| Form | Five fingers | Three fingers | Two-finger parallel gripper |
| Actuation | Gear-tendon rope drive — 2 actuated DoF | 7-DoF force control — 6 direct-drive + 1 gear-driven joint | Single motorized jaw, 90 mm stroke |
| Grasp style | Coordinated whole-hand power grasp | Per-joint force-position hybrid control — compliant pinch and tripod grasps | Parallel pinch with programmable force |
| Sensing options | Joint position, velocity, torque, temperature | Adds a tactile version with 33 pressure sensors | Adds RGB / RealSense D405 camera bundles |
| Best for | Lightweight five-finger grasping on G1/R1 at the lowest cost | Teleoperation and contact-rich manipulation on the G1 EDU | Simple pick-and-place and vision-guided gripping |
Sold Per Hand — Plan Your Setup
The Unitree tendon-driven dexterous hand is sold per hand, and there is one SKU for both sides — the same hand mounts on the left arm or the right arm, so there are no separate left and right part numbers to track.
Order a single hand for a replacement or for single-arm tasks. For bilateral manipulation on a G1 or R1, plan a pair — two of the same hand, added as two line items on your quote.
- One SKU mounts on either arm — no left/right variants
- A single hand covers replacements and single-arm tasks
- A full humanoid setup uses two — one per arm
The Five-Finger Hand for the G1 and R1
The Unitree tendon-driven dexterous hand is the five-finger hand option Unitree lists for the G1 and R1 humanoids — on the G1 it pairs with the EDU configurations that take dexterous-hand options. The hand mounts at the wrist interface and connects over RS485 at 1,000 Hz.
Over that link the hand reports joint mode, position, velocity, torque and temperature plus voltage and current, and accepts position, velocity, torque and stiffness/damping commands — so integration work runs on a standard serial bus at the 24–60 V system voltage.
Specifications
| Type | Five-finger tendon-driven dexterous hand (in-house developed) |
| Model | Dex2/5 |
| Sold as | Per hand — a humanoid setup typically uses two |
| Degrees of freedom | 2 actuated — thumb ×1 · index, middle, ring and little fingers share 1 |
| Joints | 10 — four fingers ×8 · thumb ×2 |
| Transmission | Gear-tendon rope drive |
| Weight | 365 g |
| Dimensions | 151 × 70 × 63 mm (flat state) |
| Thumb joint range | J0 0~42° · J1 0~105° |
| Four-finger joint range | J0 0~88° · J1 0~105° |
| Minimum fist clench time | 0.5 s |
| Minimum grip diameter | 8 mm |
| Fingertip force | Thumb 15 N · four fingers 15 N total |
| Max grasping load | 1.5 kg (5 cm round rigid object, palm facing down or left) |
| Operating voltage | 24–60 V |
| Static current | 0.1 A @ 58 V |
| Max current | 1.5 A @ 58 V |
| Communication | RS485 |
| Communication rate | 1,000 Hz |
| Perceptual feedback | Joint mode · position · velocity · torque · temperature · voltage/current |
| Control feedback | Joint mode · position · velocity · torque · stiffness & damping coefficients |
| Fatigue life | 100,000+ cycles |
| Drop resistance | 100+ drop tests passed |
| Operating temperature | −20 °C to 60 °C |
| Fits | Unitree G1 EDU · Unitree R1 |
| In the box | Unitree tendon-driven dexterous hand (Dex2/5) — one hand |
Shipping & Service
The hand ships worldwide by DHL or FedEx in protective industrial packaging; exact transit time is confirmed with your quote.
Every unit is 100% quality-inspected before it ships, so it arrives in perfect working order.
Last updated: October 2026.
Frequently Asked Questions
Can't find what you're looking for? Contact our