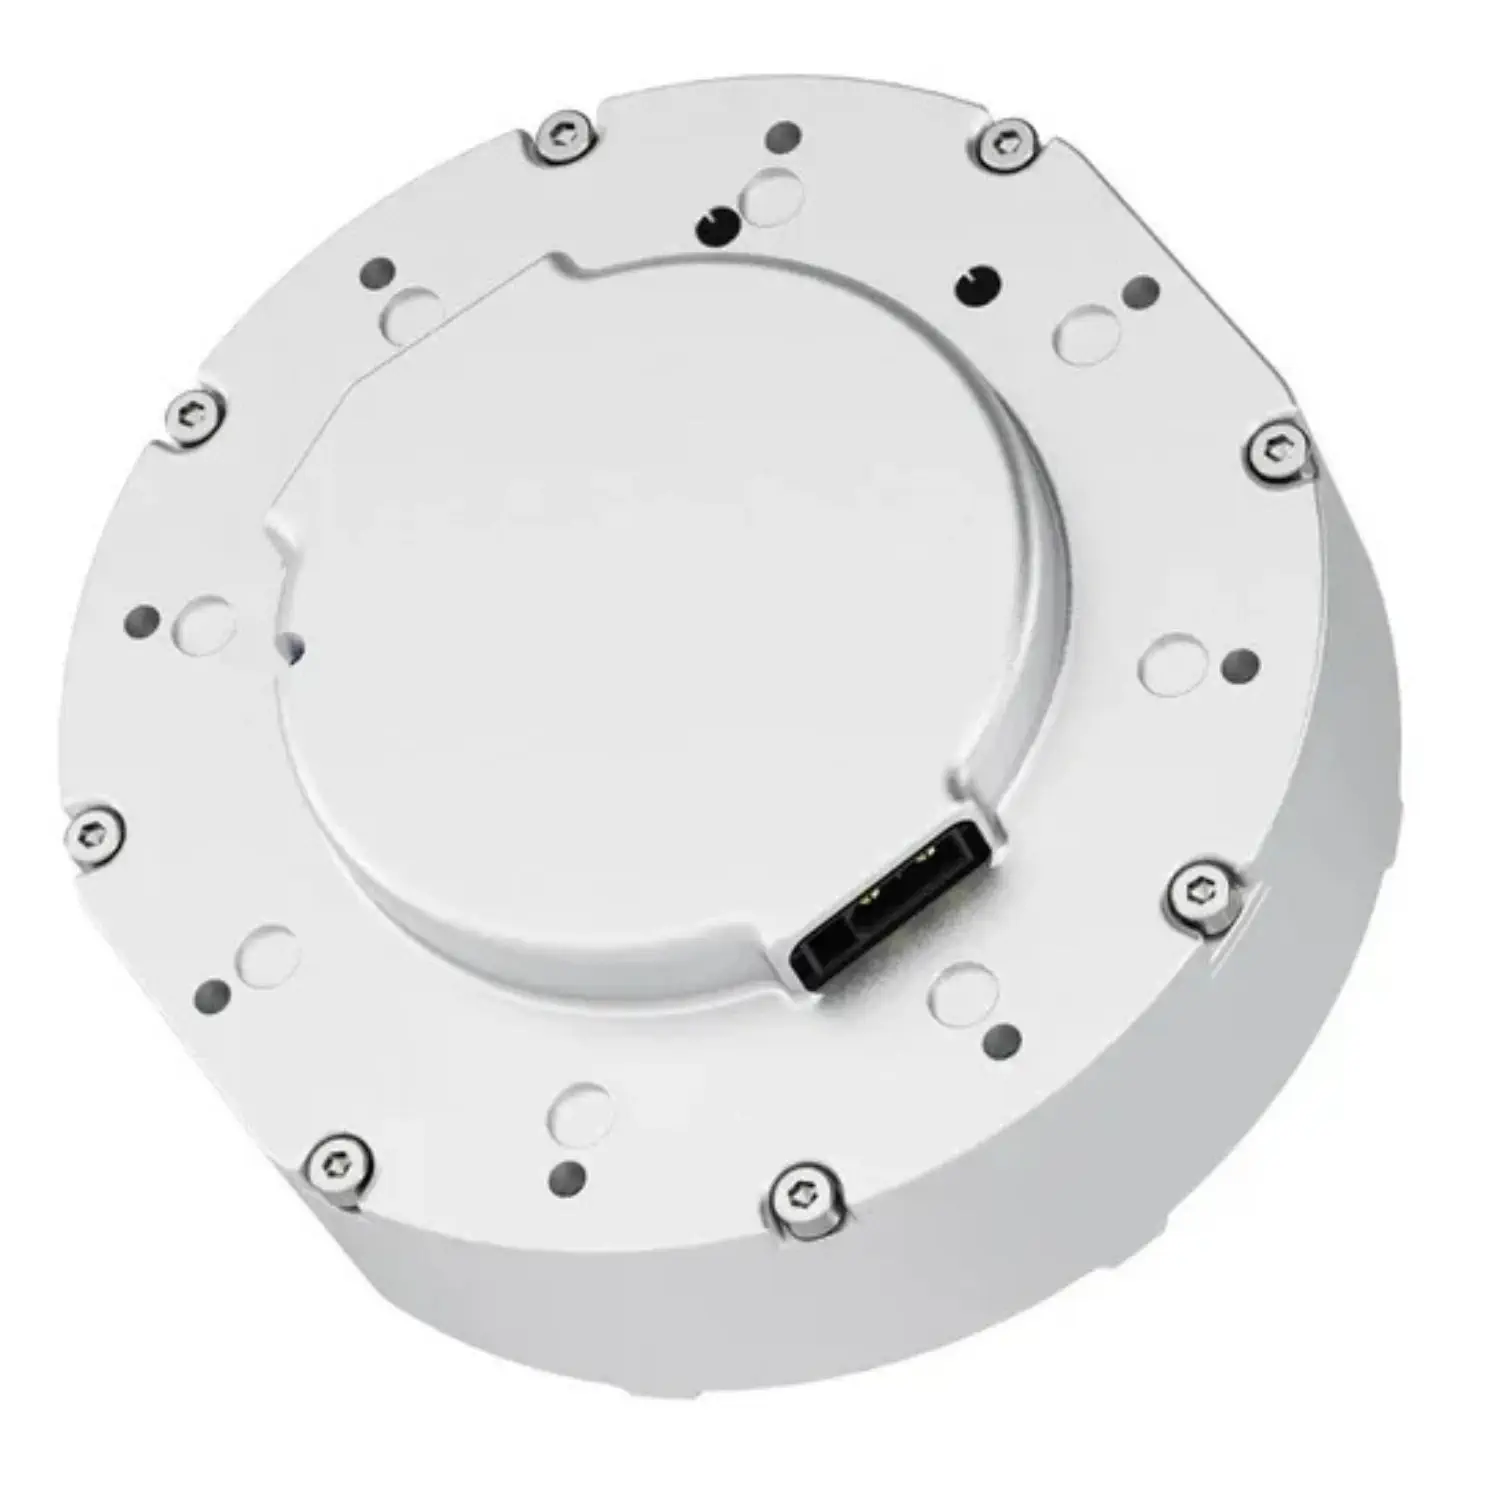
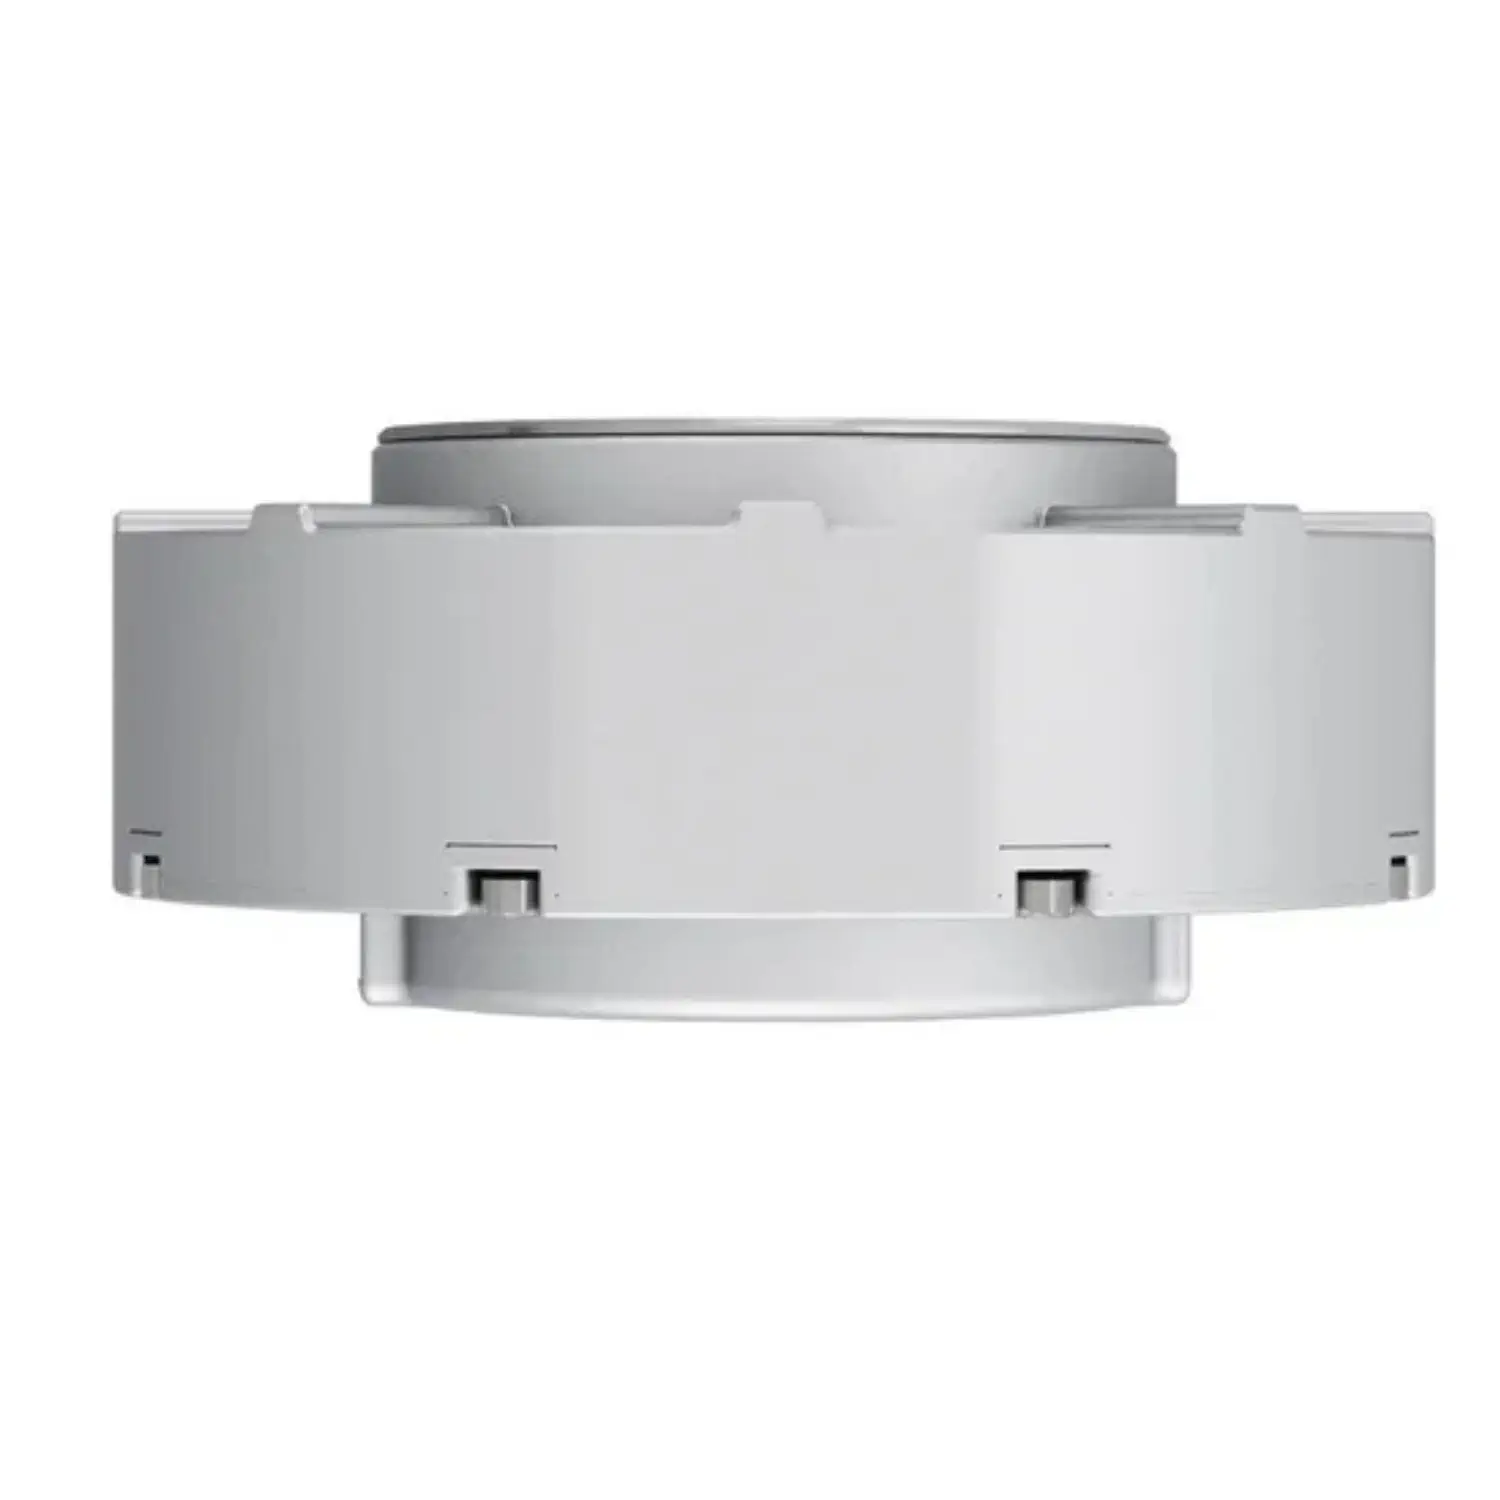
Unitree Go2 Motor
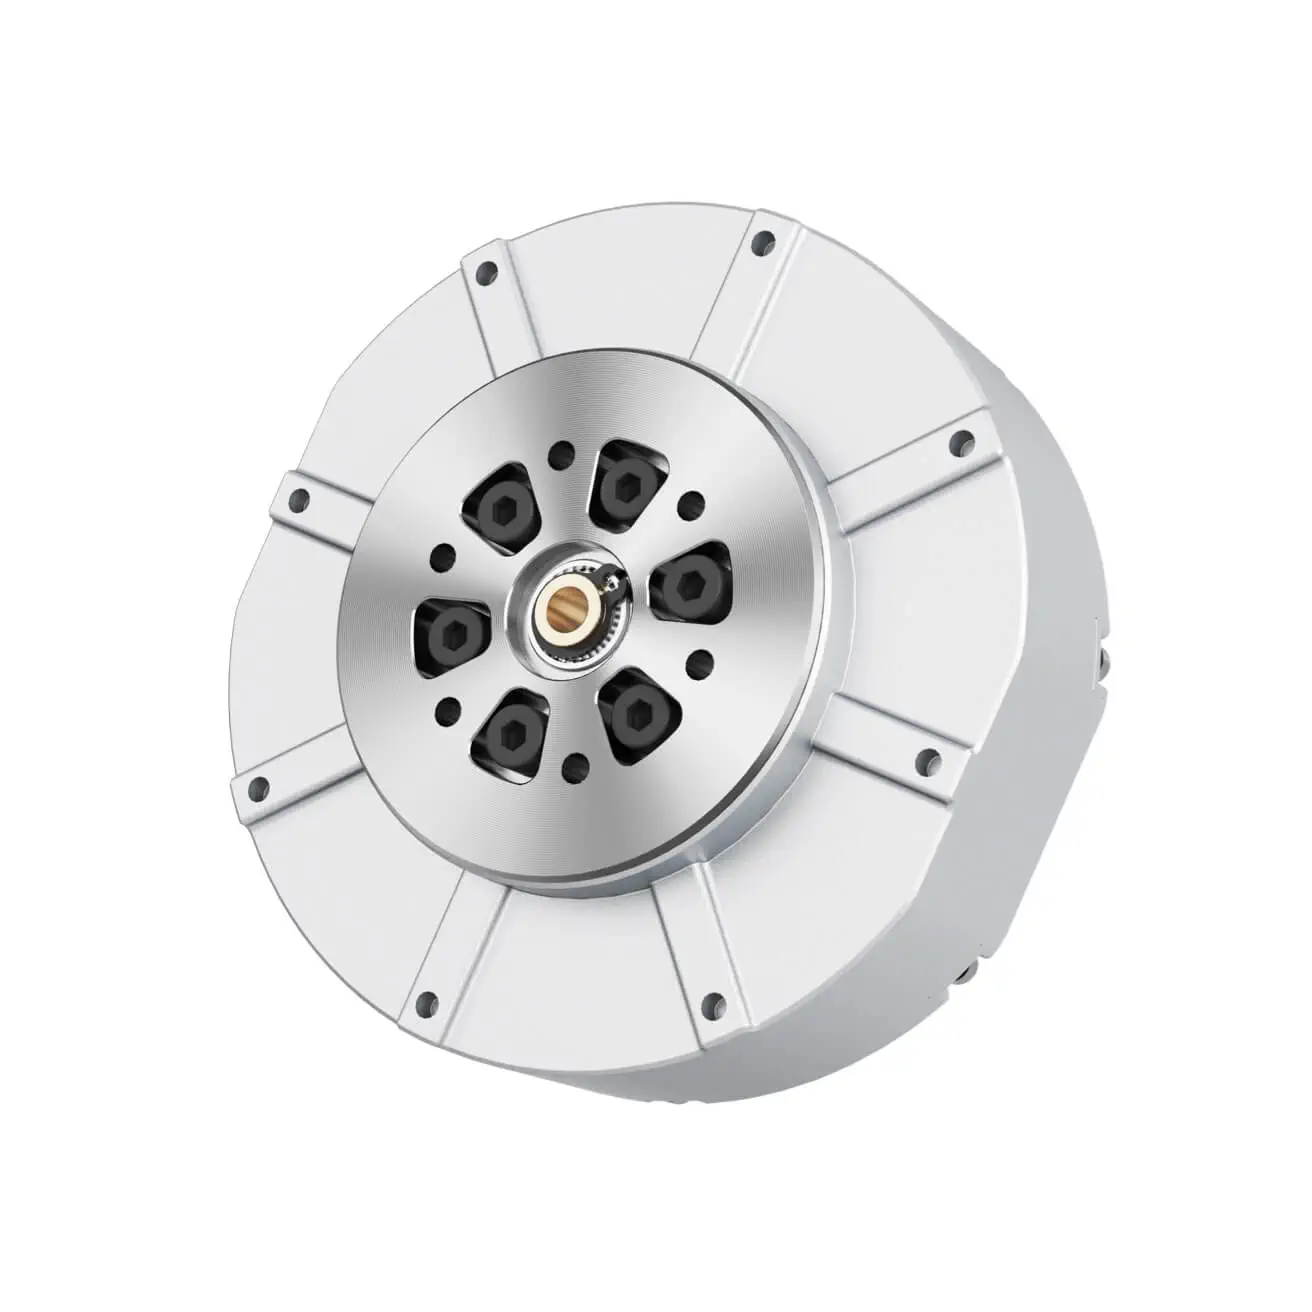
Unitree Go2 body motor — the hip joint motor for abduction and adduction, range -48° to 48°. Built on the shared GO-M8010-6 actuator; not interchangeable with the thigh or calf versions.
- Hip abduction/adduction joint — leg out, leg in
- Range -48° to 48°
- Same actuator family as thigh and calf versions
- Four per robot — one at each hip
About the Unitree Go2 Motor
The Unitree Go2 motor is the joint actuator behind every step the Go2 quadruped takes — three on each leg, twelve across the robot. It is built in three calibrated versions: the body motor that carries the leg at the hip, the thigh motor that swings the upper leg and the calf motor that folds the lower leg at the knee. All three share the same GO-M8010-6 quasi-direct-drive housing, but each is calibrated for its own joint, and they are not interchangeable.
A Go2 leg moves in sequence: the Unitree Go2 body motor abducts and adducts the leg where it meets the torso, the thigh motor swings the upper leg forward and back, and the calf motor folds the lower leg at the knee. The three versions use the identical actuator with the same ~96 × 40 mm silver housing — what differs is joint calibration, range of motion and mounting position, not the hardware itself.
Ordering the right Unitree Go2 motor starts with locating the failed joint on the robot and matching it to the body, calf or thigh version. Every Go2 carries twelve joint motors — four body, four thigh and four calf — so a single failed joint is replaced on its own while the other eleven keep working.
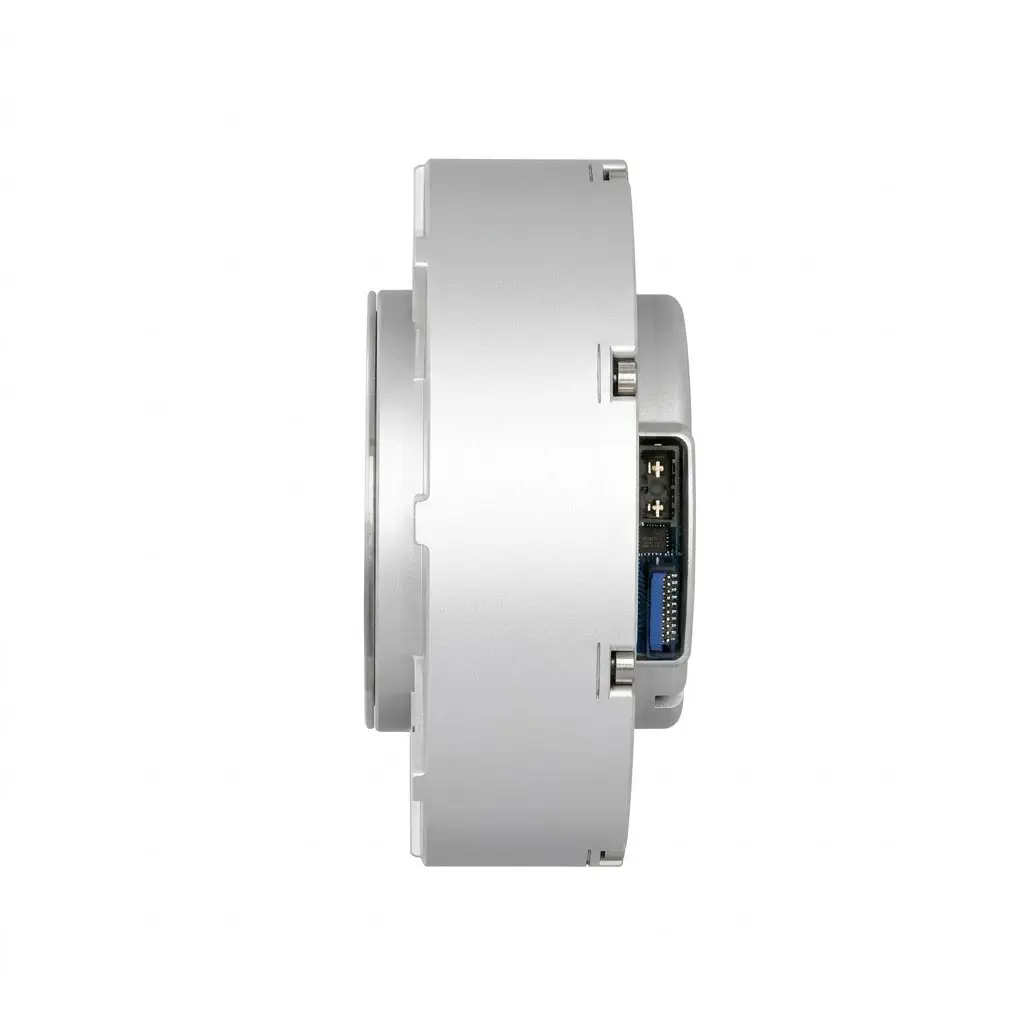
Unitree Go2 Body Motor, Calf Motor and Thigh Motor Compared
Every moving joint on a Go2 is driven by one of three versions of the same actuator family. The versions look alike and share one housing, but each is calibrated for a single joint — picking the right one starts with the joint's position on the leg.
The Unitree Go2 motor comes in three versions: the body motor at the hip, the thigh motor on the upper leg and the calf motor at the knee.
| Body motor | Thigh motor | Calf motor | |
|---|---|---|---|
| Position on the leg | Hip — where the leg meets the torso | Upper leg | Knee / lower leg |
| Joint motion | Abduction / adduction — leg out, leg in | Swing — upper leg forward and back | Fold — lower leg at the knee |
| Range of motion | -48° to 48° | -200° to 90° | -156° to -48° |
| Quantity per robot | 4 — one at each hip | 4 — one per leg | 4 — one per leg |
Every Unitree Go2 Motor Shares the GO-M8010-6 Actuator
Under the silver housing of each joint sits the same quasi-direct-drive actuator Unitree sells as the GO-M8010-6 — a joint motor with a precision output bearing, position sensing and high-speed communication, in a housing that measures roughly 96 × 40 mm on all three versions.
Because the hardware is shared, the three versions occupy the same compact mounting space and connect through the same joint wiring. What separates them is the calibration baked in for their joint: range of motion, direction and mounting orientation. That is why a calf motor cannot stand in for a thigh motor even though the housings are identical.
Which Unitree Go2 Motor Do I Need?
Every Unitree Go2 motor fits the Go2 quadruped; the only choice is which joint the failed motor served. If the failed joint is the hip — where the leg meets the torso — order the body motor. If it is the upper-leg joint, order the thigh motor; if it is the knee, order the calf motor. When in doubt, match the joint's range of motion against the table above.
- Hip joint (leg meets torso) → body motor
- Upper-leg joint → thigh motor
- Knee / lower-leg joint → calf motor
- When unsure, match the joint's range of motion to the comparison table
Specifications
| Body Motor | Thigh Motor | Calf Motor | |
|---|---|---|---|
| Type | Body (hip abduction/adduction) motor | Thigh (upper-leg swing) motor | Calf (knee / lower-leg) motor |
| Joint range | -48° to 48° | -200° to 90° | -156° to -48° |
| Role per leg | Carries the leg at the hip — abduction and adduction | Swings the upper leg forward and back | Folds and extends the lower leg at the knee |
| Quantity per robot | 4 (one at each hip) | 4 (one per leg) | 4 (one per leg) |
| In the box | 1 × Unitree Go2 Body Motor | 1 × Unitree Go2 Thigh Motor | 1 × Unitree Go2 Calf Motor |
Shipping & Motor Care
The Unitree Go2 motor ships as a compact, rigid parcel by express courier — with no lithium battery inside, it is not subject to battery shipping restrictions. For a working robot, keeping one spare motor of each version on the shelf is the fastest way to survive a joint failure, and a spare Go2 battery or charger travels in the same parcel.
Handle the motor by its housing rather than the output plate, keep the connector capped until installation, and store spares dry at room temperature.
Last updated: September 2026.
Frequently Asked Questions
Can't find what you're looking for? Contact our