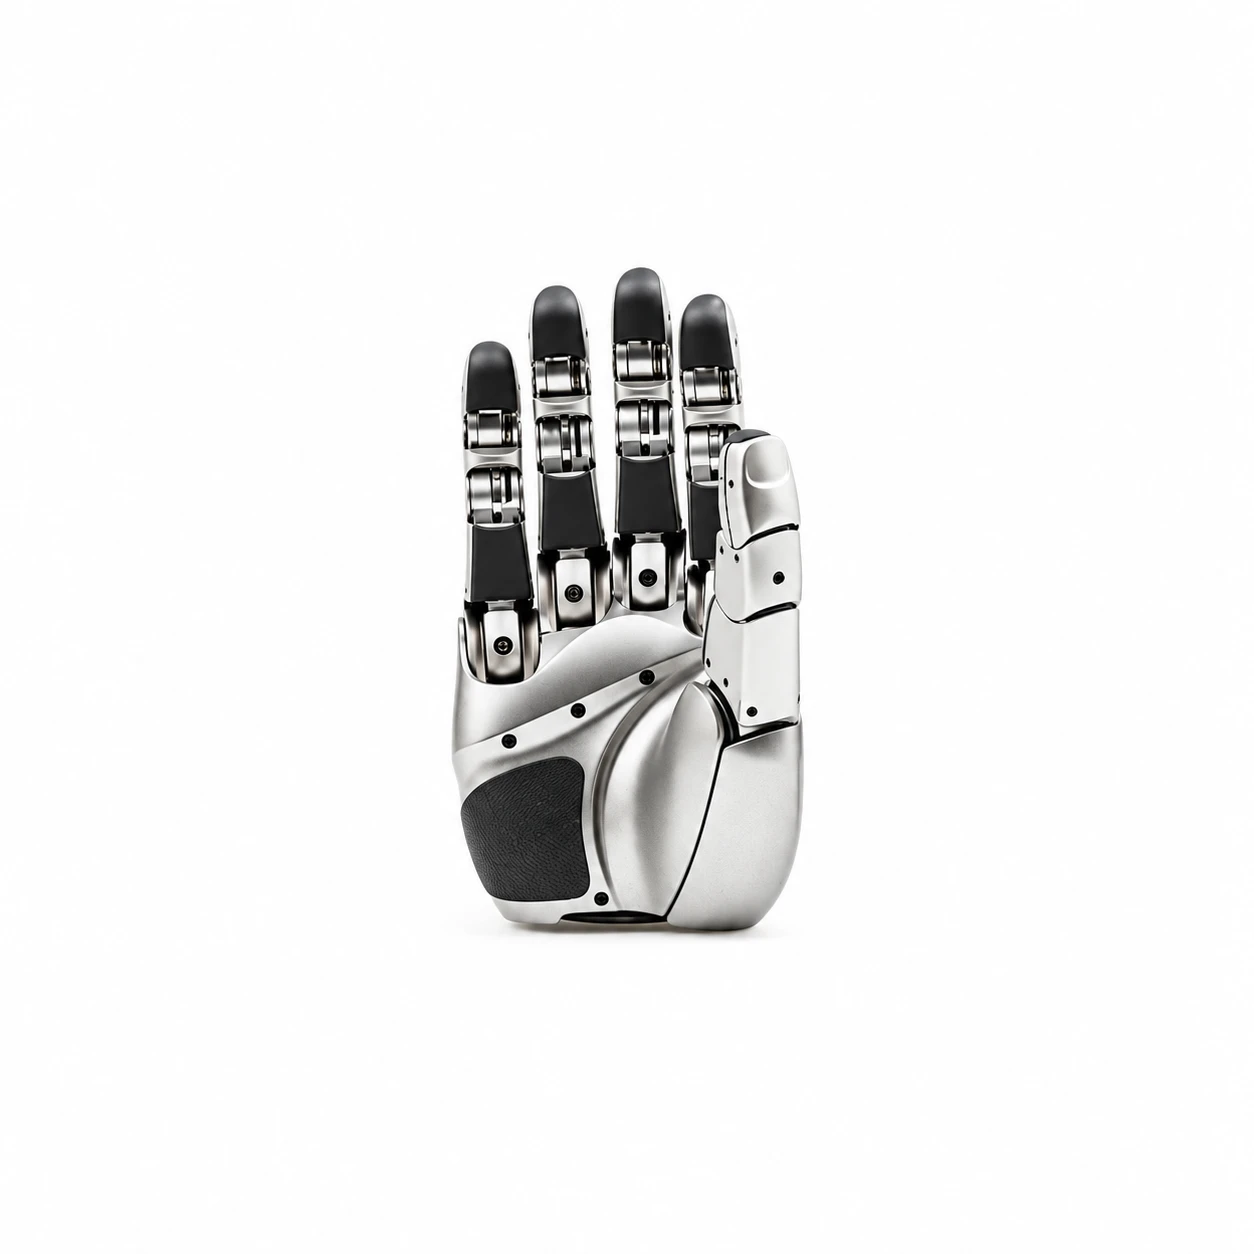
Unitree H1/H1-2 Dexterous Hand
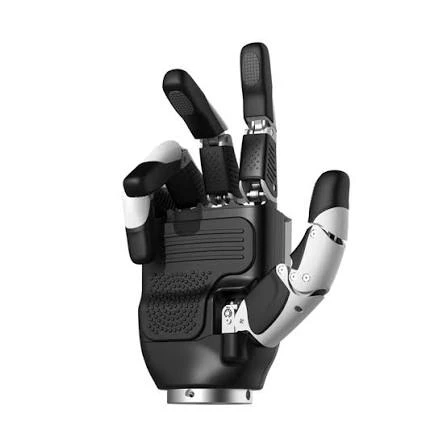
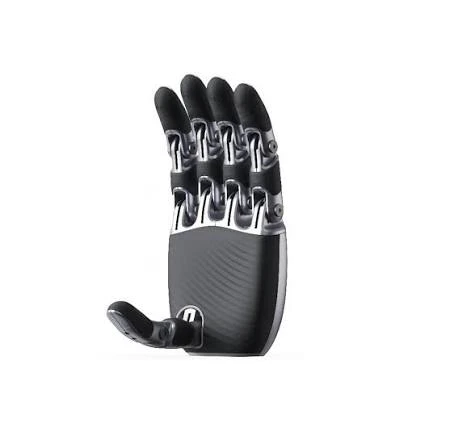
Unitree H1-2 dexterous hand — the five-finger Dex5-1 without the tactile sensing array, for the H1 and H1-2 humanoids. Sold per hand; the tactile Dex5-1P is one click away.
- Unitree H1
- Unitree H1-2
About the Unitree H1/H1-2 Dexterous Hand
The Unitree H1-2 dexterous hand is Unitree's five-finger dexterous hand for the H1 and H1-2 humanoids — the retail name for the hand Unitree models as the Dex5-1 and Dex5-1P. It mounts at the wrist as the robot's grasping end effector and is sold per hand for new robot configurations, replacements and manipulation research.
Both versions on this page share the same hand: the Dex5-1 is the standard configuration, and the Dex5-1P adds a tactile sensing layer on top of it. The comparison below walks through what each version adds and which one fits your pipeline.
Twenty Degrees of Freedom, All of Them Backdrivable
The Unitree H1-2 dexterous hand puts twenty degrees of freedom into a five-finger layout: the thumb carries four of them, each of the other four fingers carries three, and every finger adds a passive lateral swing of ±22° that lets the hand settle onto curved objects instead of pressing against them. All sixteen actuated joints are backdrivable — the hand yields instead of fighting back — which is what removes the stiff-handed feel from teleoperation and reinforcement-learning data collection.
Under the shell, twelve self-developed micro force-controlled composite transmission joints do most of the work, with four gear-driven joints completing the set. Each joint pairs a high-power-density hollow-cup motor with a high-precision encoder inside a low-damping, small-clearance reducer, and the rotation axes sit close to the finger surface — so the hand wraps objects smoothly instead of catching a knuckle corner on them. All five fingers are independently replaceable, so a damaged finger is a single-part swap rather than a hand replacement.
- 20 DoF — 16 actuated + 4 passive, with ±22° lateral swing on every finger
- Backdrivable joints for smooth teleoperation and RL training
- All five fingers replaceable as individual parts
Dex5-1 or Dex5-1P: Which Version to Buy
The Unitree H1-2 dexterous hand ships in two versions on the same hand platform. The Dex5-1 is the standard hand; the Dex5-1P adds the tactile sensing layer. Everything else — degrees of freedom, force, dimensions, integration — is identical.
| Dex5-1 | Dex5-1P | |
|---|---|---|
| Tactile sensing | 94 pressure sensors per hand | |
| Feedback set | Joint mode · position · velocity · torque · temperature · voltage/current · IMU | The joint-level set plus tactile pressure data |
| Version fit | Standard configuration for grasping tasks and replacements | Research configuration for tactile datasets and contact-rich policies |
Dex5-1 vs Dex5-S vs Dex2/5 vs Dex3-1: Which Unitree Hand to Buy
Unitree's hand catalog spans several generations. Here is where the Unitree H1-2 dexterous hand — the Dex5-1 family — sits among them.
| H1-2 hand (Dex5-1, this page) | Dex5-S | Dex2/5 | Dex3-1 | |
|---|---|---|---|---|
| Fingers | Five | Five | Five | Three |
| Degrees of freedom | 20 — 16 actuated + 4 passive | 22 per hand | 2 actuated, 10 joints | 7 |
| Tactile option | Dex5-1P — 94 pressure sensors per hand | Dex5-S Pro | Dex3-1 Tactile — 33 pressure sensors | |
| Weight | 1,100 g | 620 g | 365 g | 710 g |
| Voltage & interface | 24–60 V · USB 2.0 | 15–65 V · Ethernet / USB / RS-485 | 24–60 V · RS485 | 12–58 V · USB 2.0 |
| Named for | H1 and H1-2 — the H1-2 specification names it | Unitree's own shop, from $6,350 | G1 and R1 | G1 EDU |
| Best for | Five-finger tactile grasping on the H1 and H1-2 | Newest-generation builds with Ethernet integration | Lightweight, low-cost five-finger grasping on the G1 and R1 | Per-joint force control on the G1 EDU |
Sold Per Hand — Left and Right Are Separate Units
The Unitree H1-2 dexterous hand is sold per hand. Left and right are separate units with identical specifications, so you order exactly the side your robot needs.
For a full humanoid setup, plan a pair: two hands, added as two line items on your quote. A single hand covers a replacement or a single-arm task.
- One hand per line item — order left or right as needed
- A replacement or single-arm task needs one
- A full humanoid setup uses two — one per arm
The Hand the H1-2 Specification Names
The official Unitree H1 specification lists the H1-2's dexterous-hand option as "Dex5-1 or other ambidextrous hands" — that named slot is what the Unitree H1-2 dexterous hand fills, and the original H1 carries the dexterous hand as an optional configuration as well.
Integration runs over USB 2.0 at a 1,000 Hz control rate on a 24–60 V supply — the hand reports joint mode, position, velocity, torque, temperature, voltage and current plus IMU data every cycle.
Specifications
| Dex5-1 | Dex5-1P | |
|---|---|---|
| Type | Five-finger dexterous hand (in-house developed) | Five-finger dexterous hand (in-house developed) |
| Model | Dex5-1 | Dex5-1P |
| Version | Standard — without the tactile sensing array | Tactile — 94 pressure sensors per hand |
| Sold as | Per hand — left and right are separate units; a humanoid setup typically uses two | Per hand — left and right are separate units; a humanoid setup typically uses two |
| Degrees of freedom | 20 — 16 actuated + 4 passive (four-finger lateral swing) | 20 — 16 actuated + 4 passive (four-finger lateral swing) |
| Per-finger degrees of freedom | Thumb ×4 · index, middle, ring and little fingers ×3 each | Thumb ×4 · index, middle, ring and little fingers ×3 each |
| Transmission | 12 micro force-controlled composite transmission joints + 4 gear-driven joints | 12 micro force-controlled composite transmission joints + 4 gear-driven joints |
| Weight | 1,100 g | 1,100 g |
| Dimensions | 217.3 × 127.5 × 72.1 mm (flat state) | 217.3 × 127.5 × 72.1 mm (flat state) |
| Thumb joint range | J0 −33.5°~39° · J1 0~100° · J2 0~110° · J3 0~92° | J0 −33.5°~39° · J1 0~100° · J2 0~110° · J3 0~92° |
| Four-finger joint range | Knuckle 0 −22°~22° · Knuckle 1 0~90° · Knuckle 2 0~95° · Knuckle 3 0~81° (coupled with joint 2) | Knuckle 0 −22°~22° · Knuckle 1 0~90° · Knuckle 2 0~95° · Knuckle 3 0~81° (coupled with joint 2) |
| Four-finger lateral swing | ±22° | ±22° |
| Minimum grip diameter | 10 mm | 10 mm |
| Fingertip repeat positioning accuracy | ±1 mm | ±1 mm |
| Fingertip force | 10 N (vertical press with a 1 cm cylinder; varies by scenario) | 10 N (vertical press with a 1 cm cylinder; varies by scenario) |
| Max grasping load | 3.5 kg palm facing down · 4.5 kg palm facing left (5 cm round rigid object, room temperature) | 3.5 kg palm facing down · 4.5 kg palm facing left (5 cm round rigid object, room temperature) |
| Operating voltage | 24–60 V | 24–60 V |
| Static current | 0.2 A @ 58 V | 0.2 A @ 58 V |
| Max current | 4 A @ 58 V | 4 A @ 58 V |
| Communication | USB 2.0 | USB 2.0 |
| Communication rate | 1,000 Hz | 1,000 Hz |
| Full packet size | Sender 1,234 bytes · receiver 1,270 bytes | Sender 1,234 bytes · receiver 1,270 bytes |
| Tactile sensing | — (the Dex5-1P adds 94 pressure sensors per hand) | 94 pressure sensors per hand · secondary development of tactile algorithms supported |
| Operating temperature | −20 °C to 60 °C | −20 °C to 60 °C |
| Fits | Unitree H1 · Unitree H1-2 | Unitree H1 · Unitree H1-2 |
| In the box | Unitree H1-2 dexterous hand (Dex5-1) — one hand | Unitree H1-2 dexterous hand (Dex5-1P) — one hand |
Shipping & Service
The hand ships worldwide by DHL or FedEx in protective industrial packaging; exact transit time is confirmed with your quote.
Every unit is 100% quality-inspected before it ships, so it arrives in perfect working order.
Last updated: October 2026.
Frequently Asked Questions
Can't find what you're looking for? Contact our